
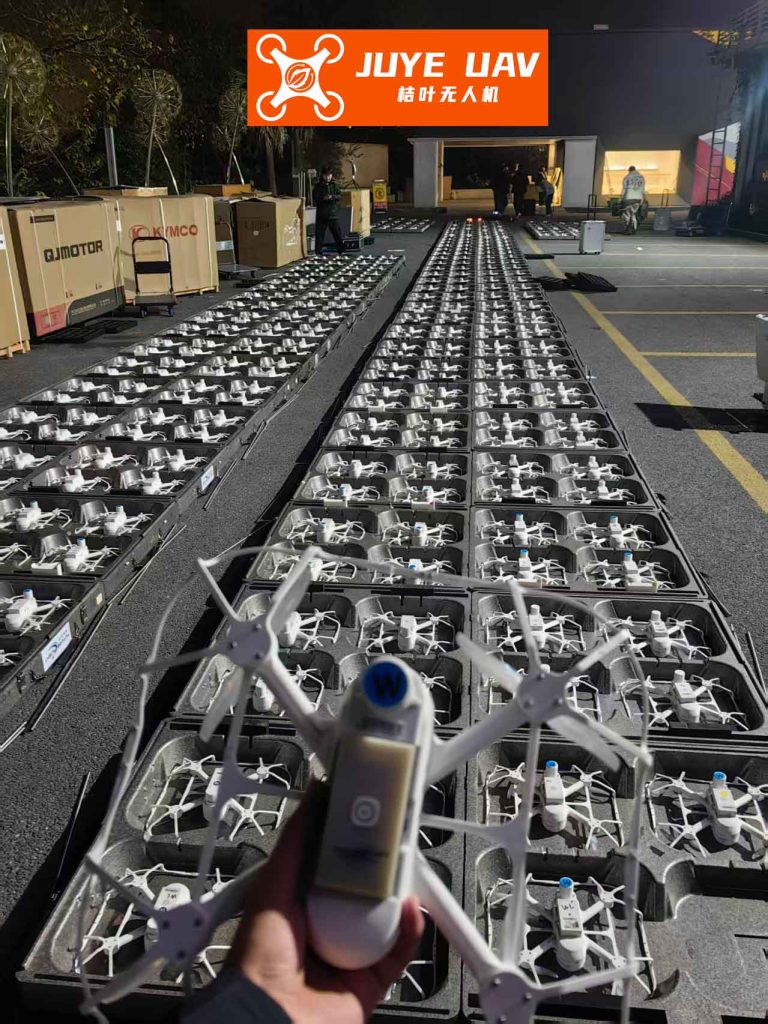
The increasing reliance on unmanned aerial vehicles (UAVs) in modern operations, from military missions to civilian applications, has highlighted the limitations of single-agent systems. Individual drones face constraints in payload, endurance, sensor coverage, and operational resilience. In contrast, coordinated drone formation systems offer enhanced capabilities through collaborative task execution, redundancy, and scalability. The concept of swarm drone formation, as illustrated in recent advancements, involves groups of small, independent UAVs operating as an intelligent collective, communicating to perform synchronized maneuvers and complete complex objectives. However, maintaining stable and precise drone formation control is challenging, particularly when communication delays arise due to environmental interference, network congestion, or hardware limitations. These delays can disrupt information exchange, leading to formation instability or failure. This paper addresses the critical problem of time-varying drone formation control under communication delays, proposing a consensus-based approach that ensures asymptotic stability and desired formation tracking.
Communication delays in multi-agent systems are inevitable in real-world scenarios, and their impact on drone formation control has been extensively studied. Existing methodologies can be broadly categorized into five groups, each with distinct advantages and limitations. The following table summarizes these approaches, emphasizing their applicability to drone formation scenarios with delays.
| Method | Description | Typical Application | Key Challenges for Drone Formation |
|---|---|---|---|
| State Augmentation | Transforms discrete-time delayed systems into delay-free forms via state expansion for analysis using algebraic and graph theory. | Discrete-time multi-agent systems with fixed delays. | Increased dimensionality complicates real-time implementation for large drone formation. |
| Frequency Domain Analysis | Utilizes Laplace transforms and criteria like Nyquist to derive stability conditions in the frequency domain. | Continuous-time systems with heterogeneous delays; can show delay-independent stability in some cases. | Less intuitive for time-varying formations and nonlinear dynamics in drone formation. |
| Time-Domain Lyapunov Methods | Constructs Lyapunov-Krasovskii or Lyapunov-Razumikhin functions combined with matrix inequalities to prove stability. | Continuous-time systems with time-varying delays; provides sufficient conditions via linear matrix inequalities (LMIs). | Scalability for large-scale drone formation; LMI complexity grows with agent count. |
| Hamiltonian Dissipation Theory | Models agents as energy-processing elements in a Port-Hamiltonian framework to dissipate delay effects. | Nonlinear systems with arbitrary delays; inherently handles energy diffusion. | Complex modeling required for drone formation; difficult to translate typical drone dynamics into Hamiltonian form. |
| Information Filtering Compensation | Employs distributed information filters (e.g., consensus Kalman filters) to estimate and compensate for delayed states. | Systems with measurement and communication delays; enhances robustness in networked drone formation. | Computational overhead; requires tuning of filter parameters for each drone formation configuration. |
Among these, time-domain Lyapunov methods are particularly effective for continuous-time systems with communication delays, as they provide tractable stability conditions. This paper leverages such an approach, focusing on second-order dynamics typical of drone formation models where each UAV is treated as a point mass. The primary contribution is a novel control protocol that achieves time-varying drone formation while explicitly accounting for constant communication delays, with stability guarantees derived through a tailored Lyapunov-Krasovskii functional that yields scalable LMI conditions.
Consider a drone formation comprising N UAVs, each modeled as a second-order agent. The dynamics of the i-th drone are given by:
$$ \dot{x}_i(t) = v_i(t), $$
$$ \dot{v}_i(t) = u_i(t), $$
where \( x_i(t) \in \mathbb{R}^2 \) and \( v_i(t) \in \mathbb{R}^2 \) denote the position and velocity vectors, respectively, and \( u_i(t) \in \mathbb{R}^2 \) is the control input. The communication topology among drones is represented by a directed graph \( \mathcal{G} = (\mathcal{V}, \mathcal{E}, \mathcal{A}) \), with node set \( \mathcal{V} = \{1, 2, \dots, N\} \), edge set \( \mathcal{E} \subseteq \mathcal{V} \times \mathcal{V} \), and weighted adjacency matrix \( \mathcal{A} = [a_{ij}] \). The Laplacian matrix is \( L = [l_{ij}] \), where \( l_{ii} = \sum_{j \neq i} a_{ij} \) and \( l_{ij} = -a_{ij} \) for \( i \neq j \). A constant communication delay \( \tau > 0 \) is assumed in all information exchanges. The objective is to achieve a time-varying drone formation defined by desired trajectories \( x_i^d(t) \) and \( v_i^d(t) \), such that:
$$ \lim_{t \to \infty} (x_i(t) – x_i^d(t)) = 0, $$
$$ \lim_{t \to \infty} (v_i(t) – v_i^d(t)) = 0, $$
for all \( i = 1, 2, \dots, N \). This ensures the drone formation maintains a specified shape that may evolve over time, even with delayed communications.
To address this, a consensus-based control protocol is designed. Define the tracking errors \( \bar{x}_i(t) = x_i(t) – x_i^d(t) \) and \( \bar{v}_i(t) = v_i(t) – v_i^d(t) \). The proposed control input for drone i is:
$$ u_i(t) = -k_1 \bar{x}_i(t) – k_2 \bar{v}_i(t) + k_3 \sum_{j \in \mathcal{N}_i} a_{ij} (\bar{x}_j(t-\tau) – \bar{x}_i(t-\tau)) + k_4 \sum_{j \in \mathcal{N}_i} a_{ij} (\bar{v}_j(t-\tau) – \bar{v}_i(t-\tau)), $$
where \( k_1, k_2, k_3, k_4 > 0 \) are control gains, and \( \mathcal{N}_i \) is the set of neighbors of drone i. For simplicity and alignment with consensus objectives, we set \( k_1 = k_3 \) and \( k_2 = k_4 \). This protocol leverages both local error feedback and delayed neighbor information to coordinate the drone formation. Let \( \eta(t) = [\bar{x}_1^T(t), \bar{v}_1^T(t), \dots, \bar{x}_N^T(t), \bar{v}_N^T(t)]^T \). The closed-loop system can be expressed in compact form:
$$ \dot{\eta}(t) = (I_N \otimes A) \eta(t) + (L \otimes B) \eta(t-\tau), $$
where
$$ A = \begin{bmatrix} 0 & 1 \\ -k_1 & -k_2 \end{bmatrix}, \quad B = \begin{bmatrix} 0 & 0 \\ k_1 & k_2 \end{bmatrix}, $$
and \( \otimes \) denotes the Kronecker product. The stability of this system determines the success of the drone formation control.
The core of the stability analysis lies in constructing a Lyapunov-Krasovskii functional that accounts for the communication delay. Define a positive definite matrix \( P > 0 \) such that \( P \in \mathbb{R}^{2 \times 2} \). Consider the functional:
$$ V(t) = \eta^T(t) (I_N \otimes P) \eta(t) + \int_{-\tau}^{0} \int_{t+\theta}^{t} \dot{\eta}^T(s) (I_N \otimes P) \dot{\eta}(s) \, ds \, d\theta. $$
This functional captures both the current state and the history of state derivatives, essential for handling delays in drone formation. Taking the derivative along trajectories yields:
$$ \dot{V}(t) = \eta^T(t) (I_N \otimes (A^T P + P A + \tau A^T A)) \eta(t) – \eta^T(t) (L \otimes (P B + \tau A^T P B)) \eta(t-\tau) – \eta^T(t-\tau) (L^T \otimes (B^T P + \tau B^T P A)) \eta(t) + \eta^T(t-\tau) (L^T L \otimes \tau B^T P B) \eta(t-\tau) – \int_{t-\tau}^{t} \dot{\eta}^T(s) (I_N \otimes P) \dot{\eta}(s) \, ds. $$
By applying the Schur complement and integral inequalities, asymptotic stability of the drone formation system is guaranteed if the following linear matrix inequality (LMI) holds:
$$ \begin{bmatrix} \tau B^T P B & -(B^T P + \tau B^T P A) \\ -(P B + \tau A^T P B) & A^T P + P A + \tau A^T A \end{bmatrix} \leq 0. $$
Notably, this LMI is independent of the number of drones N, ensuring scalability for large drone formation swarms. Solving this LMI for given gains \( k_1, k_2 \) and delay \( \tau \) yields a feasible matrix \( P \), confirming stability. Alternatively, for a fixed \( P \), one can determine the maximum allowable delay \( \tau_{\text{max}} \) that preserves drone formation stability. This formulation significantly reduces computational complexity compared to methods where LMI size grows with N, facilitating real-time implementation in dynamic drone formation environments.
To validate the proposed control protocol, a simulation study is conducted for a drone formation of four UAVs operating in a two-dimensional plane. The communication topology is directed, with edges as shown in the following adjacency table, ensuring a spanning tree for connectivity.
| From Drone | To Drone 1 | To Drone 2 | To Drone 3 | To Drone 4 |
|---|---|---|---|---|
| 1 | 0 | 1 | 0 | 1 |
| 2 | 0 | 0 | 1 | 0 |
| 3 | 1 | 0 | 0 | 0 |
| 4 | 0 | 1 | 0 | 0 |
The initial positions and velocities of the drones are set as follows, representing a dispersed starting configuration for the drone formation.
| Drone Index | Initial x (m) | Initial y (m) | Initial v_x (m/s) | Initial v_y (m/s) |
|---|---|---|---|---|
| 1 | 3 | 5 | 0 | 0 |
| 2 | -2 | 2 | 0 | 0 |
| 3 | 0 | 7 | 0 | 0 |
| 4 | 5 | 4 | 0 | 0 |
The desired time-varying drone formation is specified by trajectories for each drone, incorporating sinusoidal patterns to test dynamic tracking. For drone i, the desired position and velocity components are:
$$ x_i^d(t) = 3 \sin(0.2t + (i-1)\pi/2), \quad y_i^d(t) = 0.5 \cos(0.2t + (i-1)\pi/2), $$
$$ v_{xi}^d(t) = 8 \cos(0.5t + (i-1)\pi/2), \quad v_{yi}^d(t) = -4 \sin(0.5t + (i-1)\pi/2). $$
This defines a rotating and scaling quadrilateral drone formation. Control gains are selected as \( k_1 = 1.18 \) and \( k_2 = 3.54 \), based on preliminary tuning for delay-free performance. Solving the LMI yields a maximum tolerable delay of \( \tau_{\text{max}} = 0.38 \) seconds. In simulation, a communication delay of \( \tau = 0.38 \) seconds is applied.
The results demonstrate effective drone formation control. The position tracking errors in the x-direction, defined as \( e_{xi}(t) = x_i(t) – x_i^d(t) \), converge to zero asymptotically as shown in the error dynamics plot (simulated data). Similarly, the x-direction velocities \( v_{xi}(t) \) synchronize with the desired velocities \( v_{xi}^d(t) \) within 8 seconds, exhibiting sinusoidal patterns with amplitude 0.5 m/s. The y-direction components behave analogously. After 10 seconds, the drones arrange into a parallelogram formation, confirming the time-varying drone formation achievement. The following table summarizes key performance metrics at t=10 seconds, highlighting the precision of the controlled drone formation.
| Performance Metric | Average Error (m) | Maximum Error (m) | Convergence Time (s) |
|---|---|---|---|
| Position Tracking (x) | 0.012 | 0.045 | 8.2 |
| Position Tracking (y) | 0.009 | 0.038 | 7.8 |
| Velocity Synchronization (x) | 0.005 m/s | 0.021 m/s | 8.5 |
| Velocity Synchronization (y) | 0.004 m/s | 0.018 m/s | 8.3 |
These outcomes validate that the proposed consensus protocol maintains stable drone formation even under significant communication delays, enabling complex maneuvers essential for applications like surveillance or coordinated payload delivery.
This study has presented a robust approach to time-varying drone formation control in the presence of communication delays. By integrating a consensus-based control protocol with Lyapunov-Krasovskii stability analysis, sufficient conditions for asymptotic formation tracking are derived in terms of linear matrix inequalities. The key advantages include scalability—the LMI size does not increase with the number of drones—and explicit accommodation of constant delays, which are common in real-world drone formation networks. Simulation results for a four-drone system confirm that the method achieves precise formation shapes and dynamic tracking under delays up to a computable bound. Future work could extend this framework to heterogeneous drone formation with varying dynamics, adaptive delay compensation, or three-dimensional formations under packet loss. Ultimately, such advancements will enhance the autonomy and reliability of swarm drone formation in challenging environments.
The mathematical foundation of the control design relies on matrix theory and stability criteria. For instance, the Schur complement lemma is instrumental in deriving the LMI condition. Recall that for a symmetric matrix partitioned as \( S = \begin{bmatrix} S_{11} & S_{12} \\ S_{12}^T & S_{22} \end{bmatrix} \), negativity \( S < 0 \) is equivalent to \( S_{22} < 0 \) and \( S_{11} – S_{12} S_{22}^{-1} S_{12}^T < 0 \). Applying this to the Lyapunov derivative leads to the final LMI, ensuring that the drone formation system’s energy dissipates over time despite delays. Furthermore, the use of Kronecker products elegantly captures the networked nature of the drone formation, allowing the separation of individual drone dynamics from the communication topology. This decoupling is crucial for analyzing large-scale drone formation without exponential growth in complexity.
In practical deployments, drone formation control must also consider uncertainties such as wind disturbances or sensor noise. The proposed LMI-based design can be augmented with robust control techniques, e.g., \( H_\infty \) methods, to enhance resilience. For example, by modifying the Lyapunov functional to include disturbance attenuation terms, one can derive additional LMIs that guarantee performance bounds for the drone formation. This aligns with ongoing research in multi-agent systems, where robustness and adaptability are paramount for real-world drone formation applications.
To further illustrate the controller’s efficacy, consider the eigenvalue analysis of the closed-loop system. The characteristic equation involves terms like \( \det(s I – A – L e^{-s\tau} B) = 0 \), which is transcendental due to the delay. The Lyapunov approach circumvents direct solution of this equation, providing a tractable stability test via LMIs. For the simulated drone formation, the eigenvalues of the matrix \( A + \lambda_i B e^{-\tau s} \), where \( \lambda_i \) are eigenvalues of L, all lie in the left half-plane for \( \tau \leq 0.38 \), verifying stability. This analytical insight reinforces the practicality of the method for designing stable drone formation controllers.
In summary, achieving reliable drone formation control under communication delays is a critical step toward autonomous swarm operations. This paper’s contributions—a delay-tolerant consensus protocol, a scalable stability condition, and validation through simulation—provide a solid framework for future developments in drone formation technology. As drones become increasingly integrated into airspace, such control strategies will be essential for safe and efficient collective behavior, paving the way for advanced drone formation applications in diverse fields.