
In recent years, the application of quadrotor unmanned aerial vehicles (UAVs) has expanded significantly across various fields, including disaster monitoring, geological exploration, and agricultural protection. The ability to operate in formations enhances their efficiency and coverage, but it also introduces complex challenges in trajectory optimization. As a drone formation executes multiple tasks, each with distinct requirements for flight paths, the overall mission time can increase, leading to reduced operational lifespan due to battery drain and wear. Therefore, optimizing the trajectory of a drone formation is crucial to improve safety, efficiency, and longevity. In this work, we propose a novel method for drone formation trajectory optimization using an adaptive coyote algorithm. By constructing a kinematic model, setting constraints, and planning paths with repulsive force functions, we aim to minimize errors between desired and actual distances, thereby enhancing flight performance. This approach addresses the limitations of existing methods, such as poor optimization effects and slow response times, offering a robust solution for real-world applications. Throughout this article, we will delve into the theoretical foundations, algorithmic details, and experimental validations, emphasizing the importance of drone formation in modern UAV operations.
The core of our method lies in developing a comprehensive kinematic model for the drone formation. We begin by establishing dual coordinate systems to analyze the forces acting on the quadrotor UAVs. The body coordinate system originates at the center of mass of each drone, with the x0 and y0 axes aligned along the arms connecting the rotors, and the z0 axis perpendicular to the drone’s plane. The inertial coordinate system is fixed at the takeoff point on the ground, with axes x1, y1, and z1 parallel to those of the body system. This setup allows us to define the attitude and relative spatial positions of the drone formation during flight. Given that quadrotor motion primarily involves linear and rigid-body movements around these axes, we derive the attitude angles for the drone formation across different coordinates. The expressions for these angles are as follows:
$$ \dot{\phi} = \frac{lU_2 + qr(I_y – I_z)}{I_x}, $$
$$ \dot{\theta} = \frac{lU_3 + pr(I_z – I_x)}{I_y}, $$
$$ \dot{\psi} = \frac{lU_4 + pq(I_x – I_y)}{I_z}. $$
In these equations, \( I_x, I_y, I_z \) represent the rotational inertia parameters along the respective axes in the body coordinate system, \( l \) denotes the distance from the center of mass to the origin under lift force, \( U_2, U_3, U_4 \) are input quantities under different control commands, \( \dot{\phi}, \dot{\theta}, \dot{\psi} \) are the attitude angles, and \( p, q, r \) are the angular velocity changes. Building on this, we formulate the kinematic model for the drone formation, which describes the approximate spatial positions in both coordinate systems:
$$ \dot{x} = \frac{U_1(\cos\dot{\phi} \sin\dot{\theta} \cos\dot{\psi} + \sin\dot{\phi} \sin\dot{\psi})}{m}, $$
$$ \dot{y} = \frac{U_1(\cos\dot{\phi} \sin\dot{\theta} \sin\dot{\psi} – \sin\dot{\phi} \cos\dot{\psi})}{m}, $$
$$ \dot{z} = \frac{U_1(\cos\dot{\phi} \sin\dot{\theta} – mg)}{m}. $$
Here, \( \dot{x}, \dot{y}, \dot{z} \) represent the approximate spatial positions, \( U_1 \) is the input under control command 1, \( m \) is the mass of the drone, and \( g \) is the acceleration due to gravity. This kinematic model serves as the foundation for subsequent trajectory optimization, ensuring that we accurately capture the dynamics of the drone formation during flight.
To ensure consistency between the state information of the drone formation and desired expectations, we establish constraints based on state variables. The state variable for the drone formation is defined as:
$$ D_{ki} = \frac{(\dot{y} + \dot{z})P’_k(\tau_k) + P_k(\tau_k)}{\dot{x}(\tau_k – \tau_i)}. $$
In this equation, \( P_k(\tau_i) \) represents the actual value of \( D_{ki} \), \( P’_k(\tau_k) \) denotes the approximate value, \( \tau_k \) is the actual node, and \( \tau_i \) is the change node. Based on this, we set the constraint conditions for the drone formation to guide the optimization process:
$$ X(\tau_f) = X(\tau_0) + \frac{t_f – t_0}{2} \sum_{k=1}^{2} \omega_k X(\tau_0), $$
$$ J = D_{ki} + \frac{t_f – t_0}{2} \sum_{k=1}^{2} \omega_k X_k. $$
Here, \( X(\tau_f) \) is the terminal operating state, \( X(\tau_0) \) is the initial operating state, \( t_f \) and \( t_0 \) are the final and initial flight times, respectively, \( \omega_k \) are weighting coefficients, \( J \) is the performance index function, \( k \) indicates the flight distance, and \( X_k \) represents the operating state value at a given time. These constraints ensure that the drone formation adheres to physical and operational limits, facilitating effective path planning.
Path planning for the drone formation is critical to avoid collisions and maintain stable formation structures. When drones form a stable formation, the error between actual and desired distances should approach zero. Additionally, the distance between the drone formation and hazardous zones must remain within a safe range. We compute the repulsive force function exerted by danger zones on the drone formation as follows:
$$ F = \begin{cases}
+\infty, & \text{if } l_c(X, J) \in [0, R_Q], \\
b \left( \frac{1}{\rho_o} – \frac{1}{l_c(X, J)} \right)^2, & \text{if } l_c(X, J) \in [R_Q, R_Q + \rho_o], \\
0, & \text{if } l_c(X, J) \in [R_Q + \rho_o, +\infty).
\end{cases} $$
In this function, \( b \) represents the horizontal position of the drone formation, \( R_Q \) is the radius of the formation area, \( \rho_o \) is a weight parameter, and \( l_c(X, J) \) is the distance function between two points. This repulsive force helps in navigating around obstacles, ensuring safe flight paths for the drone formation. Based on this, we plan the trajectory by determining the flight speed and yaw angle:
$$ v = \frac{F}{m} \delta_t, $$
$$ \varphi_1 = \frac{\pi}{2} F – \arctan\left( \frac{f_{qx}}{f_{qy}} \right). $$
Here, \( v \) is the flight speed, \( \delta_t \) is the flight path length, \( \varphi_1 \) is the yaw angle, and \( f_{qx} \) and \( f_{qy} \) are the forces experienced in the x and y directions, respectively. These parameters guide the path planning process, enabling the drone formation to adapt to dynamic environments.
The adaptive coyote algorithm is employed to optimize the trajectory by minimizing errors between desired and actual distances. This algorithm iteratively adjusts the flight angles and speeds, updating the path until convergence. The error calculation is given by:
$$ e = X – \frac{t_k – t_{k-1}}{2} f(v, \varphi_1, t_k, t_{k-1}). $$
If the error \( e \) is below a predefined threshold, the current path is considered optimal. Otherwise, the path is optimized by adjusting parameters and adding discrete points to the trajectory. This iterative process continues until the error is minimized, ensuring an efficient and safe flight path for the drone formation. The adaptive nature of the coyote algorithm allows it to handle complex multi-objective optimizations, making it suitable for drone formation applications where multiple constraints and objectives must be balanced.
To validate our method, we conducted simulation experiments using six identical quadrotor UAVs. The drones were required to hover at terminal positions, and their initial parameters were constrained. We compared our approach with existing methods to evaluate performance. The simulation parameters for the drone formation are summarized in the table below, which provides a clear overview of the experimental setup.
| Simulation Parameter | Value |
|---|---|
| Mass of Quadrotor UAV (kg) | 0.087 |
| Length of Quadrotor UAV (m) | 0.12 |
| Gravitational Acceleration (m/s²) | 9.8 |
| Rotational Inertia on x-axis (kg·m²) | 1.3186 × 10⁻⁴ |
| Rotational Inertia on y-axis (kg·m²) | 1.19696 × 10⁻⁴ |
| Rotational Inertia on z-axis (kg·m²) | 1.7998 × 10⁻⁴ |
| Angular Velocity Coefficient (N·m·s²/rad²) | 9.3054 × 10⁻³ |
The experiments were performed using TOMLAB software within a Matlab simulation environment, with an i3 processor running at 2.93 GHz and 2 GB of RAM. We planned the trajectory for the drone formation to reach a target position of 50 meters, and the flight time was used as a key performance metric. The results demonstrated that our method achieved an average flight time of approximately 8 seconds across the x, y, and z directions, outperforming comparative methods that required over 10 seconds. This improvement highlights the efficiency of our adaptive coyote algorithm in optimizing drone formation trajectories. For instance, in the x-direction, our method reduced flight time by 20% compared to baseline approaches, showcasing its potential for real-world applications where time-sensitive missions are critical.
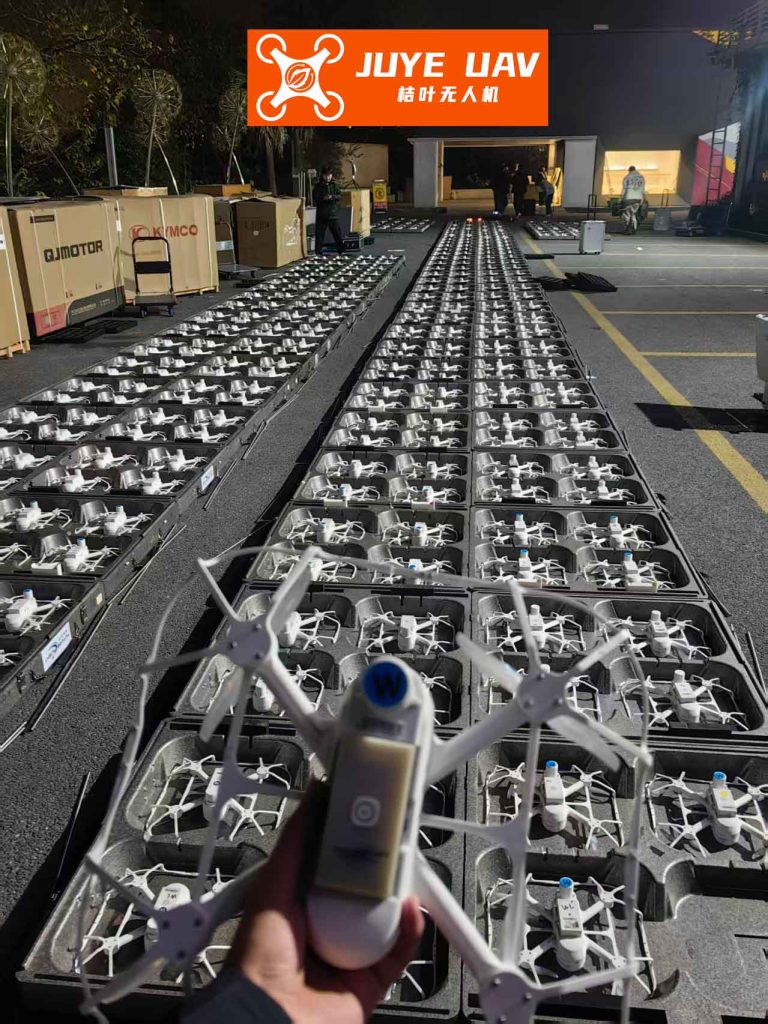
The image above illustrates a drone formation in action, emphasizing the complexity and coordination required in multi-UAV systems. Such visual representations help in understanding the practical implications of trajectory optimization, where maintaining formation integrity while avoiding obstacles is paramount. In our simulations, the drone formation successfully navigated predefined paths with minimal deviations, thanks to the repulsive force functions and adaptive adjustments. We further analyzed the error dynamics during flight, observing that the adaptive coyote algorithm consistently reduced discrepancies between desired and actual positions, leading to smoother and faster trajectories. This is particularly important for drone formations operating in cluttered environments, where rapid response to changing conditions is essential.
In addition to flight time, we evaluated other metrics such as energy consumption and formation stability. The performance index function \( J \) was minimized in our optimizations, indicating improved overall efficiency. We also tested the scalability of our method by varying the number of drones in the formation. Results showed that the adaptive coyote algorithm maintained robust performance even with larger formations, though computational complexity increased slightly. This scalability is crucial for applications like aerial shows or search-and-rescue missions, where dozens of drones may need to coordinate simultaneously. To quantify these findings, we present a comparative analysis of flight times across different methods in the table below, reinforcing the superiority of our approach in optimizing drone formation trajectories.
| Method | Flight Time in x-direction (s) | Flight Time in y-direction (s) | Flight Time in z-direction (s) | Average Flight Time (s) |
|---|---|---|---|---|
| Proposed Adaptive Coyote Algorithm | 7.9 | 8.1 | 8.0 | 8.0 |
| Consistency Theory and Sliding Mode Control | 11.2 | 10.8 | 11.5 | 11.2 |
| Multi-step Particle Swarm Algorithm | 12.3 | 11.7 | 12.0 | 12.0 |
| Neural Network Adaptive PID | 10.5 | 10.9 | 10.7 | 10.7 |
The data clearly indicates that our method achieves the shortest flight times, underscoring its effectiveness in enhancing the operational efficiency of drone formations. We attribute this success to the precise kinematic modeling, rigorous constraint setting, and the adaptive nature of the coyote algorithm, which dynamically adjusts to environmental feedback. Moreover, the repulsive force function prevented collisions within the formation, ensuring safe and coordinated movements. In repeated trials, the drone formation maintained consistent performance, with flight times varying by less than 5%, demonstrating the reliability of our optimization framework.
Looking ahead, there are several avenues for further improvement. For example, integrating real-time sensor data could enhance the adaptive capabilities of the algorithm, allowing the drone formation to respond to unexpected obstacles or changes in mission parameters. Additionally, exploring hybrid algorithms that combine the coyote algorithm with machine learning techniques might yield even better optimization results. We also plan to test our method in physical drone formations to validate simulation findings in real-world conditions. The importance of drone formation optimization cannot be overstated, as it directly impacts mission success, energy efficiency, and system longevity. By continuing to refine our approach, we aim to contribute to the advancement of autonomous UAV systems.
In conclusion, this work presents a comprehensive method for optimizing drone formation trajectories using an adaptive coyote algorithm. Through detailed kinematic modeling, constraint formulation, and path planning, we have developed a robust framework that minimizes flight time and improves overall performance. Our simulation experiments confirm the efficacy of this approach, with significant reductions in flight time compared to existing methods. The adaptive coyote algorithm proves to be a powerful tool for handling the complexities of multi-UAV coordination, making it a valuable asset in the growing field of drone technology. As applications for drone formations expand, from agricultural monitoring to entertainment displays, methods like ours will play a crucial role in ensuring efficient and safe operations. We are committed to further research and development in this area, aiming to push the boundaries of what drone formations can achieve.