
In modern agriculture, UAV drones have revolutionized practices across farming, forestry, livestock, and fisheries, driving the advancement of digital and smart farming systems. As a key player in this transformation, I focus on addressing the critical challenge of optimizing dynamic energy consumption for agricultural multi-rotor UAV drones through intelligent power-load matching. The efficiency of UAV drones hinges on their power system configurations, including motors, electronic speed controllers, propellers, and batteries, which directly influence payload capacity, flight speed, and endurance. However, a significant gap exists in theoretical guidance for selecting rotor numbers and payload configurations during the design phase, often limiting operational precision and efficiency. In this study, I propose a novel method to optimize dynamic energy consumption by configuring payloads based on the power system and rotor number of agricultural UAV drones. By leveraging an established dynamic energy consumption model, I analyze various configurations to derive optimal payload intervals, validated through extensive flight tests. This approach aims to enhance the overall performance and economic viability of UAV drones in agricultural applications.
The core of this work revolves around a dynamic energy consumption model for agricultural UAV drones, which I use to compute energy usage under different conditions. The model is expressed as:
$$ E = \frac{\pi}{30} n_p M N U_b I_b \left[ \left( \frac{a d}{v} + v \right) \frac{a}{P_0} + m_0 v^2 + \frac{1}{2} \rho d C_D A_e v \right]^2 $$
where \(E\) represents the dynamic energy consumption, \(n_p\) is the number of propellers, \(M\) is the propeller torque, \(N\) is the propeller rotational speed, \(U_b\) is the total battery voltage, \(I_b\) is the battery current, \(a\) is the flight acceleration, \(d\) is the flight distance, \(v\) is the flight speed, \(P_0\) is the total motor output power, \(m_0\) is the total mass of the UAV drone, \(\rho\) is the air density, \(C_D\) is the drag coefficient, and \(A_e\) is the effective area affected by air resistance. This formula serves as the foundation for evaluating how different power systems and rotor numbers impact energy efficiency in UAV drones.
To apply this model, I consider three distinct motor power systems commonly used in agricultural UAV drones, each with specific parameters and recommended components. These systems are detailed in the table below, highlighting key specifications such as motor model, KV rating, no-load current, and matched components like propellers, ESCs, and batteries.
| Motor Model | No-load KV (rpm/V) | No-load Current (A) | No-load Voltage (V) | Phase Resistance (mΩ) | Motor Mass (g) | Propeller Specification | ESC (A) | Battery Capacity (mAh) |
|---|---|---|---|---|---|---|---|---|
| X4112S | 450 | 0.7 | 10 | 43 | 169 | 1555/1660 | 80 | 10,000 |
| X5212S | 280 | 0.9 | 10 | 46 | 233 | 2265 | 50 | 10,000 |
| X6215S | 350 | 1.5 | 10 | 15 | 350 | 2265 | 80 | 10,000 |
Using these power systems, I calculate the dynamic energy consumption for UAV drones with rotor numbers ranging from 4 to 10 (i.e., four-rotor to ten-rotor configurations). The total empty mass of each UAV drone varies with rotor number, as additional arms and components increase weight. For instance, with the X4112S motor system, the empty mass rises from approximately 2,000 g for a four-rotor setup to higher values for more rotors, affecting overall performance. To ensure safety, I apply a power redundancy coefficient of 60%, deriving maximum payload limits for each configuration. The relationship between rotor number and maximum payload is summarized below, demonstrating how UAV drones can carry heavier loads as rotor count increases, albeit with trade-offs in energy consumption.
| Rotor Number | Empty Mass (g) for X4112S | Maximum Payload (g) for X4112S | Empty Mass (g) for X5212S | Maximum Payload (g) for X5212S | Empty Mass (g) for X6215S | Maximum Payload (g) for X6215S |
|---|---|---|---|---|---|---|
| 4 | 2,572 | 1,548 | 2,932 | 2,968 | 3,400 | 4,200 |
| 5 | 2,715 | 2,085 | 3,075 | 3,525 | 3,543 | 4,957 |
| 6 | 2,858 | 2,622 | 3,218 | 4,082 | 3,686 | 5,714 |
| 7 | 3,001 | 3,159 | 3,361 | 4,639 | 3,829 | 6,471 |
| 8 | 3,144 | 3,696 | 3,504 | 5,196 | 3,972 | 7,228 |
| 9 | 3,287 | 4,233 | 3,647 | 5,753 | 4,115 | 7,985 |
| 10 | 3,430 | 4,770 | 3,790 | 6,310 | 4,258 | 8,742 |
By inputting parameters from these power systems into the dynamic energy consumption model, I compute energy usage across different payloads for each rotor configuration. The results are plotted as load-dynamic energy consumption curves. A key finding emerges: for UAV drones with the same power system but different rotor numbers, the intersection points of load-energy curves for adjacent rotor configurations (e.g., four-rotor and five-rotor) represent optimal dynamic energy consumption load intersections. These intersections, denoted as \(I_{n/n+1}\), where \(n\) is the rotor number, form the basis for determining optimal payload intervals. For example, with the X4112S motor system, the intersection \(I_{4/5}\) occurs at a payload of 0.07 kg, indicating that for payloads below this value, a four-rotor UAV drone is more energy-efficient, while for payloads above it, a five-rotor configuration is optimal. This pattern holds across all systems, as shown in the table of intersection data below.
| Intersection | Payload for X4112S (kg) | Dynamic Energy for X4112S (kW) | Payload for X5212S (kg) | Dynamic Energy for X5212S (kW) | Payload for X6215S (kg) | Dynamic Energy for X6215S (kW) |
|---|---|---|---|---|---|---|
| I4/5 | 0.07 | 17.259 | 1.29 | 19.287 | 2.52 | 27.987 |
| I5/6 | 0.86 | 20.912 | 2.37 | 23.421 | 3.88 | 34.081 |
| I6/7 | 1.65 | 24.558 | 3.44 | 27.551 | 5.22 | 40.142 |
| I7/8 | 2.44 | 28.221 | 4.51 | 31.681 | 6.56 | 46.199 |
| I8/9 | 3.24 | 31.893 | 5.58 | 35.809 | 7.91 | 52.275 |
| I9/10 | 4.05 | 35.571 | 6.65 | 39.936 | 9.25 | 58.326 |
From these intersections, I derive optimal dynamic energy consumption load intervals. For a given power system, the payload values at intersections \(I_{4/5}, I_{5/6}, \dots, I_{9/10}\) are labeled \(L_1, L_2, \dots, L_6\). These values create intervals where specific rotor numbers yield minimal energy consumption: for example, with the X4112S system, the four-rotor UAV drone is optimal for payloads from 0 to \(L_1\) (0.07 kg), the five-rotor from \(L_1\) to \(L_2\) (0.86 kg), and so on up to the ten-rotor for payloads above \(L_6\) (4.05 kg). This relationship can be generalized with the formula:
$$ X = n \quad \text{for} \quad L_{(n-4)} \leq L < L_{(n-3)}, \quad n \geq 4 $$
where \(X\) is the recommended rotor number for optimal energy consumption, \(n\) is the rotor number, \(L\) is the target payload, and \(L_{(0)} = 0\). This formula provides a straightforward method for configuring UAV drones to achieve energy efficiency based on payload requirements.
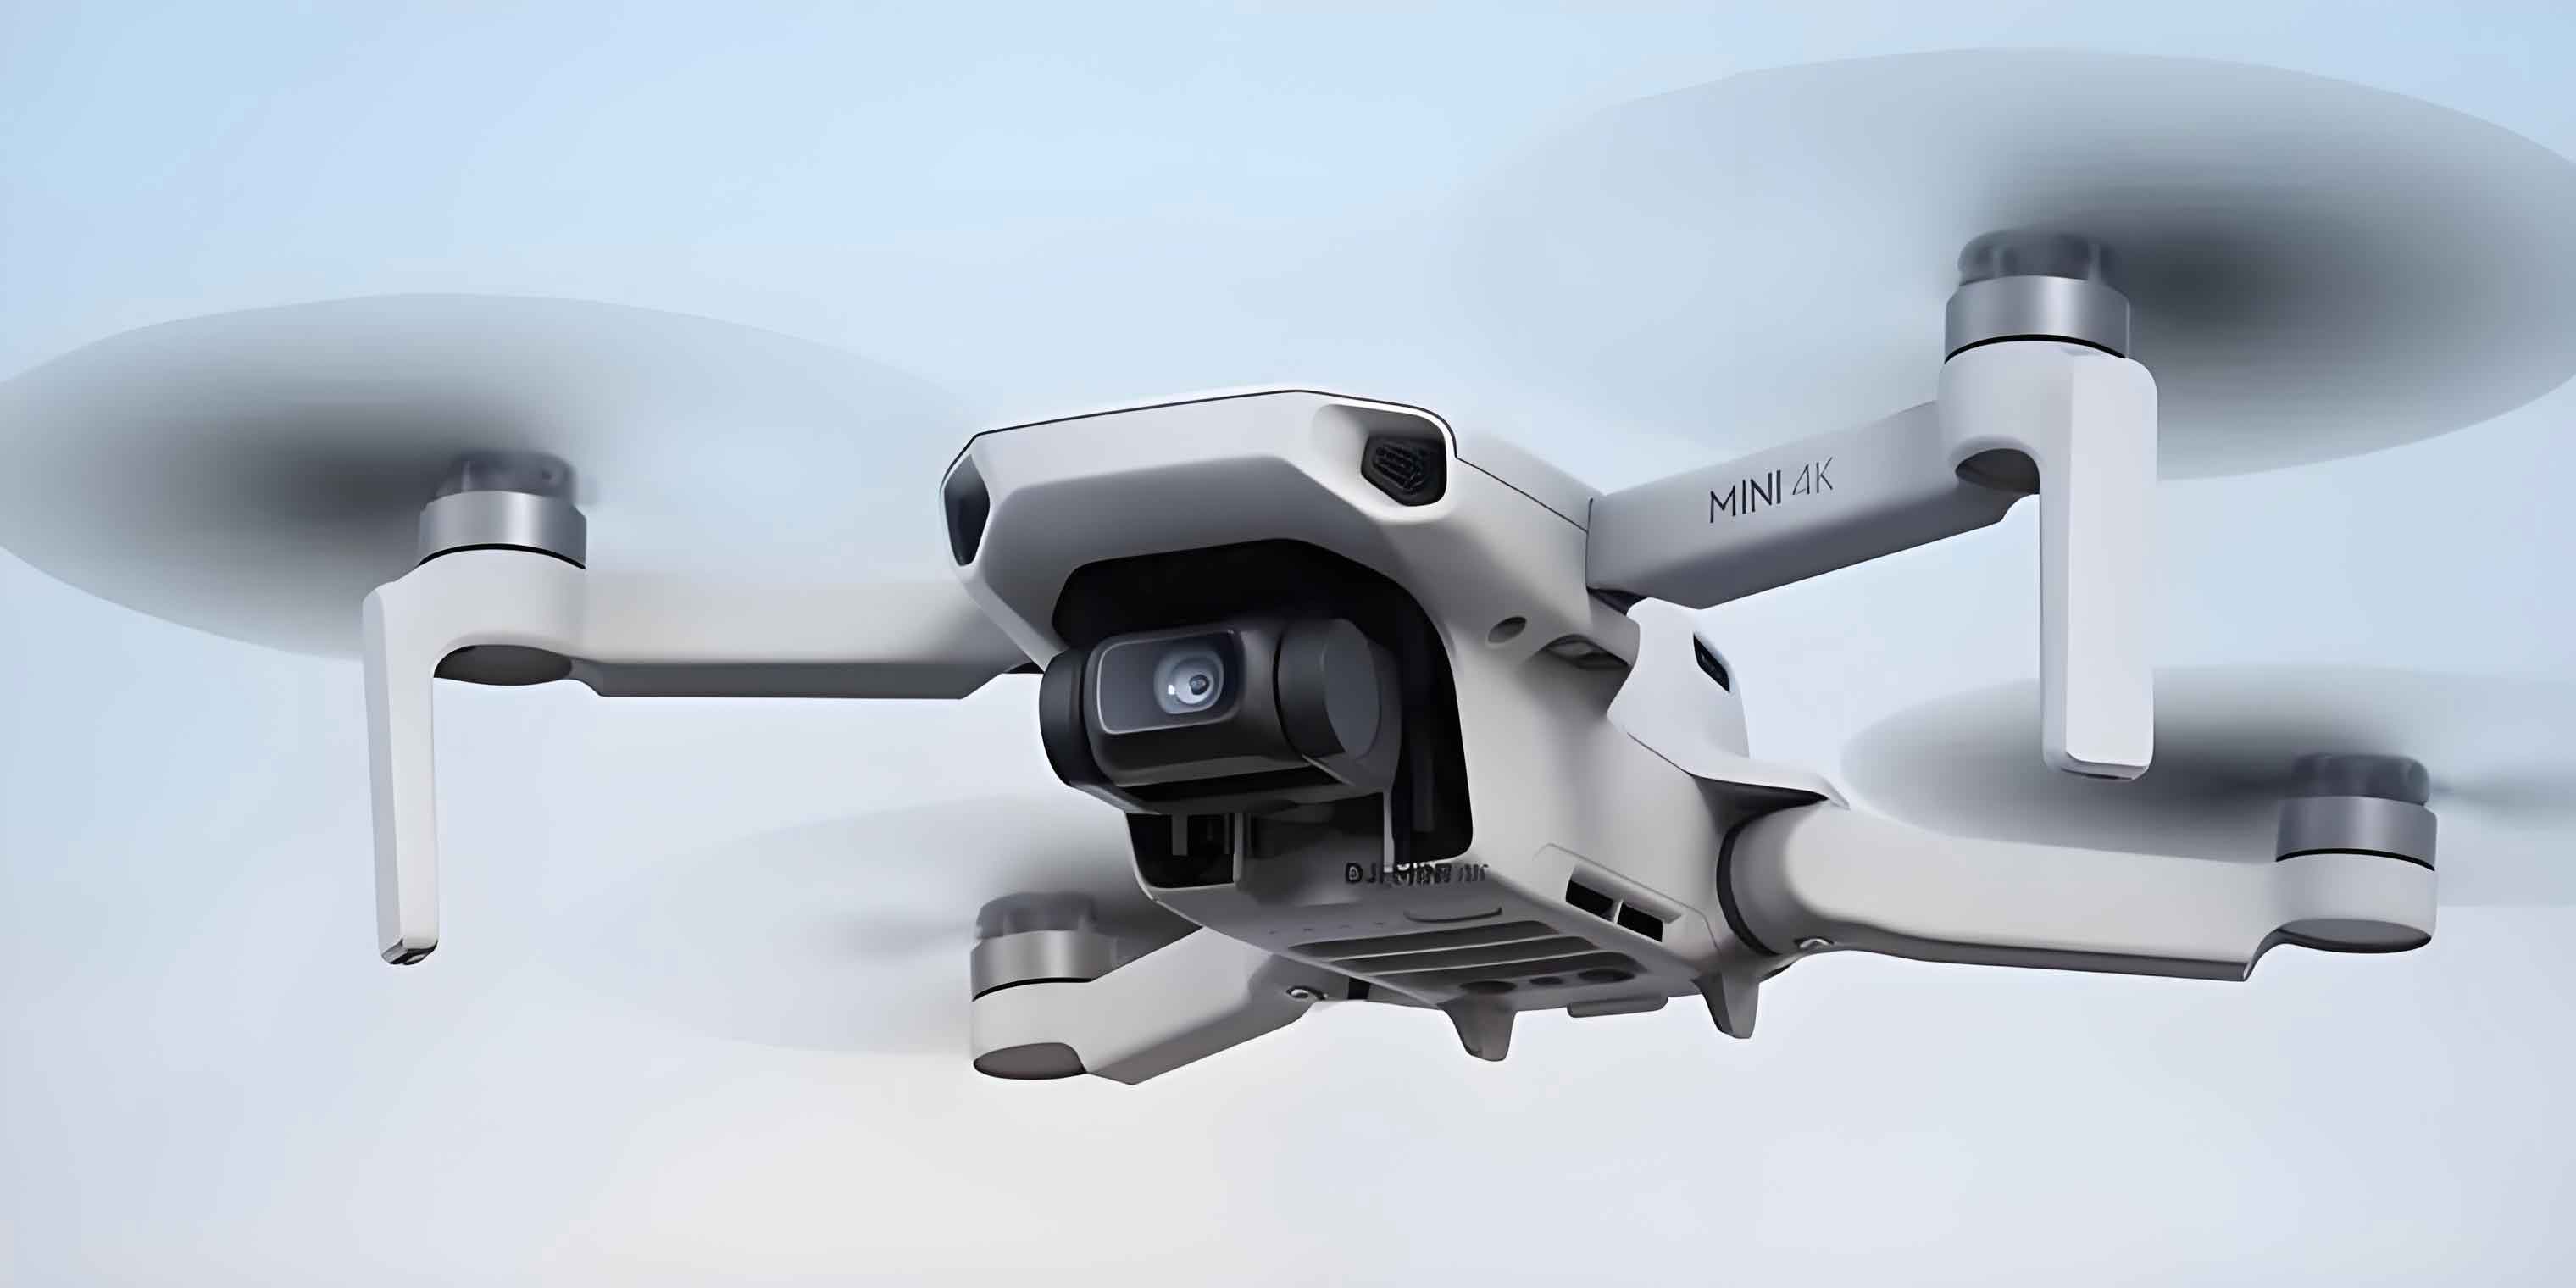
To validate this theoretical framework, I conduct flight verification tests using custom-assembled agricultural UAV drones with four, six, and eight rotors. All UAV drones are equipped with the X4112S 450KV motor system, paired with 1555 propellers, 60 A ESCs, and 10,000 mAh lithium batteries. I ensure consistent轴距 across configurations by redesigning the center plates using AutoCAD, minimizing structural variations that could affect energy consumption. The flight parameters are set as follows: acceleration of 1 m/s², speed of 5 m/s, altitude of 5 m, and a flight distance of 100 m. Environmental conditions are controlled at 15°C, with an air density of 1.23 kg/m³ calculated via Python. Each UAV drone undergoes multiple flights with payloads ranging from 0 to 3.5 kg at 0.5 kg intervals, totaling 80 flights (16 for four-rotor, 32 for six-rotor, and 32 for eight-rotor).
For data acquisition, I employ a dynamic energy consumption testing system comprising an onboard sky module and a ground base station. The onboard module includes a power meter connected between the energy output and input of the UAV drone, a定位 module for real-time positioning, and an onboard computer for data analysis. The ground station provides centimeter-level RTK positioning via a data link. During flights, I use Mission Planner to log data, convert it to KML format, and visualize trajectories in Google Earth. The collected data includes power consumption and flight dynamics, which I process to compute actual dynamic energy consumption for each payload and rotor configuration.
The experimental results reveal a close alignment between measured dynamic energy consumption and theoretical values. For the four-rotor UAV drone, the average error between test and theoretical values is 3.22%; for the six-rotor, it is 2.87%; and for the eight-rotor, it is 2.85%. These low errors confirm the accuracy of the dynamic energy consumption model for UAV drones. I perform linear fitting on the data, achieving R² values above 0.98 for all configurations, indicating strong correlation. The fitted curves intersect at points analogous to the theoretical intersections, substantiating the existence of optimal dynamic energy consumption load intervals. For instance, with the X4112S system, the intersection \(A\) between four- and six-rotor curves occurs at a payload of approximately 0.2 kg, while intersection \(C\) between six- and eight-rotor curves is near 2.0 kg. These define intervals where each rotor number minimizes energy consumption: 0–0.2 kg for four-rotor, 0.2–2.0 kg for six-rotor, and above 2.0 kg for eight-rotor UAV drones.
To refine these intervals, I analyze errors between test and theoretical data, identifying effective and failure zones for optimal dynamic energy consumption loads. Effective zones are ranges where the theoretical method yields accurate results, while failure zones are where discrepancies arise due to model limitations. For the tested UAV drones, the failure zones are centered around intersection points with small tolerances: for intersection \(A\) (four- and six-rotor), the failure zone is \(0.2 \pm 0.036\) kg; for \(B\) (four- and eight-rotor), \(0.88 \pm 0.098\) kg; and for \(C\) (six- and eight-rotor), \(2.0 \pm 0.076\) kg. Outside these zones, the optimal payload intervals are reliable, enabling precise configuration of UAV drones for energy efficiency.
The implications of this research are profound for the design and operation of agricultural UAV drones. By applying the dynamic energy consumption model and intersection analysis, designers can select rotor numbers and payloads that minimize energy use, extending flight endurance and reducing operational costs. For example, if a farming task requires a payload of 1.5 kg, the method recommends a six-rotor UAV drone with the X4112S system for optimal efficiency. This approach not only enhances the performance of individual UAV drones but also contributes to sustainable agriculture by lowering energy consumption. Furthermore, the testing system developed here provides a robust framework for future evaluations of UAV drone technologies.
In conclusion, this study establishes a systematic method for optimal power-load matching in agricultural multi-rotor UAV drones. Through theoretical modeling and experimental validation, I demonstrate that dynamic energy consumption can be minimized by configuring payloads based on rotor numbers and power systems. The key findings include the derivation of optimal load intervals from intersection points of energy curves, with validation showing average errors below 3.3% across configurations. The identification of effective and failure zones further refines these intervals, offering practical guidance for UAV drone design. As UAV drones continue to evolve in agriculture, this work provides a valuable reference for optimizing energy efficiency, with potential applications in other domains such as logistics or environmental monitoring. Future research could explore additional factors like wind conditions or battery aging to enhance the model’s robustness for real-world UAV drone operations.