
I investigate how a UAV drone can plan safe, efficient, and smooth three-dimensional paths in two low-altitude environments that are fundamentally different: mountainous terrain with continuous elevation surfaces and urban terrain with dense regular obstacles. The central difficulty is not merely to find a feasible route, but to satisfy flight constraints, avoid collisions, reduce path length, and maintain stability under a limited computational budget. My work therefore develops two improved swarm intelligence optimizers, one for mountain-like terrain and one for city-like terrain, and validates them from benchmark functions to embedded hardware and real flight tests. The keyword throughout my study is the UAV drone, because every mathematical model, algorithmic modification, and experimental result is ultimately evaluated by whether it improves UAV drone autonomy.
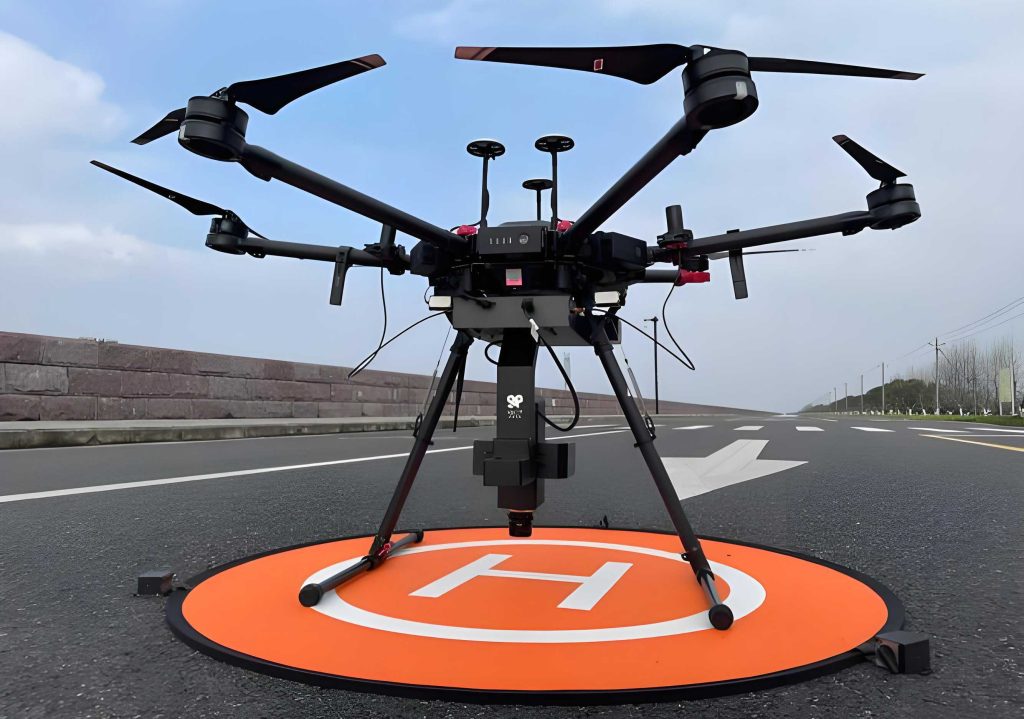
Motivation and scope. A UAV drone operating at low altitude faces different risks from a ground robot. It must respect altitude limits, turning limits, climb and dive limits, and segment-length limits. In mountainous regions, the terrain is non-flat and continuous, so the UAV drone must frequently climb and descend. In urban regions, buildings create narrow corridors and dense obstacle fields, so the UAV drone must exploit limited free space. I therefore treat path planning as a constrained optimization problem that balances length, smoothness, safety, and computational cost. My objective is to design improved swarm intelligence algorithms that can support a UAV drone in both environments without relying on excessively large populations or very long iteration counts.
Three-dimensional environment modeling. I represent the flight space as a bounded three-dimensional region. The UAV drone must remain inside the spatial limits:
$$0 \le x \le x_{\max}, \quad 0 \le y \le y_{\max}, \quad 0 \le z \le z_{\max}$$
For mountainous terrain, I use a digital elevation model because it gives a continuous elevation surface. The height can be written as a function of horizontal coordinates:
$$z = f(x,y)$$
This model allows the UAV drone to respond to peaks, ridges, valleys, and slopes. For urban terrain, I use regular obstacles with known centers, widths, lengths, and heights. This representation is suitable for dense building-like obstacle fields, because the UAV drone can be checked against each obstacle volume. In both cases, the planning result is a sequence of waypoints that the UAV drone must follow after smoothing.
Path constraints for a UAV drone. I impose several hard constraints. The altitude constraint prevents the UAV drone from flying too close to the ground or to obstacle surfaces:
$$H_i \ge H_{\min}, \quad i=1,2,\ldots,n$$
The segment-length constraint prevents abrupt changes between waypoints:
$$l_i \ge l_{\min}$$
The turning-angle constraint limits horizontal turns:
$$\frac{\mathbf{a}_i^{T}\mathbf{a}_{i+1}}{\|\mathbf{a}_i\|\|\mathbf{a}_{i+1}\|} \ge \cos\psi, \quad i=2,3,\ldots,n-1$$
The climb and dive constraint limits vertical motion:
$$\left|\frac{z_i-z_{i-1}}{\|\mathbf{a}_i\|}\right| \le \tan\theta$$
The total length constraint limits the mission range:
$$\sum_{i=1}^{n} l_i \le L_{\max}$$
I combine these factors into a scalar cost function. The UAV drone path cost is:
$$C = w_1 \sum_{i=1}^{n} l_i + w_2 \sum_{i=1}^{n} h_i + w_3 \sum_{i=1}^{n} g_i$$
where \(h_i\) is the altitude term, \(g_i\) is the threat or obstacle term, and the weights satisfy:
$$w_1 + w_2 + w_3 = 1$$
For many of my experiments, the geometric length term is the dominant fitness component, but the UAV drone still must respect all safety constraints. The path length fitness is:
$$fit = \sum_{i=1}^{m} \sqrt{(x_{i+1}-x_i)^2 + (y_{i+1}-y_i)^2}$$
I also smooth the optimized waypoints with cubic spline interpolation. This step is important because a raw waypoint sequence may be geometrically short but dynamically infeasible for a UAV drone. Cubic spline interpolation produces a continuous and smooth trajectory:
$$S_k(x) = a_k + b_k(x-x_k) + c_k(x-x_k)^2 + d_k(x-x_k)^3$$
where each interval is connected with continuous first and second derivatives. This smoothing step makes the path more suitable for a real UAV drone controller.
| Constraint or objective | Mathematical role | Effect on UAV drone planning |
|---|---|---|
| Altitude limit | \(H_i \ge H_{\min}\) | Prevents ground collision and low-altitude risk |
| Segment length | \(l_i \ge l_{\min}\) | Avoids extremely short and unstable turns |
| Turning angle | \(\cos^{-1}\) of horizontal segment dot product is bounded | Keeps turns within UAV drone maneuverability |
| Climb and dive angle | \(\left|(z_i-z_{i-1})/\|\mathbf{a}_i\|\right| \le \tan\theta\) | Controls vertical safety and energy use |
| Maximum length | \(\sum l_i \le L_{\max}\) | Ensures mission feasibility |
| Weighted cost | \(C = w_1\sum l_i + w_2\sum h_i + w_3\sum g_i\) | Balances length, altitude, and threat |
Benchmark evaluation philosophy. I evaluate the optimizers on the CEC2005 benchmark suite because it contains unimodal, noisy, multimodal, and fixed-dimension composite functions. Unimodal functions test convergence speed. Multimodal functions test the ability to escape local optima. Fixed-dimension functions test robustness under complex variable interactions. For a UAV drone path planner, these properties matter because the terrain and obstacle fields are nonconvex and often contain many local minima. I use mean, standard deviation, and rank as primary metrics.
$$\text{Mean} = \frac{1}{S}\sum_{i=1}^{S} C_i$$
$$\text{Std} = \sqrt{\frac{1}{S-1}\sum_{i=1}^{S}(C_i-\bar{C})^2}$$
I also use Friedman ranking and Wilcoxon signed-rank testing to compare algorithms statistically. The Friedman test assigns a rank to each optimizer on each function, while the Wilcoxon test evaluates whether pairwise performance differences are significant.
| Benchmark group | Functions | Primary purpose | Relevance to UAV drone |
|---|---|---|---|
| Unimodal | f1–f5 | Measure convergence accuracy and speed | Fast descent in simple terrain valleys |
| Step and noisy | f6–f7 | Test discontinuity and noise tolerance | Sensor noise and discrete obstacle maps |
| Multimodal | f8–f13 | Test local-optimum avoidance | Mountain peaks and urban corridors |
| Fixed-dimension composite | f14–f23 | Test complex variable coupling | Mixed terrain and obstacle interactions |
Original hippopotamus optimization behavior. I use the hippopotamus optimizer as the base for mountainous UAV drone planning because it models herd behavior, defensive reaction, and escape. The population is initialized as:
$$X_i = lb + rand(ub-lb)$$
The male hippopotamus position is updated by:
$$X_i^{Mhipoo} = x_{ij} + y_1(D_{hippo}-I_1 x_{ij})$$
The female and juvenile position is updated by:
$$X_i^{FBhippo} = x_{ij} + h_1(D_{hippo}-I_2 MG_i)$$
when the separation factor is large. The separation factor originally decreases with iteration:
$$T = \exp(-t/t_{\max})$$
However, a fixed decreasing factor can make the search inflexible. I therefore replace it with a growth-ratio mechanism. The defense phase is modeled by:
$$D = P_j – x_{ij}$$
$$X_i^{HR} = R_L \oplus P_j + (f\cos(2\pi d)+g)D$$
The escape phase uses a local safety region:
$$X_i^{Hs} = x_{ij} + rand_3(lb_j^{local} + s(ub_j^{local}-lb_j^{local}))$$
Although the original optimizer has good exploration, it can stagnate on continuous mountain surfaces. My UAV drone experiments show that local optima often appear near ridges and narrow valleys, so a stronger balance between exploration and exploitation is required.
DMHO: multi-strategy improved hippopotamus optimization. I propose DMHO for mountainous UAV drone path planning. DMHO integrates four mechanisms. First, Lévy flight initialization increases initial diversity. Second, a dynamic growth ratio changes the separation behavior according to fitness. Third, adaptive prism opposition-based learning improves the ability to escape local optima. Fourth, random diffusion models the UAV drone’s attempt to leave a dangerous region. The initial position is generated by:
$$X_i = X_{\min} + L(\lambda)(X_{\max}-X_{\min})$$
The Lévy step is drawn from a heavy-tailed distribution:
$$L(\lambda) \sim \frac{u}{|v|^{1/\lambda}}$$
This initialization helps the UAV drone planner sample far-separated regions of the mountain terrain instead of clustering around one slope. The dynamic growth ratio is:
$$T = \frac{f_{\text{best}}}{f_i}$$
If an individual has a good fitness value, it can move farther from the group, which increases the chance of discovering a better UAV drone corridor. The adaptive prism opposition-based learning rule is:
$$x^{*} = \frac{lb+ub}{2} + \frac{lb+ub}{2k} – \frac{x}{k}$$
where the lens-like scaling factor is:
$$k = \left(1 + \frac{iter}{iter_{\max}}\right)^{10}$$
This rule creates an opposite candidate that changes from wide exploration to focused refinement. The random diffusion step is:
$$s = 0.1 R(1,d)(u_b-l_b)$$
$$X_{i+1} = X_i + s$$
For a UAV drone, this behavior is analogous to a sudden safe retreat when a predator or obstacle cluster blocks the current corridor.
| DMHO strategy | Core expression | Influence on UAV drone path planning |
|---|---|---|
| Lévy flight initialization | \(X_i = X_{\min} + L(\lambda)(X_{\max}-X_{\min})\) | More diverse initial mountain corridors |
| Dynamic growth ratio | \(T = f_{\text{best}}/f_i\) | Adaptive separation and better convergence |
| Adaptive prism opposition | \(x^{*} = (lb+ub)/2 + (lb+ub)/(2k) – x/k\) | Escapes ridge and valley local optima |
| Random diffusion | \(s = 0.1R(1,d)(u_b-l_b)\) | Improves safety recovery in blocked regions |
DMHO algorithm flow. I initialize the population with Lévy flight. I evaluate each candidate path. I update the dominant hippopotamus. I split the population into male and female or juvenile groups. I use the dynamic growth ratio instead of a fixed decreasing threshold. I generate predator positions and update defensive behavior. I apply adaptive prism opposition-based learning to improve the best candidates. I apply random diffusion when the search is trapped. I repeat until the maximum iteration count is reached, and then I output the best UAV drone path.
DMHO sensitivity and benchmark comparison. I fix the number of fitness evaluations to 15000 and compare population/iteration combinations. The combination 30/500 gives the best overall rank in my tests. I compare DMHO with several widely used optimizers, including particle swarm optimization, grey wolf optimizer, gravitational search algorithm, Harris hawks optimizer, honey badger algorithm, dung beetle optimizer, fire hawk optimizer, and the original hippopotamus optimizer. On the 23 CEC2005 functions, DMHO obtains the best mean on most functions and the best standard deviation on many functions. Its average winning rate is high, and its Friedman rank is first among the compared methods.
| Population/iteration setting | Rank total | Average rank | Final rank |
|---|---|---|---|
| 20/750 | 42.0 | 1.8261 | 2 |
| 30/500 | 38.5 | 1.6739 | 1 |
| 60/250 | 57.5 | 2.5000 | 3 |
| Method | Friedman rank total | Average rank | Overall position |
|---|---|---|---|
| DMHO | 50.5 | 2.1956 | 1 |
| Original hippopotamus optimizer | 63.0 | 2.7391 | 2 |
| Gravitational search algorithm | 95.0 | 4.1304 | 3 |
| Harris hawks optimizer | 117.0 | 5.0870 | 4 |
| Fire hawk optimizer | 129.5 | 5.6304 | 5 |
| Honey badger algorithm | 128.5 | 5.5870 | 6 |
| Dung beetle optimizer | 134.0 | 5.8261 | 7 |
| Grey wolf optimizer | 155.0 | 6.7391 | 8 |
| Particle swarm optimization | 162.5 | 7.0652 | 9 |
Mountainous UAV drone path planning with DMHO. I build three mountain-like environments. Environment 1 contains fewer peaks and represents moderate complexity. Environment 2 contains many peaks and steep slopes. Environment 3 represents a transition between mountain and plateau terrain. The UAV drone starts and ends at different coordinates, and the altitude surface is continuous. I set a minimum flight height, a maximum turning angle, a maximum climb and dive angle, and a maximum path length. The optimization goal is to find a smooth path that avoids peaks, respects altitude, and minimizes length.
| Mountain environment | Terrain character | Main challenge for UAV drone |
|---|---|---|
| Environment 1 | Fewer peaks, moderate elevation changes | Balancing length and smoothness |
| Environment 2 | Dense peaks, steep local slopes | Avoiding local optima and sharp climbs |
| Environment 3 | Mixed mountain and plateau features | Maintaining stable altitude and turning |
| Algorithm | Environment 1 mean | Environment 1 std | Environment 2 mean | Environment 2 std | Environment 3 mean | Environment 3 std |
|---|---|---|---|---|---|---|
| DMHO | 2838.1 | 1.3984 | 2828.5 | 0.3433 | 1226.1 | 6.7142 |
| Original hippopotamus optimizer | 2841.2 | 2.0993 | 2842.4 | 1.2625 | 1226.8 | 7.2257 |
| Particle swarm optimization | 2850.1 | 3.5105 | 2839.9 | 1.3923 | 1578.9 | 82.644 |
| Grey wolf optimizer | 2859.1 | 5.1296 | 2847.6 | 0.6789 | 1241.0 | 4.7864 |
| Honey badger algorithm | 2856.2 | 3.5068 | 2833.9 | 0.7862 | 1251.5 | 8.1989 |
In all three mountain environments, DMHO obtains the lowest average fitness and a small standard deviation. Compared with the original hippopotamus optimizer, DMHO reduces the standard deviation substantially in the first two environments and slightly in the third. The resulting UAV drone paths are shorter, smoother, and more consistent with flight constraints. The convergence curves show that DMHO reaches a stable value earlier than most comparison algorithms, which is important because a real UAV drone may need to replan quickly when the mission changes.
Original honey badger optimization behavior. For urban UAV drone planning, I start from the honey badger algorithm. The population is initialized by:
$$x_{ij} = lb_j + r_1(ub_j-lb_j)$$
The odor intensity is:
$$I_i = r_2 \frac{S}{4\pi d_i^2}$$
where the source strength and distance are:
$$S = (x_i-x_{i+1})^2$$
$$d_i = x_{prey}-x_i$$
The original density factor is:
$$\alpha = C\exp(-t/t_{\max})$$
The digging phase is:
$$x_{new} = x_{prey} + F\beta I x_{prey} + F r_3 \alpha d_i |\cos(2\pi r_4)(1-\cos(2\pi r_5))|$$
The honey phase is:
$$x_{new} = x_{prey} + F r_7 \alpha d_i$$
This algorithm has strong local search behavior, but in dense urban obstacle fields it can converge prematurely. A UAV drone in a city must explore multiple narrow corridors before committing to one route. Therefore, I introduce three modifications.
MIHBA: multi-strategy improved honey badger algorithm. First, I use Halton sequence initialization. The Halton sequence creates a low-discrepancy distribution:
$$n = \sum_{i=0}^{m-1} b_i p^i$$
$$\phi_p(n) = \sum_{i=0}^{m-1} b_i p^{-i-1}$$
$$H(n) = [\phi_{p1}(n), \phi_{p2}(n)]$$
This gives the UAV drone a more uniform set of initial urban corridors. Second, I replace the original density factor with a water-wave dynamic density factor:
$$\alpha = 2 \exp(-t/t_{\max}) \cdot r \cdot S$$
This factor introduces dynamic uncertainty and helps the swarm avoid premature convergence. Third, I use adaptive learning-rate prism opposition-based learning. The opposite point is:
$$x^{*} = \frac{lb+ub}{2} + \frac{lb+ub}{2k} – \frac{x}{k}$$
$$k = \left(1 + \frac{iter}{iter_{\max}}\right)^{10}$$
This mechanism improves the chance that the UAV drone escapes a local urban trap, such as a dead-end street or a narrow gap between high buildings.
| MIHBA strategy | Core expression | Benefit for urban UAV drone |
|---|---|---|
| Halton initialization | \(H(n) = [\phi_{p1}(n), \phi_{p2}(n)]\) | Uniform coverage of urban free space |
| Water-wave density factor | \(\alpha = 2\exp(-t/t_{\max})rS\) | Balances exploration and exploitation |
| Adaptive prism opposition | \(x^{*} = (lb+ub)/2 + (lb+ub)/(2k) – x/k\) | Escapes narrow-corridor local optima |
MIHBA sensitivity, comparison, and ablation. I again fix the total fitness evaluations and compare population/iteration settings. The setting 30/500 gives the best overall rank. I compare MIHBA with non-monopolize search, particle swarm optimization, genetic algorithm, dung beetle optimizer, and the original honey badger algorithm. MIHBA obtains the best mean on many unimodal, multimodal, and fixed-dimension functions. I also perform an ablation study with combinations of Halton initialization, water-wave density, and prism opposition. The full MIHBA configuration performs best overall. Friedman testing places MIHBA first, and Wilcoxon signed-rank testing shows significant differences from most compared algorithms.
| Population/iteration setting | Rank total | Average rank | Final rank |
|---|---|---|---|
| 15/1000 | 50.0 | 2.174 | 3 |
| 30/500 | 43.0 | 1.869 | 1 |
| 60/250 | 45.0 | 1.957 | 2 |
| Method | Rank total | Average rank | Final position |
|---|---|---|---|
| MIHBA | 41.5 | 2.7667 | 1 |
| HBA12 | 64.0 | 4.2667 | 2 |
| HBA13 | 65.5 | 4.3667 | 3 |
| HBA3 | 78.5 | 5.2333 | 4 |
| HBA1 | 85.5 | 5.7000 | 5.5 |
| HBA23 | 85.5 | 5.7000 | 5.5 |
| HBA2 | 92.5 | 6.1667 | 7 |
| HBA | 110.5 | 7.3667 | 8 |
| Dung beetle optimizer | 114.0 | 7.6000 | 9 |
| Particle swarm optimization | 126.5 | 8.4333 | 10 |
| Non-monopolize search | 134.0 | 8.9333 | 11 |
| Genetic algorithm | 172.0 | 11.4667 | 12 |
Urban UAV drone path planning with MIHBA. I construct three urban environments. Environment 4 resembles a residential area with scattered low buildings. Environment 5 resembles a commercial district with dense L-shaped obstacles. Environment 6 resembles a mixed community with low-rise, mid-rise, and high-rise zones. The flight volume increases across the three environments, so the UAV drone must search a larger space. I use a small iteration budget because urban replanning should be fast. The UAV drone must avoid all buildings while minimizing path length and maintaining smooth turns.
| Urban environment | Layout character | Main challenge for UAV drone |
|---|---|---|
| Environment 4 | Scattered low-rise blocks | Selecting a short route without unnecessary detours |
| Environment 5 | Dense commercial blocks and L-shaped obstacles | Finding narrow feasible corridors |
| Environment 6 | Mixed low, middle, and high buildings | Managing large search space and altitude changes |
| Algorithm | Environment 4 mean | Environment 4 std | Environment 5 mean | Environment 5 std | Environment 6 mean | Environment 6 std |
|---|---|---|---|---|---|---|
| MIHBA | 161.67 | 2.27 | 334.42 | 5.27 | 541.62 | 63.95 |
| HBA | 164.35 | 11.87 | 338.17 | 66.66 | 549.97 | 82.67 |
| Particle swarm optimization | 163.99 | 7.90 | 348.70 | 30.91 | 553.07 | 43.22 |
| Genetic algorithm | 429.38 | 0.00 | 425.71 | 0.00 | 1000.00 | 0.00 |
| Dung beetle optimizer | 166.68 | 8.25 | 386.18 | 107.54 | 555.70 | 47.66 |
The urban results show that MIHBA reaches the lowest mean fitness in all three environments and usually has the smallest standard deviation. The UAV drone paths generated by MIHBA use the available free space more effectively. The convergence curves show that MIHBA stabilizes faster than the original honey badger algorithm, which is critical when a UAV drone must respond to a sudden obstacle or a no-fly instruction. The ablation and statistical tests confirm that each proposed mechanism contributes to the final performance, and the full MIHBA configuration is the most reliable for urban UAV drone path planning.
Hardware platform and control architecture. I build a modular quadrotor platform for real UAV drone validation. The platform contains a lightweight frame, a flight controller, an embedded AI computer, a depth camera, telemetry, and a ground control station. The AI computer performs high-level path planning and perception. The flight controller executes attitude and position control. The depth camera supplies environment information. The ground station is used for monitoring, mode switching, and emergency handling. The control module checks whether the UAV drone is ready, whether localization is valid, and whether the geofence is satisfied. It then sends waypoint commands through a MAVLink bridge and receives state feedback.
| Subsystem | Function | Interaction with UAV drone planning |
|---|---|---|
| Flight controller | Attitude and position stabilization | Executes waypoint and velocity commands |
| Embedded AI computer | Path planning and perception | Runs DMHO and MIHBA online |
| Depth camera | Local environment sensing | Supports obstacle avoidance and map checking |
| Telemetry | Data link | Transmits status and command data |
| Ground control station | Monitoring and safety override | Provides human supervision of UAV drone |
Real-world validation in mountain-like and city-like scenes. I select two outdoor test areas. One area contains tree rows and narrow passages that imitate the canyon effect of an urban environment. The other area contains uneven terrain and slopes that imitate mountain-like relief. I scale the maps to match the test field. I run the improved algorithms, compare them with their baseline algorithms, and then deploy the best path to the real UAV drone. The mountain-like test shows that DMHO improves fitness by 2.96% over the original hippopotamus optimizer. The city-like test shows that MIHBA improves fitness by 1.57% over the original honey badger algorithm. The UAV drone follows the smoothed paths and completes the missions, which demonstrates that the simulation-to-reality transfer is practical.
| Validation scene | Base algorithm | Improved algorithm | Base fitness | Improved fitness | Improvement |
|---|---|---|---|---|---|
| Mountain-like terrain | Original hippopotamus optimizer | DMHO | 254.0867 | 246.5667 | 2.96% |
| City-like obstacle field | Original honey badger algorithm | MIHBA | 156.3398 | 153.8886 | 1.57% |
Interpretation for UAV drone autonomy. The most important outcome of my work is that a UAV drone can benefit from algorithm-specific improvements rather than a one-size-fits-all planner. In mountain terrain, the continuous elevation surface rewards strong global exploration and smooth altitude transitions. DMHO succeeds because Lévy initialization, dynamic growth ratio, adaptive prism opposition, and random diffusion prevent the search from being trapped on a single ridge. In urban terrain, the dense regular obstacles reward uniform initialization and dynamic adaptation. MIHBA succeeds because Halton initialization covers the free space more evenly, the water-wave density factor maintains search diversity, and prism opposition learning helps the UAV drone escape narrow corridors.
Statistical reliability. I do not rely only on visual convergence curves. I use repeated independent runs, mean and standard deviation, Friedman ranking, and Wilcoxon signed-rank tests. This is important for a UAV drone because a planner that succeeds once but fails often is not safe. My results show that the improved algorithms are not only better on average but also more stable across repeated trials. The lower standard deviation means the UAV drone is more likely to obtain a similar path when the mission is repeated. The higher rank means the algorithm is more robust across different terrain types and obstacle densities.
| Evaluation dimension | DMHO for mountain UAV drone | MIHBA for urban UAV drone |
|---|---|---|
| Global exploration | Strong, due to Lévy initialization and random diffusion | Strong, due to Halton initialization and water-wave density |
| Local exploitation | Improved by adaptive prism opposition | Improved by adaptive prism opposition |
| Local-optimum escape | High in ridge and valley terrain | High in dense building corridors |
| Path smoothness | Enhanced by cubic spline interpolation | Enhanced by cubic spline interpolation |
| Real-flight validation | 2.96% fitness improvement | 1.57% fitness improvement |
Conclusion of my study. I have designed, tested, and validated two improved swarm intelligence algorithms for UAV drone path planning. The first, DMHO, targets mountainous terrain with continuous elevation surfaces. The second, MIHBA, targets urban terrain with dense regular obstacles. Both algorithms use multi-strategy improvements to balance global exploration and local exploitation. Benchmark tests show strong convergence accuracy and stability. Three-dimensional simulation tests show shorter and smoother paths. Hardware tests and real flights show that the optimized paths can be executed by a UAV drone. I conclude that improved swarm intelligence is a practical and effective foundation for autonomous UAV drone navigation in complex low-altitude environments.
Future work. I plan to refine the internal mechanisms of both algorithms so that the UAV drone can adapt parameters online when the environment changes. I also intend to combine the planners with reactive methods such as artificial potential fields and model predictive control. This would allow a UAV drone to respond to moving obstacles, sudden wind disturbances, and dynamic no-fly zones. Another direction is multi-UAV drone cooperation, where several UAV drone platforms share map updates and task assignments. Finally, I will extend the validation to more diverse real-world scenes, including forest edges, industrial sites, and dense residential areas, so that the algorithms can be tested under a wider range of sensing and communication conditions.