
In the realm of emergency response, the rapid acquisition of accurate disaster information is paramount for effective decision-making and enhancing rescue efficiency. Through my involvement in recent large-scale flood relief operations, I have witnessed firsthand the transformative role of fire UAV (unmanned aerial vehicle) systems. These advanced platforms, equipped with high-altitude reconnaissance, emergency mapping, and versatile payload capabilities, have become indispensable tools. In this article, I will delve into the practical applications, methodologies, and lessons learned from deploying fire UAVs in complex disaster scenarios, emphasizing their integration into tactical frameworks. The core keyword—fire UAV—will be reiterated throughout to underscore its centrality in modern firefighting and rescue aviation.
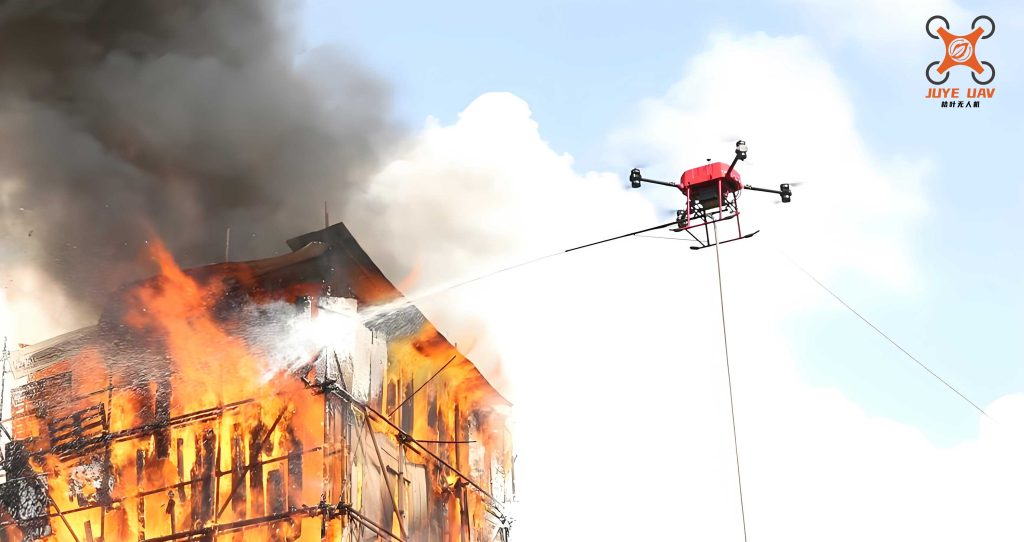
The operational paradigm for fire UAV deployment hinges on a synergistic approach combining long-endurance fixed-wing drones with agile multi-rotor systems. This “high-low mix” strategy enables both broad-area surveillance and precise, localized inspection. For instance, during a major flood event covering over 300 square kilometers, our team employed this dual-system architecture. The long-endurance fixed-wing fire UAV operated at altitudes around 1000 meters, conducting wide-area tactical reconnaissance. Meanwhile, smaller multi-rotor fire UAV units handled point-specific tasks. The effectiveness of such coverage can be modeled using a basic reconnaissance area formula:
$$A_{total} = \sum_{i=1}^{n} (v_i \times t_i \times w_i)$$
where \(A_{total}\) is the total area covered, \(v_i\) is the velocity of the i-th fire UAV, \(t_i\) is its flight time, and \(w_i\) is the effective imaging swath width. This formula highlights how fire UAV endurance and speed directly impact situational awareness.
To quantify the missions, the following table summarizes a typical operational cycle for fire UAV assets in such environments:
| Fire UAV Type | Mission Profile | Sorties Flown | Images Captured | Ground Resolution | Key Intelligence Gathered |
|---|---|---|---|---|---|
| Long-Endurance Fixed-Wing | High-Altitude Broad Area Scan | 11 | 9900 | 10 cm | Breach locations, extent of urban inundation |
| Vertical Take-Off and Landing (VTOL) Fixed-Wing | Rapid Deployment Tactical Mapping | 8 | 7200 | 5-7 cm | Detailed floodwater boundaries, infrastructure status |
| Multi-Rotor (Heavy Lift) | Close-Range Inspection & Payload Delivery | 25+ | N/A (Live Video) | <3 cm | Real-time structural damage, survivor spotting |
The data acquisition rate of a fire UAV system is critical. We can express the information yield \(I\) as:
$$I = \frac{N_{img} \times R_{px}^2 \times B_{depth}}{t_{proc}}$$
Here, \(N_{img}\) is the number of images, \(R_{px}\) is the spatial resolution in pixels per meter, \(B_{depth}\) is the bit depth of the imagery, and \(t_{proc}\) is the processing time. Optimizing this yield is a constant focus for fire UAV teams.
Once imagery is captured, the challenge shifts to rapid processing and dissemination. In disrupted environments with intermittent communication networks, we established forward and rear data processing cells. The fire UAV management system generated shareable links, allowing commanders to access video feeds, panoramas, and 2D/3D models directly on mobile devices without installing specialized software. This drastically reduced the decision-loop time. The efficiency of this information pipeline can be represented by a simplified latency model:
$$T_{latency} = T_{acq} + T_{proc} + T_{trans} + T_{access}$$
where \(T_{acq}\) is fire UAV acquisition time, \(T_{proc}\) is data processing time, \(T_{trans}\) is transmission time, and \(T_{access}\) is user access time. Our goal was to minimize each component, with the fire UAV’s role being central to reducing \(T_{acq}\). A daily product was the “Road Submerged Status Map,” which used a three-color coding system (green for clear, yellow for partially submerged, red for impassable) derived directly from fire UAV orthomosaics. This tool was essential for planning rescue and drainage operations.
The tactical flexibility of the fire UAV proved invaluable across diverse rescue scenarios. Each fire UAV platform could be configured with modular payloads—high-resolution cameras, thermal sensors, loudspeakers, or searchlights. For example, during a night-time evacuation of a flooded hospital, a multi-rotor fire UAV equipped with a spotlight and thermal camera was deployed. It guided amphibious boats by providing real-time reconnaissance of submerged hazards and building entry points. In search operations in suburban areas, the fire UAV’s loudspeaker payload amplified the effectiveness of systematic “grid-by-grid, building-by-building” vocal sweeps. The utility of a fire UAV for such tasks can be analyzed through a probability of detection (\(P_d\)) framework:
$$P_d = 1 – (1 – p_{sensor})^n$$
where \(p_{sensor}\) is the probability that the fire UAV’s sensor (visual, thermal, etc.) detects a target in a single pass, and \(n\) is the number of passes. Using a fire UAV increases \(n\) efficiently over difficult terrain.
Collaboration and interoperability were force multipliers. We operated within a joint emergency response mechanism, coordinating with national disaster reduction centers. Daily flight plans were crafted based on drainage task force deployments. The collaborative output is summarized below:
| Collaborative Entity | Fire UAV Contribution | Joint Output Type | Quantity Produced | Primary Use |
|---|---|---|---|---|
| Fire UAV Unit + National Disaster Center | 2D/3D mapping of core disaster zones | Geospatial Analysis Reports | 15 | Strategic resource allocation |
| Fire UAV Unit + On-site Command | Real-time video and annotated maps | Tactical Situation Overlays | 8 | Immediate rescue coordination |
| Fire UAV Unit + Engineering Teams | Pre- and post-intervention site models | Change Detection Charts | 5 | Monitoring intervention efficacy |
The synergy between different fire UAV assets and external agencies can be modeled as a network efficiency problem. Let the overall system effectiveness \(E\) be a function of the number of connected nodes (teams, \(N_t\)) and the quality of data links (\(Q_d\)) provided primarily by fire UAVs:
$$E = \alpha \log(N_t) + \beta \cdot Q_d$$
where \(\alpha\) and \(\beta\) are scaling coefficients. The fire UAV’s role is embedded in enhancing \(Q_d\).
However, the operations also revealed several shortcomings in our fire UAV deployment. A scarcity of trained pilots, a mismatch between the produced maps/charts and the immediate decision-making needs of field commanders, and an insufficient inventory of long-endurance fixed-wing fire UAV platforms were key limitations. To address these, we are formalizing standard operating procedures (SOPs) for fire UAV reconnaissance, underground structure inspection, and real-time map annotation. The training regimen for fire UAV operators is being intensified, with a focus on simulated high-stress environments.
From a technical perspective, improving the fire UAV service level involves optimizing several performance parameters. We can define a composite “Fire UAV Operational Readiness Score” \(S\):
$$S = w_1 \cdot \frac{T_{endurance}}{T_{req}} + w_2 \cdot \frac{R_{data}}{R_{req}} + w_3 \cdot P_{interop}$$
Here, \(T_{endurance}\) is the actual fire UAV flight endurance, \(T_{req}\) is the mission-required endurance, \(R_{data}\) is the data processing rate, \(R_{req}\) is the required rate, \(P_{interop}\) is the interoperability score with other systems, and \(w_i\) are weighting factors summing to 1. Our goal is to drive \(S\) closer to 1 through technological and procedural advancements.
Future developments for fire UAV technology in fire and rescue services point toward greater autonomy, enhanced sensor fusion, and robust communications in denied environments. The integration of Artificial Intelligence (AI) for real-time anomaly detection in fire UAV footage is a promising avenue. Consider an AI model that processes fire UAV imagery to identify distress signals or structural weaknesses. Its accuracy \(Acc\) could be a function of training data size \(D\) and model complexity \(M\):
$$Acc(D, M) = \gamma \cdot \tanh(\delta \cdot D) + \epsilon \cdot M$$
where \(\gamma, \delta, \epsilon\) are constants. Deploying such AI on the fire UAV edge devices would further accelerate analysis.
In conclusion, the fire UAV has evolved from a niche tool to a cornerstone of modern disaster response. Its ability to provide rapid, comprehensive, and actionable intelligence under extreme conditions is unmatched. The lessons from large-scale flood operations underscore the need for a holistic approach—combining advanced fire UAV hardware, streamlined data workflows, adaptive tactics, and deep inter-agency cooperation. As we refine our strategies and technologies, the fire UAV will undoubtedly play an even more pivotal role in saving lives and mitigating disaster impacts, solidifying its status as an essential asset in the emergency responder’s toolkit. The journey of integrating the fire UAV into every facet of our operational doctrine continues, driven by a commitment to innovation and effectiveness in the face of adversity.
To further illustrate the technical specifications and operational parameters of typical fire UAV systems in use, the following comparative table provides a detailed breakdown:
| Parameter / Fire UAV Model | Fixed-Wing Long-Range Scout | VTOL Tactical Mapper | Multi-Rotor Heavy Lifter | Miniature Reconnaissance |
|---|---|---|---|---|
| Max Endurance (hours) | 6-10 | 3-5 | 0.75-1.5 | 0.5 |
| Operational Range (km) | 50-100 | 20-40 | 5-10 | 2-5 |
| Typical Payload Capacity (kg) | 1.5-3.0 | 2.0-4.0 | 5.0-15.0 | 0.3 |
| Key Sensors | RGB camera, Multispectral | RGB, LiDAR, Thermal | Thermal, Zoom camera, Loudspeaker | Ultra-wide camera |
| Data Link Type | Long-range digital video | Medium-range hybrid | Short-range robust video | Wi-Fi/ Mesh |
| Primary Disaster Role | Large-area damage assessment | Rapid high-detail mapping | Close support, delivery, search | Indoor/ confined space recon |
| Weather Tolerance | Moderate wind, no rain | Light wind, no precipitation | Light wind, light rain | Calm conditions only |
The selection of the appropriate fire UAV for a given task is a critical decision. We can formalize this with a utility function \(U\) for a mission with requirements vector \(\vec{R}\) and a fire UAV with capabilities vector \(\vec{C}\):
$$U(\vec{R}, \vec{C}) = \frac{\vec{R} \cdot \vec{C}}{|\vec{R}| |\vec{C}|}$$
where a value closer to 1 indicates a better match. This conceptual model helps in pre-mission planning for fire UAV deployments.
Another vital aspect is the logistical footprint and support required for a fire UAV unit. The sustainability of operations depends on factors like charging infrastructure, spare parts, and data storage. The mean time between failures (MTBF) for a fire UAV fleet and the mean time to repair (MTTR) are key metrics:
$$Availability = \frac{MTBF}{MTBF + MTTR}$$
Maintaining high availability for our fire UAV assets is a constant logistical endeavor, requiring dedicated support personnel and robust supply chains.
In terms of data products, the fire UAV generates massive datasets. The processing workflow from raw imagery to a 3D model involves photogrammetric principles. The core equation for generating a point cloud from overlapping fire UAV images is based on structure-from-motion (SfM):
$$\min_{P_i, X_j} \sum_{i,j} || p_{ij} – \Pi(P_i, X_j) ||^2$$
Here, \(P_i\) are camera parameters for image \(i\), \(X_j\) are 3D point coordinates, \(p_{ij}\) is the observed 2D image point, and \(\Pi\) is the projection function. Efficiently solving this for large fire UAV datasets is crucial for timely map production.
The evolution of the fire UAV as a platform is also tied to regulatory and airspace integration challenges. Developing safe and standardized protocols for operating multiple fire UAVs in congested emergency airspace is an ongoing effort. This involves concepts like UAS Traffic Management (UTM), where the fire UAV must communicate its intent and position. The safety case often relies on probability models for mid-air collision risk, which must be kept acceptably low for fire UAV operations to be authorized in shared spaces.
Ultimately, the story of the fire UAV in disaster response is one of continuous adaptation and integration. From providing the initial eyes over a devastated landscape to guiding the final stages of recovery, the fire UAV has proven its worth. As technology advances, so too will the capabilities of the fire UAV, promising even greater resilience and effectiveness in the face of future calamities. The commitment to leveraging every technological advantage, with the fire UAV at the forefront, remains a defining principle for progressive emergency services worldwide.