
The pursuit of efficiency, portability, and operational flexibility is a constant driver in the development of modern agricultural UAV technology. A significant challenge faced in the field is the transportation and rapid deployment of these systems, especially in regions characterized by small, fragmented land plots. Bulky, fixed-arm drones necessitate large vehicles for transport and require time-consuming assembly, directly impacting operational throughput. While integrating arm folding mechanisms addresses the portability issue, it inherently adds mass and potentially alters the structural dynamics of the airframe. Therefore, achieving a lightweight design for such mechanisms without compromising structural integrity and dynamic performance is paramount. This article details a systematic engineering approach, combining finite element analysis (FEA) and structural topology optimization, to develop a lightweight arm folding mechanism for a quadrotor agricultural UAV. The primary objectives are to minimize mass while ensuring the mechanism meets all static and dynamic requirements under the most severe operational loads.
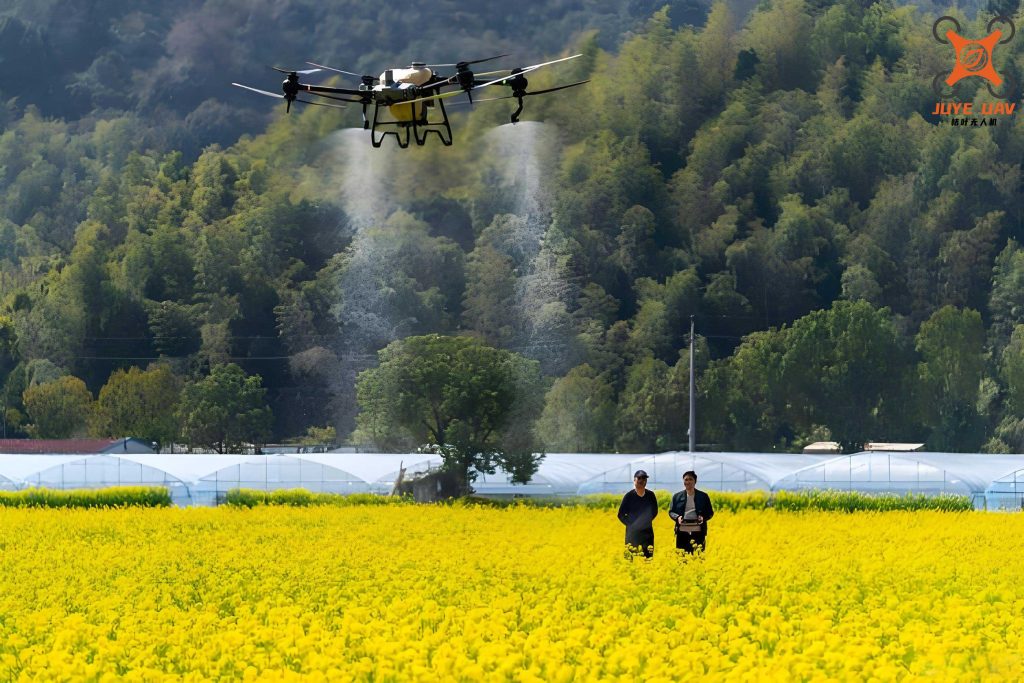
The core of this methodology is topology optimization, a computational design technique that determines the optimal material layout within a given design space, subject to specified constraints and performance objectives. For the arm folding mechanism of an agricultural UAV, the goal is to remove material from non-critical, low-stress areas while maintaining sufficient stiffness and strength. The mathematical foundation often employs the Solid Isotropic Material with Penalization (SIMP) method. In this formulation, the design domain is discretized into finite elements, each assigned a pseudo-density variable, $\rho_i$, which varies between a lower bound $\rho_{min}$ (near zero, representing void) and 1 (representing solid material). The material properties are interpolated as a function of this density. The optimization problem for minimizing compliance (maximizing stiffness) with a mass constraint can be stated as:
$$
\begin{aligned}
& \text{find} \quad && \boldsymbol{\rho} = (\rho_1, \rho_2, …, \rho_n)^T \\[0.5em]
& \text{minimize} \quad && c(\boldsymbol{\rho}) = \mathbf{U}^T \mathbf{K}(\boldsymbol{\rho}) \mathbf{U} = \sum_{i=1}^{n} (\rho_i)^p \mathbf{u}_i^T \mathbf{k}_0 \mathbf{u}_i \\[0.5em]
& \text{subject to} \quad && \frac{V(\boldsymbol{\rho})}{V_0} = \frac{\sum_{i=1}^{n} \rho_i v_i}{V_0} \leq f \\[0.5em]
& && \mathbf{K}(\boldsymbol{\rho}) \mathbf{U} = \mathbf{F} \\[0.5em]
& && 0 < \rho_{min} \leq \rho_i \leq 1, \quad i=1,…,n
\end{aligned}
$$
where $c$ is the structural compliance (inverse of stiffness), $\mathbf{K}$ is the global stiffness matrix, $\mathbf{U}$ and $\mathbf{F}$ are the global displacement and force vectors, $\mathbf{k}_0$ is the element stiffness matrix for solid material, $\mathbf{u}_i$ is the element displacement vector, $p$ is the penalty factor (typically $p=3$) that drives the density towards 0 or 1, $V(\boldsymbol{\rho})$ is the volume of the current design, $V_0$ is the volume of the design domain, $v_i$ is the volume of an element, and $f$ is the prescribed volume fraction constraint. This formulation guides the optimization algorithm to redistribute material from low-stress regions to load-bearing paths, creating an efficient, lightweight topology for the agricultural UAV component.
Methodology: From Conceptual Design to Validated Optimization
The development process follows a structured sequence: three-dimensional modeling, pre-optimization performance evaluation, topology optimization setup and execution, geometry reconstruction, and finally, validation of the optimized design. This ensures the final product is both lightweight and functionally reliable for the demanding environment of agricultural UAV operations.
1. Three-Dimensional Modeling and Pre-Optimization Analysis
The initial design of the arm folding mechanism was based on kinematic requirements for reliable locking and unfolding, as well as spatial constraints for a compact folded configuration. The mechanism primarily consists of two main structural members (Socket A and Socket B), a locking latch, a locking spring, and various fasteners (clamping bolt, pivot bolt, locating screw). The connection between Socket A and B is a sleeve-and-insert type, with Socket B rotating around the pivot bolt. The locking action utilizes an over-center (four-bar linkage dead-center) principle for secure, snap-in locking when the arm is raised, and a simple pull-release for folding. This design allows the quadrotor agricultural UAV to transform from a large operational wingspan to a highly compact form factor, drastically improving logistics.
To establish a performance baseline, a finite element model was created. The materials were defined as follows: the main arm was modeled as Carbon Fiber, while the folding mechanism components were assigned the aluminum alloy 6061-T6, a common choice for lightweight aerospace structures due to its good strength-to-weight ratio. Their properties are summarized in Table 1.
| Material | Density (kg/m³) | Young’s Modulus (GPa) | Poisson’s Ratio | Yield Strength (MPa) |
|---|---|---|---|---|
| 6061-T6 Aluminum | 2700 | 69.0 | 0.33 | 240 |
| Carbon Fiber | 1800 | 290.0 | 0.30 | 4870 |
The critical load case was defined by the maximum thrust scenario. Each motor of the quadrotor agricultural UAV was specified to provide a maximum lift of 243 N. This force was applied as a tensile load at the distal end of the arm (motor mount location). A fixed support boundary condition was applied at the interface where the arm connects to the central flight controller plate. A convergence study was performed to determine an appropriate global mesh size, resulting in a high-quality mesh with an average element quality of 0.817.
Static Analysis Results (Pre-Optimization): The analysis revealed the stress and deformation distribution under full load. The maximum equivalent (von-Mises) stress was found to be 107.28 MPa, located at the connection region between Socket A and Socket B. This value is well below the yield strength of 6061-T6 (240 MPa), indicating a significant safety factor and, crucially, a clear opportunity for mass reduction through topology optimization. The maximum deformation was 0.41129 mm at the motor end, a negligible deflection that would not impact the flight control or spraying accuracy of the agricultural UAV.
Modal Analysis Results (Pre-Optimization): A pre-stressed modal analysis was conducted to determine the natural frequencies and mode shapes of the assembly. Resonance with the motor/propeller excitation frequencies must be avoided to ensure stable flight and prevent fatigue. The selected motor’s maximum operational speed corresponds to a forcing frequency of 32.75 Hz. The first six natural frequencies of the initial design are listed in Table 2. The first natural frequency was 145.52 Hz, which is substantially higher than the maximum excitation frequency, confirming that the initial design was dynamically safe. This established a critical benchmark: the optimized design must maintain natural frequencies sufficiently above the operational excitation range.
| Mode Order | Natural Frequency (Hz) | Mode Order | Natural Frequency (Hz) |
|---|---|---|---|
| 1 | 145.52 | 4 | 569.90 |
| 2 | 148.88 | 5 | 1345.60 |
| 3 | 562.27 | 6 | 1415.90 |
2. Topology Optimization Setup and Execution
Based on the static analysis, the components Socket A, Socket B, and the locking latch were identified as the design space for optimization. Regions required for bolted connections (holes for pivot bolt, clamping bolt, locating screw) and bearing surfaces were designated as non-design regions to preserve functionality and manufacturability. The optimization problem was formally defined within the FEA software’s topology module:
- Objective: Minimize Compliance (Maximize Global Stiffness).
- Constraint: Volume Reduction (Mass Reduction) by 15%.
- Method: SIMP (Density-based approach).
- Algorithm Control: Maximum iteration = 500, convergence tolerance = 0.1%.
The solver iteratively redistributed material within the design space. The final iteration produced a material density contour plot, effectively a three-dimensional “guidance blueprint” showing where material is essential (density ~1) and where it can be removed (density ~0). This optimized topology revealed intricate, organic-looking load paths that efficiently channel stresses from the load application points to the fixed support, eliminating bulky, non-structural material typical of initial prismatic designs.
3. Geometry Reconstruction and Design Interpretation
The raw topology optimization result is not directly manufacturable. It serves as a conceptual guide. The density distribution was interpreted and translated into a new, clean, parametric CAD model. This reconstruction phase involves engineering judgment to balance the optimal topology with practical considerations such as ease of machining (for aluminum), assembly, and aesthetic integration with the rest of the agricultural UAV airframe. Key changes included adding strategic ribs, smoothing complex contours, and ensuring uniform wall thicknesses where possible. The visual comparison between the initial and optimized geometries clearly shows a more skeletal, efficient structure with significant material removed from low-stress zones.
Validation of the Optimized Design
The reconstructed CAD model of the optimized arm folding mechanism was subjected to the same rigorous FEA procedures as the original design to verify its performance. The identical boundary conditions, material properties, and load of 243 N per arm were applied.
Static Analysis Results (Post-Optimization): The results confirmed the success of the optimization. Crucially, the maximum equivalent stress in the new design was found to be 89.91 MPa, which is not only still safely below the material yield strength but also represents a 16.2% reduction from the initial design’s stress. This counterintuitive result—lower stress after removing material—is a hallmark of successful topology optimization: material is placed more efficiently along primary load paths, reducing stress concentrations. The maximum deformation saw a marginal improvement, decreasing to 0.40711 mm. A comprehensive comparison is provided in Table 3.
| Metric | Initial Design | Optimized Design | Change |
|---|---|---|---|
| Mass of Mechanism | 231.54 g | 204.21 g | ‑11.8% |
| Max. Equivalent Stress | 107.28 MPa | 89.91 MPa | ‑16.2% |
| Max. Deformation | 0.41129 mm | 0.40711 mm | ‑1.0% |
The mass reduction of 27.33 grams per mechanism translates to a total saving of 109.32 grams for the entire quadrotor agricultural UAV (four arms). This directly increases potential payload capacity or flight endurance, two critical performance metrics for any agricultural UAV.
Modal Analysis Results (Post-Optimization): The pre-stressed modal analysis was repeated on the optimized assembly. The results, compared in Table 4, show that the dynamic characteristics were not only preserved but, in several modes, enhanced. The first natural frequency increased slightly to 145.81 Hz, maintaining a wide margin above the excitation frequency. Most modes showed a slight increase in frequency, indicating a higher global stiffness-to-mass ratio. While the 5th mode frequency decreased by 3.7%, it remained at a very high absolute value (1295.8 Hz), posing no risk of resonance. This confirms that the lightweighting process improved the fundamental dynamic stiffness of the structure.
| Mode Order | Initial Freq. (Hz) | Optimized Freq. (Hz) | Change |
|---|---|---|---|
| 1 | 145.52 | 145.81 | +0.20% |
| 2 | 148.88 | 149.43 | +0.37% |
| 3 | 562.27 | 566.12 | +0.68% |
| 4 | 569.90 | 572.47 | +0.45% |
| 5 | 1345.60 | 1295.80 | -3.70% |
| 6 | 1415.90 | 1417.30 | +0.10% |
Conclusion and Implications for Agricultural UAV Design
This study successfully demonstrates a complete engineering workflow for the structural optimization of a critical subsystem in a quadrotor agricultural UAV. By applying finite element-based topology optimization to the arm folding mechanism, a mass reduction of 11.8% was achieved per mechanism while simultaneously improving key performance indicators. The optimized design exhibits lower maximum stress, comparable deformation, and maintained or slightly improved natural frequencies compared to the initial, conservatively designed component.
The implications for agricultural UAV development are significant. First, the integration of such an optimized folding mechanism solves the practical logistics problem, enabling a drastic reduction in transport volume (over 75% in this case) without sacrificing the operational wingspan. Second, the achieved weight saving directly contributes to the overarching goal of platform lightweighting, which can be leveraged to carry more agrochemicals, more advanced sensors, or to extend flight time—all factors that enhance operational efficiency and reduce cost per acre. The methodology itself, combining precise load definition, static and dynamic FEA, and systematic topology optimization, provides a robust and repeatable template for lightweighting other components of the agricultural UAV, such as the central frame, landing gear, or sprayer mounting system. This approach ensures that as the industry moves towards more portable and intelligent agricultural UAV platforms, their structural design is not only compact and functional but also fundamentally efficient and reliable.