
The sustainable management and protection of forest resources represent a critical challenge in balancing ecological integrity with socio-economic development. This is particularly evident in regions like Guizhou Province, characterized by rich biodiversity, complex karst topography, and a delicate interplay between conservation needs and livelihood pressures. Traditional forest resource monitoring, reliant on ground-based surveys, is often labor-intensive, time-consuming, and limited in its spatial and temporal scope. In recent years, the integration of Unmanned Aerial Vehicle (UAV) technology with remote sensing (RS) has emerged as a revolutionary tool, offering unprecedented capabilities for efficient, high-resolution, and cost-effective data acquisition. This article explores the application of UAV remote sensing in comprehensive forest resource monitoring, with a particular emphasis on the pivotal role of fire UAV systems in prevention, detection, and post-event analysis.
The fundamental components of a forestry UAV system consist of the aerial platform and the ground control station (GCS). Platforms are primarily categorized into fixed-wing and rotary-wing (multirotor) types. For large-scale forest monitoring, fixed-wing UAVs are often preferred due to their longer endurance and faster cruising speed, enabling coverage of extensive areas in a single flight. Rotary-wing UAVs, especially multirotors, excel in missions requiring vertical take-off and landing (VTOL), precise hovering, and detailed inspection of smaller, targeted plots. The choice significantly impacts mission planning. The GCS is used for flight path pre-planning, real-time telemetry monitoring, and data downlinking.
The sensor payload is the core of the remote sensing capability. While standard high-resolution RGB cameras are commonplace, the integration of multispectral, thermal infrared, and Light Detection and Ranging (LiDAR) sensors is expanding the informational dimension. Data processing workflows involve photogrammetric processing of overlapping imagery to generate high-resolution Digital Surface Models (DSMs), Digital Terrain Models (DTMs), and orthorectified mosaics (Orthomosaics). The Canopy Height Model (CHM), derived by subtracting DTM from DSM, is a fundamental data layer for structural analysis.
The advantages of UAV remote sensing over traditional methods are substantial, as summarized in Table 1.
| Aspect | Traditional Ground Survey | Satellite/Aerial Remote Sensing | UAV Remote Sensing |
|---|---|---|---|
| Spatial Resolution | Point-based, highly accurate but sparse | Low to Moderate (e.g., 10m – 30m) | Very High (<0.1m – 0.5m) |
| Temporal Flexibility | Low, logistically constrained | Fixed by satellite revisit cycle | On-demand, rapid deployment |
| Operational Cost | High (labor, time) | High (imagery purchase) to Very High (commissioned flight) | Relatively Low |
| Data Richness | Detailed but localized parameters | Broad spectral & spatial coverage | High-resolution structural & spectral detail |
| Safety for Personnel | Risky in difficult terrain | N/A | High, operates remotely |
Extracting Forest Structural and Biophysical Parameters
The high spatial resolution of UAV imagery enables detailed extraction of individual tree and stand-level parameters. Key methodologies include:
1. Individual Tree Detection and Crown Delineation: Algorithms, such as local maxima filtering on CHMs or region-growing segmentation on orthomosaics, can automatically identify tree tops and delineate crown boundaries. The crown projection area ($A_c$) is a primary derived metric.
2. Tree Height Estimation: Tree height ($H$) is directly extracted from the CHM as the difference between the DSM value at the tree apex and the corresponding DTM value.
$$ H_i = \text{DSM}(x_i, y_i) – \text{DTM}(x_i, y_i) $$
where $(x_i, y_i)$ are the coordinates of the $i$-th detected tree top.
3. Stem Diameter and Volume/Biomass Estimation: Allometric relationships are established between UAV-derived metrics (like $A_c$) and field-measured parameters like Diameter at Breast Height (DBH). These relationships are often species-specific and region-specific.
$$ \text{DBH} = \alpha \cdot \sqrt{A_c} + \beta $$
Subsequently, above-ground biomass (AGB) can be estimated using standard allometric equations:
$$ \text{AGB} = a \cdot (\text{DBH})^b $$
or via more complex models incorporating height $H$ and wood density $\rho$:
$$ \text{AGB} = a \cdot \rho \cdot (\text{DBH})^b \cdot H^c $$
The parameters $a$, $b$, $c$, $\alpha$, $\beta$ are derived from regression analysis of field calibration data.
4. Canopy Closure and Leaf Area Index (LAI): Canopy closure (or crown cover) is calculated as the ratio of the total crown area to the ground area of a plot. Spectral vegetation indices (VIs) computed from multispectral data (e.g., NDVI, NDRE) are correlated with LAI and chlorophyll content, providing insights into vegetation health and productivity. A simple Visible-band Difference Vegetation Index (VDVI) usable with RGB cameras can be expressed as:
$$ \text{VDVI} = \frac{2 \cdot G – R – B}{2 \cdot G + R + B} $$
where $R$, $G$, $B$ are the digital number values in the red, green, and blue bands, respectively.
| Parameter | Primary Data Source | Key Extraction Method | Typical Accuracy |
|---|---|---|---|
| Tree Height (H) | CHM from RGB/SfM or LiDAR | Local Maxima on CHM | >90% for open canopies |
| Crown Area (A_c) | Orthomosaic / CHM | Watershed, Region-growing segmentation | Dependent on canopy density |
| Stem Density | Orthomosaic / CHM | Individual Tree Detection (ITD) count | High for low/med density |
| Canopy Closure | Binary canopy mask from Orthomosaic/VI | Pixel/object area ratio | >85% |
| Biomass (AGB) | H, A_c + Allometry | Regression modeling | Varies with model & site |
Monitoring Forest Health: Pests, Diseases, and Stress
UAVs are highly effective for early detection and mapping of forest disturbances. Multispectral and thermal sensors are particularly valuable here.
1. Pest and Disease Outbreaks: Pathogens and insects often cause subtle changes in leaf pigment, water content, and structure before becoming visible to the naked eye. Multispectral indices sensitive to chlorophyll (e.g., NDVI) or water content (e.g., NDWI) can identify areas of pre-visual or early-stage stress. Specific disease patterns, like those caused by rusts or bark beetles, create distinct spectral-spatial signatures that machine learning classifiers (e.g., Random Forest, Support Vector Machines) can be trained to detect.
2. Drought and Abiotic Stress: Thermal infrared sensors measure canopy temperature. Stressed vegetation, with stomatal closure reducing evaporative cooling, often exhibits elevated canopy temperatures compared to healthy vegetation. This thermal signature, detectable by a specialized fire UAV equipped with a thermal camera, can map water stress across a landscape.
The Critical Role of Fire UAV Systems in Wildland Fire Management
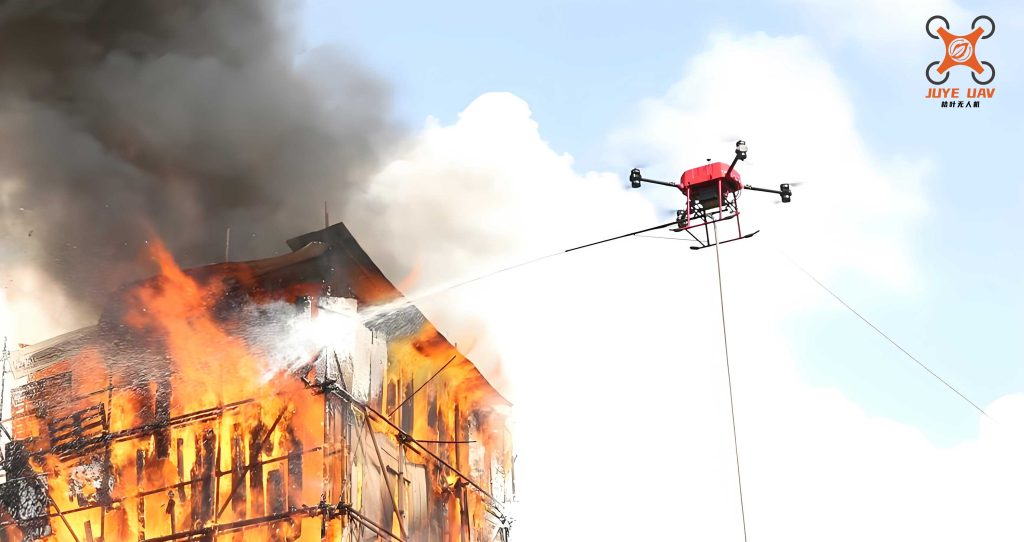
The application of UAVs in wildland fire management is one of the most impactful and rapidly advancing areas. A dedicated fire UAV is typically equipped with a combination of visual (RGB), thermal infrared (TIR), and sometimes multispectral sensors. Their roles span the entire fire management cycle:
1. Pre-Fire: Risk Assessment and Fuel Mapping:
* Fuel Load Estimation: By deriving canopy height, density, and biomass, UAVs help create detailed fuel maps, which are critical inputs for fire behavior models (e.g., FARSITE, FlamMap).
* Fuel Moisture Content: Spectral indices from multispectral data can be correlated with live fuel moisture content, a key variable in fire ignition and spread risk.
2. Active Fire: Detection, Monitoring, and Intelligence:
* Early Detection: Thermal cameras on a fire UAV can detect hotspots through smoke or during nighttime, far earlier than visual observation. Automated detection algorithms analyze thermal video streams in real-time, identifying pixel clusters with temperatures exceeding a critical threshold ($T_{crit}$).
* Fire Perimeter Mapping: UAVs can safely map the active fire front and perimeter with high accuracy, providing real-time situational awareness. The geolocation of the fire line is continuously updated.
* Fire Behavior Analysis: Time-series thermal imagery can be used to estimate rate of spread (ROS) and fire intensity.
$$ \text{ROS} = \frac{\Delta d}{\Delta t} $$
where $\Delta d$ is the distance the fire front moved over time interval $\Delta t$, derived from sequential georeferenced thermal images.
3. Post-Fire: Severity Assessment and Rehabilitation Planning:
* Burn Severity Mapping: Differences in pre-fire and post-fire spectral indices (like dNBR – differenced Normalized Burn Ratio) computed from multispectral UAV data provide high-resolution maps of burn severity.
$$ \text{NBR} = \frac{\text{NIR} – \text{SWIR}}{\text{NIR} + \text{SWIR}} $$
$$ \text{dNBR} = \text{NBR}_{\text{pre-fire}} – \text{NBR}_{\text{post-fire}} $$
* Erosion Risk Assessment: High-resolution post-fire DTMs reveal changes in topography and soil exposure, aiding in planning erosion control measures.
| Mission Phase | Primary Objective | Recommended Sensor Suite | Key Data Product |
|---|---|---|---|
| Pre-Fire / Risk | Fuel mapping, moisture assessment | Multispectral, RGB (for structure) | Fuel type/layer maps, Moisture index maps |
| Active Fire – Detection | Hotspot identification, initial perimeter | Long-wave Infrared (LWIR) Thermal Camera | Georeferenced hotspot coordinates/KML |
| Active Fire – Intelligence | Perimeter mapping, spread monitoring | Thermal + RGB (for context) | Real-time fire perimeter GIS layer |
| Post-Fire | Severity assessment, damage estimation | Multispectral, RGB | Burn severity index map (e.g., dNBR), Change detection maps |
The operational superiority of a fire UAV in active fire scenarios is clear. Unlike manned aircraft, they can operate in heavy smoke, at night, and in otherwise dangerous conditions without risking pilot lives. Their ability to provide persistent, localized surveillance is a game-changer for incident commanders. The integration of data from a fire UAV directly into Geographic Information System (GIS) platforms enables dynamic, data-driven decision support.
Challenges, Future Directions, and Synergistic Integration
Despite the transformative potential, challenges remain in UAV-based forest monitoring. These include:
* Limited Payload and Endurance: This constrains the weight and power of sensors, especially for advanced systems like LiDAR or hyperspectral cameras.
* Data Processing Volume: Large areas flown at ultra-high resolution generate massive datasets, requiring robust computational resources and efficient processing pipelines.
* Regulatory and Airspace Restrictions: Flight permissions, especially beyond visual line of sight (BVLOS), are a significant hurdle for large-scale operations.
* Under Canopy and High-Density Forest Limitations: Optical and SfM techniques struggle in closed canopies. Penetrative sensors like LiDAR are better but more costly.
The future lies in synergistic technology integration and advancement:
1. Multi-Platform and Multi-Sensor Data Fusion: The true power is unlocked by fusing data from satellites, manned aircraft, UAVs, and ground sensors. Satellites provide frequent, wide-area context. UAVs offer targeted, high-resolution detail. For example, a regional biomass model from satellite data can be locally calibrated and validated using precise measurements from a UAV.
2. Advanced Sensor Development: Miniaturization of LiDAR and hyperspectral sensors will become more accessible. Synthetic Aperture Radar (SAR) payloads for small UAVs could enable all-weather, day-and-night monitoring, a significant advantage for a fire UAV in any condition.
3. Artificial Intelligence and Automated Analytics: Deep learning algorithms (Convolutional Neural Networks – CNNs) will move beyond simple tree detection to automated species identification, precise health diagnosis, and predictive analytics for fire risk and pest outbreaks.
4. Swarm Technology: Coordinated fleets of UAVs, or swarms, could dramatically increase area coverage for tasks like post-fire assessment or rapid detection patrols, with different UAVs in the swarm carrying complementary sensors.
The integration of UAV remote sensing, particularly specialized fire UAV systems, into operational forestry and fire management represents a paradigm shift. It enables a move from reactive, coarse-scale monitoring to proactive, precise, and intelligent resource management. By providing a safe, efficient, and rich source of geospatial data, UAV technology is an indispensable tool for conserving forest ecosystems, mitigating wildfire risks, and supporting the sustainable stewardship of our planet’s vital forest resources. Continued investment in platform durability, sensor miniaturization, automated data processing, and regulatory frameworks will ensure this technology reaches its full potential in safeguarding forests for future generations.