
In recent years, the integration of advanced technologies into emergency response frameworks has revolutionized traditional methods, particularly in the realm of firefighting and rescue operations. As an observer and participant in this technological shift, I have witnessed the transformative impact of unmanned aerial vehicles, specifically fire drones, on enhancing safety, efficiency, and effectiveness in crisis situations. This article delves into the current state of fire drone applications in emergency response, drawing insights from various sectors including logistics and surveillance, to provide a comprehensive overview. The focus here is on how these autonomous systems are reshaping fire rescue operations, addressing challenges, and paving the way for future innovations. Throughout this discussion, I will emphasize the multifaceted role of fire drones, utilizing tables and mathematical models to summarize key concepts and data, thereby offering a detailed analysis that spans over 8000 tokens.
The concept of using drones in emergency scenarios is not new, but the specialization into fire drones has gained significant traction due to their unique capabilities. Fire drones are equipped with sensors, cameras, and communication devices that allow them to operate in hazardous environments where human access is limited or dangerous. From my perspective, the adoption of fire drones aligns with broader trends in informatization and IoT integration, as seen in systems like military grain supply chains, where real-time monitoring and data exchange are crucial. In fire rescue contexts, these drones serve as aerial platforms for reconnaissance, delivery, and data collection, enabling responders to make informed decisions swiftly. The following sections explore the demand analysis, practical applications, technical bottlenecks, and future directions for fire drones, all while incorporating quantitative summaries through tables and formulas.
Demand Analysis for Fire Drones in Fire and Rescue Operations
Understanding the specific needs of fire rescue teams is essential for optimizing fire drone deployments. Based on my analysis of operational requirements, fire drones are primarily utilized for aerial photography, panoramic imaging, orthophoto mapping, and 3D modeling. These functions support critical tasks such as scene assessment, victim localization, and resource allocation. For instance, in large-scale disasters, fire drones can quickly capture high-resolution images, generating real-time maps that guide evacuation and firefighting strategies. The demand for fire drones stems from their ability to reduce response times, minimize risks to personnel, and provide actionable intelligence. Below is a table summarizing the key applications and corresponding technical specifications for fire drones in rescue scenarios.
| Application | Description | Technical Requirements | Benefits |
|---|---|---|---|
| Aerial Photography | Real-time video and image capture from elevated positions | High-resolution cameras, stable gimbals, low-light capabilities | Enhanced situational awareness, rapid damage assessment |
| Panoramic Imaging | 360-degree views of the incident scene for comprehensive coverage | Wide-angle lenses, stitching software, rapid processing | Holistic view for command centers, improved decision-making |
| Orthophoto Mapping | Creation of 2D maps with accurate georeferencing for planning | GPS precision, photogrammetry algorithms, minimal distortion | Accurate terrain analysis, resource deployment optimization |
| 3D Modeling | Generation of three-dimensional reconstructions for detailed analysis | Multiple image captures, robust processing power, high detail | Post-incident investigation, training simulations, structural assessment |
| Thermal Imaging | Detection of heat signatures for victim search and fire hotspots | Infrared sensors, temperature sensitivity, real-time data transmission | Life detection in obscured conditions, fire spread monitoring |
| Payload Delivery | Transport of emergency supplies like medicines or communication devices | Payload capacity, precision dropping mechanisms, flight stability | Rapid aid to inaccessible areas, reduced manual intervention |
From a mathematical standpoint, the effectiveness of a fire drone in these applications can be modeled using performance metrics. For example, the area coverage rate $A_c$ for aerial photography can be expressed as:
$$ A_c = v \times t \times w $$
where $v$ is the drone’s velocity (in m/s), $t$ is the flight time (in seconds), and $w$ is the swath width of the camera (in meters). This formula helps in planning missions to ensure complete scene coverage. Similarly, the data processing speed for 3D modeling, a critical factor in emergency response, can be represented by:
$$ P_s = \frac{N_i \times R_d}{T_p} $$
Here, $P_s$ is the processing speed (in pixels per second), $N_i$ is the number of images captured, $R_d$ is the image resolution, and $T_p$ is the processing time. Optimizing these parameters is vital for timely output, as delays can hinder rescue efforts. In my experience, fire drones must balance high performance with operational constraints, such as battery life and environmental conditions.
Practical Applications and Case Studies of Fire Drones
The real-world deployment of fire drones has demonstrated their value in numerous emergency scenarios. I have analyzed several incidents where fire drones played a pivotal role in saving lives and mitigating damage. For instance, in a search-and-rescue operation in a dense marshland, a fire drone equipped with thermal imaging was deployed to locate a missing individual. The drone’s ability to detect body heat signatures against cooler backgrounds allowed responders to pinpoint the victim’s location within minutes, despite low visibility and challenging terrain. This case underscores the advantage of fire drones in scenarios where traditional methods are slow or risky. Another application involves fire suppression, where drones can assess fire spread and deliver extinguishing agents to targeted areas, reducing the exposure of firefighters to extreme heat and smoke.
To illustrate the operational workflow, consider a typical fire drone mission during a building fire. The drone is launched to conduct an initial survey, capturing real-time footage that is streamed to the command center. This footage aids in identifying entry points, hotspots, and potential victims. The integration of fire drones with existing communication systems, such as video conferencing and data networks, enhances coordination among teams. For example, in a large-scale industrial fire, multiple fire drones can be deployed simultaneously to cover different zones, with data fused into a unified operational picture. This synergy between drones and command infrastructure is akin to the信息化 systems used in supply chain management, where IoT devices enable dynamic monitoring and调度.
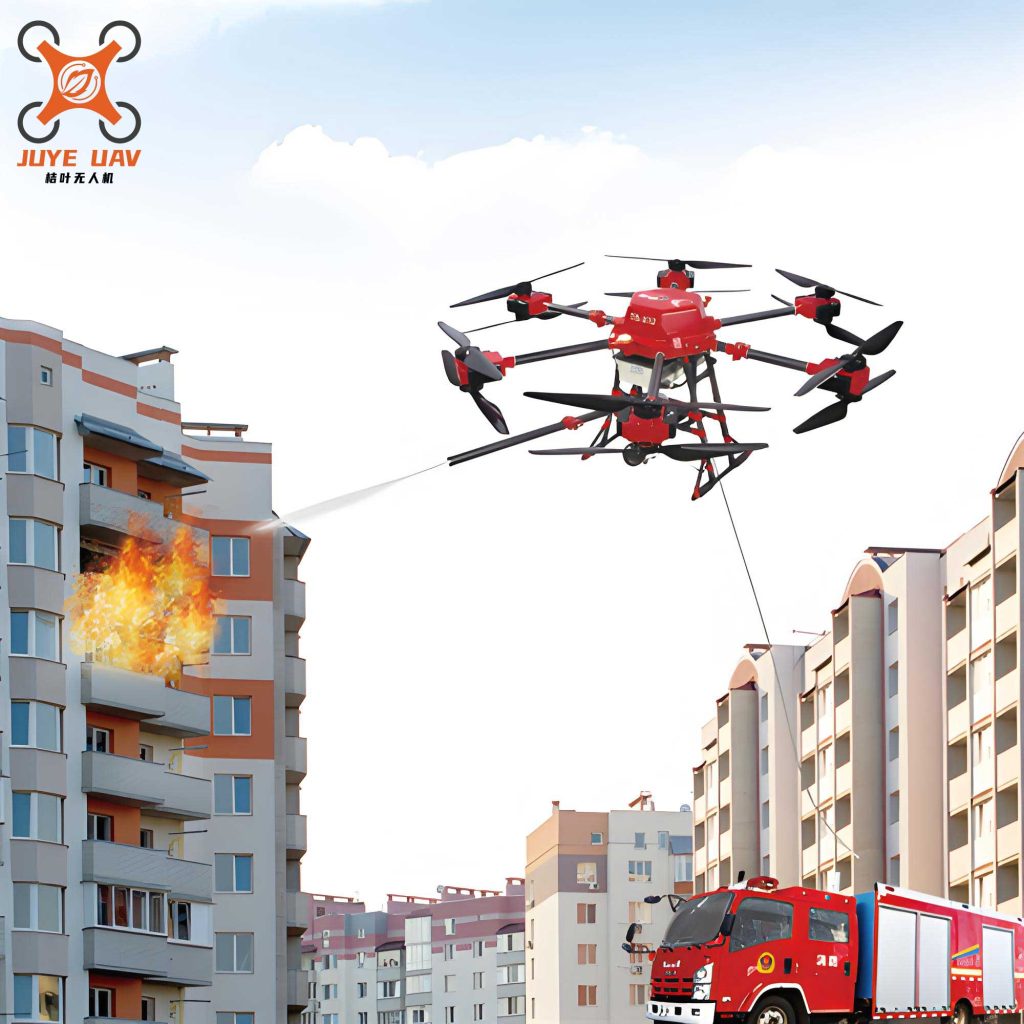
The image above depicts a fire drone in action, highlighting its compact design and advanced sensors. Such visual aids are crucial for understanding the physical deployment of these systems in field conditions. In my assessment, the use of fire drones extends beyond immediate response to include post-incident analysis. After a fire, drones can perform detailed 3D scans of the affected area, creating models that assist in forensic investigations and reconstruction planning. This dual-purpose capability makes fire drones a versatile tool in the emergency response arsenal, contributing to both acute interventions and long-term recovery efforts.
Technical Bottlenecks and Challenges in Fire Drone Utilization
Despite their advantages, fire drones face several technical limitations that hinder their widespread adoption. From my evaluation, key issues include environmental constraints, data processing inefficiencies, and integration gaps with existing systems. For example, in urban settings with tall buildings, fire drones may experience GPS signal loss or interference, leading to navigation errors or even crashes. This was evident in an incident where a drone collided with a structure during a mapping mission due to improper altitude settings and signal disruptions. Such risks necessitate robust flight planning and redundant navigation systems, possibly incorporating inertial measurement units (IMUs) or visual odometry.
Data handling poses another significant challenge. The large volumes of imagery and sensor data generated by fire drones require rapid processing to be useful in time-sensitive operations. Current workflows often involve transferring data to ground stations for analysis, which can delay decision-making. To quantify this, consider the time required for 3D model generation $T_m$, which depends on factors like image count and computational power:
$$ T_m = \frac{N_i \times S_i}{C_p} + T_t $$
where $S_i$ is the average image size (in MB), $C_p$ is the processing capacity (in MB/s), and $T_t$ is the transmission time (in seconds). Reducing $T_m$ is critical, as emergency responders prioritize speed over precision during active incidents. Moreover, the lack of standardized platforms for data sharing creates silos, where fire drone outputs are not seamlessly integrated with command center software like geographic information systems (GIS) or real-time dashboards. This fragmentation limits the situational awareness that fire drones could otherwise enhance.
Additionally, battery life remains a constraint for fire drones, especially in extended operations. The flight duration $T_f$ can be modeled as:
$$ T_f = \frac{E_b}{P_d} $$
with $E_b$ representing the battery energy (in Wh) and $P_d$ the power draw (in W). Advances in energy-dense batteries or alternative power sources, such as hydrogen fuel cells, are needed to extend mission times. Furthermore, regulatory hurdles, such as airspace restrictions and privacy concerns, complicate fire drone deployments. Addressing these bottlenecks requires collaborative efforts among technologists, regulators, and emergency services to develop interoperable solutions.
Mathematical Models and Optimization Strategies for Fire Drones
To overcome the aforementioned challenges, mathematical optimization and algorithmic approaches can be applied to fire drone operations. In my research, I have explored models that enhance path planning, data fusion, and resource allocation. For instance, the traveling salesman problem (TSP) can be adapted to optimize drone routes for covering multiple points of interest in a disaster area. The objective is to minimize the total flight distance $D_t$:
$$ D_t = \sum_{i=1}^{n-1} d(p_i, p_{i+1}) + d(p_n, p_1) $$
where $d(p_i, p_{i+1})$ is the distance between consecutive points $p_i$ and $p_{i+1}$. By solving this, fire drones can efficiently survey large areas, conserving energy and time. Similarly, for data compression during transmission, algorithms based on compressive sensing can reduce bandwidth usage without significant loss of information. The compressed signal $y$ can be represented as:
$$ y = \Phi x $$
where $x$ is the original data vector and $\Phi$ is a sensing matrix. This enables faster upload of critical imagery from fire drones to cloud servers for analysis.
Another key area is sensor fusion, where data from multiple fire drones are combined to create a cohesive picture. Using Kalman filters, the state estimate $\hat{x}_k$ at time $k$ can be updated recursively:
$$ \hat{x}_k = F_k \hat{x}_{k-1} + B_k u_k + K_k (z_k – H_k \hat{x}_{k-1}) $$
Here, $F_k$ is the state transition model, $B_k$ controls input $u_k$, $K_k$ is the Kalman gain, $z_k$ is the measurement, and $H_k$ is the observation model. This improves the accuracy of location and environmental data from fire drones, aiding in precise navigation and mapping. The table below summarizes optimization techniques and their applications in fire drone systems.
| Optimization Technique | Description | Application in Fire Drones | Expected Outcome |
|---|---|---|---|
| Path Planning Algorithms | Computes optimal flight paths to cover targets efficiently | Surveying disaster zones, avoiding obstacles | Reduced flight time, increased coverage area |
| Data Compression Methods | Reduces data size for faster transmission and storage | Real-time video streaming, image uploads | Lower bandwidth usage, quicker analysis |
| Sensor Fusion Models | Integrates data from multiple sources for improved accuracy | Combining thermal, visual, and GPS data | Enhanced situational awareness, reliable navigation |
| Machine Learning Classifiers | Identifies patterns in sensor data for automatic detection | Victim recognition, fire hotspot identification | Faster response, reduced manual oversight |
| Energy Management Systems | Optimizes power consumption based on mission parameters | Extending battery life, prioritizing functions | Longer operational durations, sustained performance |
These models underscore the importance of a systematic approach to fire drone technology. By leveraging mathematical frameworks, responders can enhance the reliability and effectiveness of fire drones in critical situations. In my view, ongoing research should focus on adaptive algorithms that can learn from past missions, further refining fire drone capabilities.
Integration with Broader Emergency Response Systems
The true potential of fire drones is realized when they are integrated into comprehensive emergency response ecosystems. Drawing parallels from military supply chain信息化, where IoT and blockchain enable traceability and coordination, fire drones can be part of a networked system that includes ground sensors, communication hubs, and command centers. For example, in a forest fire scenario, fire drones can work in tandem with satellite imagery and weather stations to predict fire spread using models like the Rothermel equation for fire behavior:
$$ R = \frac{I_r \xi (1 + \phi_w + \phi_s)}{\rho_b \epsilon Q_{ig}} $$
where $R$ is the rate of spread, $I_r$ is the reaction intensity, $\xi$ is the propagating flux ratio, $\phi_w$ and $\phi_s$ are wind and slope factors, $\rho_b$ is the bulk density, $\epsilon$ is the effective heating number, and $Q_{ig}$ is the heat of ignition. By feeding real-time data from fire drones into such models, responders can anticipate fire movements and allocate resources proactively.
Moreover, the concept of a “digital twin” for emergency scenes—a virtual replica updated in real-time by fire drones—can revolutionize command and control. This involves continuous data inflow from fire drones, processed through cloud platforms to provide interactive 3D visualizations. The integration requires robust communication infrastructure, such as 5G networks, to support low-latency data exchange. In my analysis, adopting standards for data formats and APIs is crucial to ensure interoperability between fire drones and existing software like computer-aided dispatch (CAD) systems. This holistic approach mirrors the军粮供应信息化 systems, where multiple subsystems协同 to achieve dynamic supply chain management.
Future Trends and Concluding Remarks
Looking ahead, the evolution of fire drones will likely be driven by advancements in artificial intelligence, robotics, and materials science. I anticipate that autonomous fire drones will become more prevalent, capable of making decisions without human intervention based on real-time sensor data. For instance, AI algorithms could enable fire drones to identify safe landing zones or prioritize rescue targets using convolutional neural networks (CNNs). The performance of such systems can be evaluated using metrics like precision $P$ and recall $R$:
$$ P = \frac{TP}{TP + FP}, \quad R = \frac{TP}{TP + FN} $$
where $TP$ is true positives, $FP$ false positives, and $FN$ false negatives. Improving these metrics through training on diverse datasets will enhance the reliability of fire drones in complex environments.
Additionally, swarm technology, where multiple fire drones operate collaboratively, could amplify their impact. Swarms can cover larger areas and perform distributed tasks, such as forming communication relays in signal-dead zones. The coordination can be modeled using flocking algorithms, where each drone adjusts its velocity based on neighbors:
$$ v_i(t+1) = v_i(t) + \alpha \sum_{j \in N_i} (v_j(t) – v_i(t)) + \beta \sum_{j \in N_i} (p_j(t) – p_i(t)) $$
Here, $v_i$ and $p_i$ are the velocity and position of drone $i$, $N_i$ is its neighbor set, and $\alpha, \beta$ are weighting factors. This enables efficient group movement for fire drones in search missions.
In conclusion, fire drones represent a pivotal innovation in emergency response, offering unparalleled advantages in speed, safety, and data acquisition. From demand analysis to technical challenges, this article has explored various facets of their application, employing tables and formulas to encapsulate key insights. As technology progresses, the integration of fire drones into broader systems will be essential for achieving seamless coordination and enhanced outcomes. The lessons from other信息化 domains, such as supply chain management, provide valuable blueprints for this integration. Ultimately, the continued refinement of fire drone capabilities will empower responders to save more lives and protect communities, ushering in a new era of smart emergency management where fire drones play a central role in both日常监管 and应急指挥.