
Sensitive clay riverbank slopes are highly susceptible to deep-seated, retrogressive landslides. In these failures, localized collapse at the toe initiates a progressive failure plane that extends upwards. The strong brittle behavior of sensitive clays complicates the identification of hazardous slopes, while their low remolded strength exacerbates the areal extent of retrogressive influence and potential disaster zones. The advancement of digital photogrammetry and low-altitude remote sensing platforms, particularly using UAV drones, has propelled the widespread application of multi-scale surface process monitoring, including for landslides. It is now feasible to acquire centimeter-level accuracy, high-resolution surface imagery and distributed point cloud data over large areas, providing the technical means to measure pre-failure deformations in sensitive clay landslides. Therefore, this study employs UAV drones for photogrammetric surveys coupled with a total station ground control point network monitoring technique for a detailed case analysis.
1. Project Overview
An observed riverbank slope was prone to intermittent retrogressive landslides. While this behavior has regional specificity and does not represent all sensitive clay landslides, from a monitoring perspective, this uniqueness offers an advantage. The relatively long intervals between successive failure stages increase the likelihood that a field monitoring campaign can capture imagery of slope morphology changes between different phases. Based on existing surface displacement time-series data, observed deformation signs, and adverse stability conditions, a core study slope was identified. At this location, the stream bank is 11m high with an average inclination of approximately 18.4°, featuring a distinct scarp up to 1.2m high at the crest. Fluvial erosion at the toe has reached the top of the underlying clay layer, promoting active slope instability processes along this near-horizontal, low-strength stratum.
In September 2019, a monitoring network consisting of 108 Ground Control Points (GCPs) was established. The network was arranged along five parallel transects spaced about 5m apart, primarily concentrated on the landslide bench and the slope area. Each GCP comprised a 1m long, 10M threaded steel rod driven approximately 0.9m into the ground to ensure visibility in low grassy vegetation, topped with a reinforcing bar cap. This design aimed to position the rod within the frost depth, subjecting it to similar magnitude freeze-thaw cycles as the surrounding soil. The bar cap served a dual purpose: enhancing safety and improving visual identification in imagery due to its 60mm diameter.
2. UAV Data Acquisition and Processing
2.1 Image Acquisition
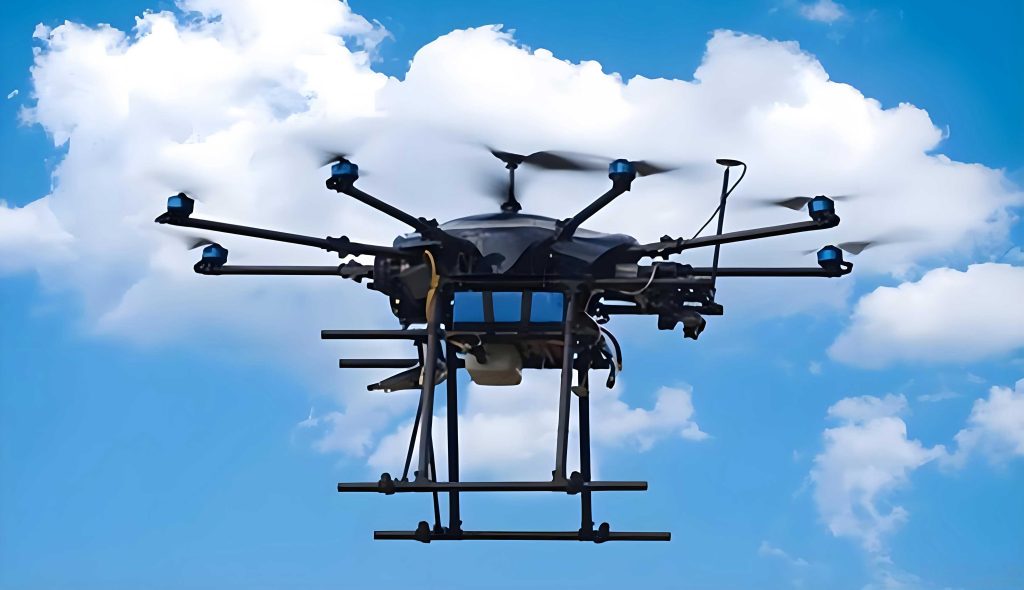
Image collection during the study utilized an octocopter UAV drone with a 1m diameter, equipped with a GPS navigation system for autonomous flight along pre-programmed waypoints. A two-person operation mode was employed. The UAV drone featured an electric gimbal integrated into the central chassis for precise camera azimuth control during flight and effective compensation for aerial platform motion. High-density point cloud data of the landslide surface was generated using specialized photogrammetric software. This method utilized a calibrated camera to acquire image sequences along planned flight strips, requiring specific forward overlap within strips and side overlap between adjacent parallel strips to ensure complete coverage of the study area.
2.2 Data Processing Workflow
Processing UAV drones photogrammetric data is a systematic algorithmic procedure to transform 2D image sequences into high-precision 3D geographic information, adhering to rigorous mathematical modeling and engineering standards. The workflow can be divided into four distinct stages.
Stage 1: Image Preprocessing and Feature Enhancement. Data processing begins with image quality optimization. To address issues common in UAV drones imagery, such as lighting fluctuations and lens distortion, radiometric correction is applied using adaptive histogram equalization algorithms for local contrast adjustment in over- or under-exposed regions. The core formula is expressed as:
$$I_{out}(x,y) = \frac{T(I_{in}(x,y))}{N_{max}} \cdot 255$$
where $T()$ is the grayscale mapping function based on sub-region histograms, and $N_{max}$ is the maximum allowed gray level.
Simultaneously, geometric correction based on the Brown-Conrady model is performed, iteratively solving for radial distortion coefficients $k_1$, $k_2$ and tangential distortion coefficients $p_1$, $p_2$ to calibrate pixel coordinates accurately, with typical residuals controlled within 0.3px. The Signal-to-Noise Ratio (SNR) of preprocessed images can be improved by up to 12dB, laying a solid foundation for subsequent feature matching.
Stage 2: Dense Matching and Point Cloud Generation. Building upon sparse point clouds, an improved Semi-Global Matching (SGM) algorithm is employed for sub-pixel disparity calculation. The Census transform is introduced to refine the matching cost function:
$$C(p,d) = \sum_{q \in W_p} XOR(\text{Census}(q), \text{Census}(q_d))$$
where $W_p$ is a $(9 \times 9)$ pixel window, and $q_d$ is the corresponding point in the right image offset by disparity $d$. To enhance reconstruction in vegetated areas, a multi-baseline matching strategy is used jointly. With baseline length gradients set to $[0.2B, 0.5B, B]$ (where $B$ is the original baseline), the final generated point cloud density reaches 300–500 points/m², with a planimetric accuracy better than 3cm (at 1:500 scale).
Stage 3: Refined Digital Surface Model (DSM) Construction. Point cloud post-processing employs a multi-level filtering strategy. First, Statistical Outlier Removal (SOR with standard deviation multiplier $k=2.0$) eliminates noise points. Second, an improved Cloth Simulation Filter (CSF) with a rigidity parameter of 0.65 is applied to separate ground from non-ground points, adapting to complex terrain. The surface modeling stage utilizes Moving Least Squares (MLS) for surface fitting:
$$\min \sum_{i=1}^{n} \theta(\|x – x_i\|) \cdot (f(x) – z_i)^2$$
where $\theta(\|x – x_i\|)$ is a Gaussian weight function, $\theta(\|x – x_i\|) = e^{-\|x – x_i\|^2 / h^2}$; $h=0.3$m controls the bandwidth of weight decay; $f(x)$ is the surface function to be fitted; and $z_i$ is the actual elevation of point $x_i$.
The generated DSM has a grid resolution of 5cm, with a vertical root mean square error (RMSE) ≤ 8cm relative to GCPs.
Stage 4: 3D Modeling and Multi-Resolution Texture Mapping. A watertight mesh is generated based on Poisson surface reconstruction algorithm, effectively preserving terrain features at a 0.1m scale with a depth parameter $d=10$. Texture mapping employs a view-dependent weighted blending technique, calculating the visibility weight of each triangular face in each image:
$$w_i = \frac{\cos \theta_i}{\|X – C_i\|^2}$$
where $\theta_i$ is the angle between the camera line-of-sight and the face normal, and $C_i$ is the camera center coordinate. The final textured model possesses Level of Detail (LOD) capability, automatically switching to 2K texture maps at a 50m viewing distance, improving storage efficiency by 40%.
2.3 Integrated Measurement Analysis and Accuracy Assessment
The extensive network of GCPs served a dual function: continuously assessing model accuracy and providing redundancy against the anticipated high loss rate of GCPs during landslide progression. Seven GCPs were designated as control points, with the remainder serving as check points. Residuals were calculated by comparing total station-measured coordinates with photogrammetrically derived coordinates. The typical residuals for the initial model are presented in two forms: image point residuals and real-space residuals. Results showed a root mean square error (RMSE) in image space of 0.23px, leading to RMSE errors of 8mm, 9mm, and 14mm in the x, y, and z (vertical) directions, respectively. Complete information on model parameters and residuals is summarized in the tables below.
| Epoch | Control Points | Check Points | Estimated Accuracy (mm) | Valid Images | RMSE X (px) | RMSE Y (px) |
|---|---|---|---|---|---|---|
| 2019/11 | 7 | 73 | 5 | 18 | 0.2285 | 0.2203 |
| 2020/11 | 7 | 77 | 5 | 22 | 0.2228 | 0.2420 |
| 2021/04 | 7 | 55 | 5 | 22 | 0.2272 | 0.2116 |
| 2021/11 | 7 | 61 | 4 | 46 | 0.2312 | 0.2634 |
| 2022/04 | 7 | 33 | 4 | 33 | 0.1886 | 0.2237 |
| Epoch | RMSE X (mm) | RMSE Y (mm) | RMSE Z (mm) | Total RMSE (mm) |
|---|---|---|---|---|
| 2019/11 | 8 | 9 | 14 | 18 |
| 2020/11 | 13 | 12 | 24 | 30 |
| 2021/04 | 7 | 12 | 23 | 27 |
| 2021/11 | 13 | 22 | 13 | 29 |
| 2022/04 | 7 | 8 | 19 | 22 |
The data indicates that the total RMSE for the five photogrammetric models of the study area ranged from 18mm to 30mm. Residuals were higher than theoretically expected primarily due to the use of reinforcing bar caps as GCP targets. Three damage mechanisms were observed: pedestrian impact driving the threaded rod through the cap; animal gnawing deforming the cap; and partial failure of internal定位筋 within the cap, introducing systematic positioning bias difficult to detect visually.
3. Results Analysis and Discussion
3.1 Difference Digital Elevation Models (DoD)
The Difference of Digital Elevation Models (DoDs) provides a visual representation of topographic change. Mid-gray tones indicate no elevation change, dark gray to black tones represent elevation loss (subsidence), and light gray to white tones indicate elevation gain. The 3D expression of the slope geometry reveals the presence of an existing scarp which forms the downslope boundary of the flat bench area. The displacement magnitude of this scarp diminishes with increasing coordinate values, indicating that the left portion of the study area experienced larger downslope displacements.
Notably, field observations indicated no significant changes in slope geometry between 2019 and 2020. Consequently, elevation differences in the initial monitoring period were concentrated in the no-significant-change zone (mid-gray), demonstrating that vegetation clearance prior to image acquisition effectively controlled interference errors from vegetation cover on surface elevation measurements. The elevation changes caused by the 2022 landslide event are distinctly visible. Landslide debris accumulation at the toe caused surface uplift of up to 2m (white tones), while the landslide scar area showed maximum subsidence of approximately -4m (dark tones). The grayscale changes on the slope body above the scar indicate deformation had already occurred in this zone. While DoDs effectively identify and delineate areas of slope deformation, the 3D surface displacement vector field provides a more precise quantitative description of the deformation process leading up to retrogression.
3.2 Surface Displacement Vector Analysis
Analysis of surface displacement profiles along slope cross-sections further reveals the kinematics of the failure. A target cross-section, traversing the approximate center of the two retrogressive flow events, can serve as an indicator for the propagation of the failure plane beyond the initial scarp at the crest. Incremental surface displacement profiles characterizing three main stages of slope behavior are analyzed.
- Stage of Insignificant Deformation: Over a two-year monitoring period with no visual signs of qualitative change, displacement magnitudes were minimal. Near-horizontal displacement at the toe indicated wedge sliding along the underlying clay layer.
- Post-2022 Failure Stage: GCPs located downslope of the crest scarp showed continued displacement along the inferred failure direction.
- Post-2023 Flow Failure Stage: Exposure of the scarp rear and displacement in the bench area behind the crest indicated the failure plane had extended deeper into the slope mass.
The monitoring data revealed that surface displacement monitoring points on the bench behind the crest exhibited progressive cumulative displacement directed towards the stream, initially showing an approximately linear growth trend. This linear increase in horizontal displacement characterizes the tensile strain generated as the slope slides along the near-horizontal failure plane within the underlying clay layer.
4. Conclusion
This study implemented a monitoring approach based on UAV drones photogrammetry integrated with a total station ground control point network to assess pre-failure displacement in a sensitive clay landslide. Five years of periodic GCP measurements revealed an accumulation of slow deformation directed towards the crest scarp prior to the flow failures in 2022 and 2023. The data demonstrated that monitoring points on the rear bench exhibited progressive, stream-directed cumulative displacement with an initial near-linear trend, characterizing tensile strain from sliding along the basal clay layer. Integrating surface displacement distribution characteristics indicates that, by the end of the monitoring period, the progressive failure plane had extended beyond the original scarp, leaving the slope at risk of further retrogressive instability. The application of UAV drones proved instrumental in capturing high-resolution, multi-temporal data essential for understanding the kinematics of this complex landslide process.