
In modern battlefield environments, small fixed-wing unmanned aerial vehicles (UAVs) are increasingly susceptible to external electromagnetic interference (EMI) that can induce flight control instability. Understanding the underlying coupling mechanisms is essential for both electromagnetic hardening and countermeasure development. In this work, we systematically investigate the continuous-wave (CW) electromagnetic radiation effects on a small fixed-wing UAV, combining full-wave electromagnetic simulation with controlled irradiation experiments. Our study identifies the servo signal cables running along the narrow fuselage as the dominant back-door coupling path, and reveals that cable resonance at specific frequencies converts external field energy into common-mode currents, which then transform into differential-mode voltages due to impedance imbalance, ultimately disturbing the pulse-width modulation (PWM) signals and causing non‑command tail-fin oscillations.
Introduction
The proliferation of small fixed-wing UAVs in both civilian and military applications has brought increased attention to their vulnerability in complex electromagnetic environments. High-power microwave weapons, communication jammers, and navigation disruptors all pose serious threats. Unlike rotary-wing UAVs, fixed-wing platforms have distinct aerodynamic layouts, flight control systems, and internal cabling arrangements, leading to unique electromagnetic coupling pathways. Previous research largely focused on front-door coupling through antennas or on rotary‑wing UAVs, leaving a gap in the understanding of back‑door coupling for fixed‑wing UAVs. In this paper, we aim to fill that gap by studying the field-to-cable coupling mechanism in a typical small fixed-wing UAV. We first analyze the possible back‑door coupling paths using an electromagnetic topology model, then build a detailed simulation model in CST Microwave Studio and Cable Studio to evaluate the induced voltages on various internal cables under different polarization and incidence angles. Finally, we validate the simulation results through whole‑vehicle CW irradiation tests and propose a physically consistent mechanism for the observed tail‑fin jitter.
Back‑Door Coupling Path Analysis
The internal structure of a small fixed‑wing UAV typically comprises wings, tail (horizontal and vertical stabilizers), fuselage, power system (motor and servos), flight controller, data‑link module, and navigation receiver. The servos are mounted inside the tail and connected to the flight controller via dedicated signal cables. These cables run along the slender tail boom and are exposed to external electromagnetic fields. Three primary back‑door coupling paths were identified: (1) direct field‑to‑cable coupling on the servo signal lines, which can act as efficient receiving antennas at resonance; (2) radiation coupling through apertures or non‑perfect shielding in the fuselage; (3) interference with attitude sensors located near the tail. Among these, the servo signal cables are directly linked to the PWM control signals that command tail‑fin deflection, making them the most plausible path for inducing jitter. Furthermore, the cables are unshielded and share a common ground return with the power line, leading to imbalance and common‑mode to differential‑mode conversion.
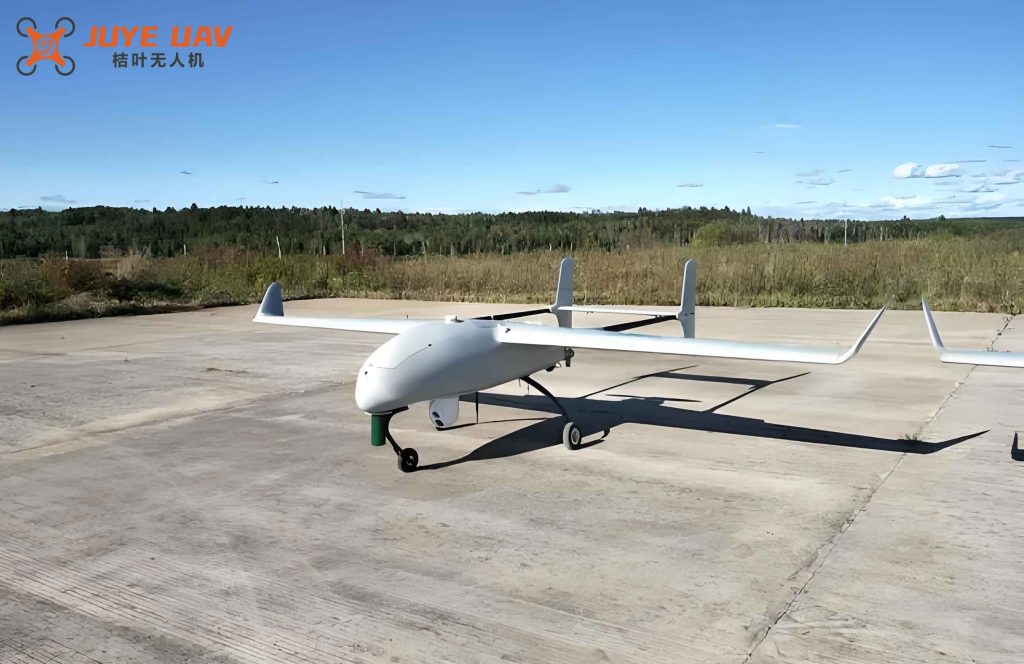
Field‑to‑Cable Coupling Simulation
Model Construction
We built a three‑dimensional model of the small fixed‑wing UAV using SolidWorks and imported it into CST. The fuselage baseplate, motor, and payload enclosure were assigned magnesium‑aluminum alloy material parameters, while the remaining structure was set as dielectric (relative permittivity εr = 4.3, μr = 1). The internal cables were modeled according to actual routing: two servo signal cables (C1‑rudder and C1‑elevator) running along the tail boom, one coaxial data‑link cable (C2) from the flight controller to the top‑mounted antenna, one three‑phase power cable (C3) connecting the electronic speed controller to the brushless motor, one coaxial GPS antenna feed cable (C4), and one power supply cable (C5) inside the battery compartment. Table 1 lists the measured physical dimensions of these cables.
| Cable ID | Length | r1 (conductor radius) | r2 (insulation outer radius) | r3 (outer conductor radius) | r4 (jacket outer radius) |
|---|---|---|---|---|---|
| C1‑rudder | 620.4 | 0.4 | 0.6 | − | − |
| C1‑elevator | 815.6 | 0.4 | 0.6 | − | − |
| C2 | 216.7 | 0.5 | 0.84 | 1.0 | 1.5 |
| C3 | 230.9 | 0.5 | 1.2 | − | 1.8 |
| C4 | 226.0 | 0.5 | 0.84 | 1.0 | 1.5 |
| C5 | 64.7 | 1.0 | 1.5 | − | − |
Simulation Setup
The incident wave was defined as a uniform plane wave with adjustable polarization angle α, elevation angle θ (fixed at 90° for horizontal incidence in the x‑y plane), and azimuth angle ϕ. Two incidence directions were considered: nose‑on (ϕ = 180°) and left‑broadside (ϕ = 270°). Two polarization states were applied: horizontal (α = 0°, electric field parallel to the UAV x‑axis) and vertical (α = 90°, electric field perpendicular to the x‑axis). Thus four representative illumination scenarios were simulated. The excitation was a Gaussian pulse covering 0 – 500 MHz, with a peak field strength of 100 V/m. All cable ports were terminated with 50 Ω loads. Voltage probes were placed at the cable connection points to the flight controller and to the servos.
Simulation Results
Figure 6 (described textually) shows the induced voltage at the cable ports as a function of frequency for the four scenarios. Across all cases, the rudder servo cable (C1‑rudder) exhibited the highest coupling voltage, followed by the elevator servo cable (C1‑elevator), the power supply cable (C5), the three‑phase motor cable (C3), and finally the two coaxial cables (C2 and C4) whose voltages remained below 0.46 V due to effective shielding. The maximum voltage on C1‑rudder reached 7.74 V under horizontal polarization and broadside incidence, which was about 68 % higher than the 4.61 V observed under vertical polarization with the same incidence direction. In the nose‑on case, horizontal polarization gave 4.61 V while vertical gave 4.03 V. This strong polarization dependence confirms that the electric field component parallel to the cable axis is the dominant excitation mechanism.
The servo cables displayed distinct resonant peaks in the 100 – 500 MHz range. The major resonance frequencies were approximately 172 MHz, 261 MHz, and 336 MHz in the simulation. These frequencies align well with the half‑wavelength resonance condition of a transmission line. The theoretical half‑wave resonance frequency for a cable of length L embedded in a dielectric with relative permittivity εr is given by:
$$ f_{\text{res}} = \frac{n c}{2 L \sqrt{\varepsilon_r}}, \quad n = 1,2,3,\dots $$
Using L = 0.6204 m for the rudder cable and εr = 2.2 (polyethylene insulation), we compute the first three harmonic frequencies as 163 MHz, 248 MHz, and 326 MHz. These theoretical values are in excellent agreement with the simulation peaks (difference less than 5 %) and with the experimental sensitive frequencies (165 MHz, 241 MHz, 337 MHz). Table 2 provides a direct comparison.
| Harmonic order | Theoretical (MHz) | Simulated (MHz) | Experimental (MHz) |
|---|---|---|---|
| 1 | 163 | 172 | 165 |
| 2 | 248 | 261 | 241 |
| 3 | 326 | 336 | 337 |
Small deviations are attributed to the cable being not perfectly straight inside the fuselage, which increases the effective electrical length, and to the finite ground plane effect in the simulation model. Nevertheless, the overall coincidence strongly supports the conclusion that cable resonance is the root cause of the frequency‑selective coupling.
Continuous‑Wave Irradiation Experiment
Experimental Setup
We conducted the experiments inside a microwave anechoic chamber. A vector signal source generated a single‑frequency CW signal, which was amplified by a power amplifier and radiated by a log‑periodic antenna placed 2 m from the UAV, with the UAV positioned 1.2 m above the ground. A GPS signal simulator provided equivalent satellite navigation signals so that the UAV’s navigation receiver remained operational. The flight controller, data‑link, and servos were powered by an internal battery. A high‑speed camera recorded the tail‑fin motion, and field‑strength probes monitored the electric field near the UAV. The ground‑control station logged telemetry data. The frequency range was swept from 100 MHz to 400 MHz in steps of 1 MHz, covering the resonance region identified in the simulation. For each frequency, the field strength was gradually increased until the tail‑fin started to jitter, and the threshold field strength was recorded.
Observed Effects and Sensitive Frequencies
During the sweep, we observed two types of back‑door coupling effects: sensor parameter fluctuations (e.g., pitch and roll angle readings) and non‑command tail‑fin oscillations. The tail‑fin jitter was more repeatable and occurred at lower field strengths than sensor fluctuations, so we focused on jitter as the representative effect. Table 3 summarizes the sensitive frequency bands and the corresponding thresholds for the worst‑case polarization and incidence (horizontal polarization, left‑broadside incidence).
| Frequency band (MHz) | Minimum threshold (V/m) | Remarks |
|---|---|---|
| 155–175 | 52.6 at 165 MHz | Vertical tail jitter first, then horizontal tail |
| 230–255 | 80.2 at 241 MHz | Both tails jitter; pitch/roll readings fluctuate |
| 325–350 | 146.3 at 337 MHz | Pitch/roll readings fluctuate, less visible jitter |
The field‑strength threshold versus frequency curves exhibited a characteristic V‑shape around each sensitive center frequency. The jitter amplitude increased continuously with field strength, but outside the sensitive bands no jitter was observed even at the maximum available field strength. The three center frequencies (165 MHz, 241 MHz, 337 MHz) correspond precisely to the half‑wavelength resonances of the rudder servo cable. The vertical tail (rudder) jitter always appeared before the horizontal tail (elevator) jitter, consistent with the rudder cable having a stronger coupling due to its length and orientation. Under vertical polarization or nose‑on incidence, the thresholds were higher (up to 80–150 V/m), but the sensitive center frequencies remained unchanged, confirming that the resonance mechanism is independent of illumination angle and polarization.
To further confirm that the jitter is not caused by the flight controller’s attitude loop, we analyzed the time‑domain waveform of the vertical tail deflection angle. Figure 9 (described textually) shows a typical record under 150 MHz, 100 V/m irradiation. The jitter was high‑frequency and aperiodic, with a broad distribution of deflection angles ranging from −20° to +20°, showing no correlation with the 10 Hz flight‑control update cycle. This rules out the possibility that the interference is transmitted through the sensor‑feedback path and instead points to direct injection of noise into the PWM signal at the servo input.
Mechanism of Tail‑Fin Jitter
Based on the simulation and experimental evidence, we propose the following mechanism for the field‑induced tail‑fin jitter in a small fixed‑wing UAV. When the external CW field frequency coincides with a half‑wave resonance of the servo signal cable, a strong common‑mode current Icm is induced along the cable. In an ideal balanced three‑wire configuration (signal, power, ground), this common‑mode current would not produce a differential voltage across the PWM signal terminals. However, the actual cable assembly in the UAV uses a twisted triplet without a shield, and the servo controller’s input impedance is not perfectly balanced. The resulting impedance imbalance Zunbalance converts part of the common‑mode current into a differential‑mode voltage ΔVdm:
$$ \Delta V_{\text{dm}} = I_{\text{cm}} \cdot Z_{\text{unbalance}} $$
This differential‑mode noise voltage adds directly to the PWM control pulse. The servo controller detects the pulse width by comparing the input signal with an internal reference. A small shift in the pulse leading or trailing edge caused by ΔVdm leads to an erroneous measured pulse width, and consequently to an undesired servo angle command. The error magnitude is proportional to ΔVdm, which in turn increases linearly with the incident field strength. This explains the observed continuous increase of jitter amplitude with field strength. Moreover, because the resonance is frequency‑selective, the jitter only appears within narrow bands around the resonant frequencies. The fact that the vertical tail (rudder) is more sensitive than the horizontal tail (elevator) is due to the rudder cable being longer (0.620 m vs. 0.816 m for elevator) but also to its more direct exposure inside the tail boom structure.
We also investigated the influence of cable shielding. The coaxial cables (C2, C4) and the three‑phase motor cable (C3) did not induce jitter because their shields or balanced construction effectively suppress common‑mode currents. The power cable (C5) is short (64.7 mm) and its resonance occurs above 2 GHz, outside our measurement range. Therefore, the unshielded servo signal cables are the primary vulnerable path.
Conclusion
Through combined simulation and experimental investigation, we have elucidated the field‑to‑cable coupling mechanism responsible for continuous‑wave electromagnetic interference in a small fixed‑wing UAV. The key findings are:
- The servo signal cables (especially the rudder cable) are the most sensitive back‑door coupling path. Their half‑wave resonances at 165 MHz, 241 MHz, and 337 MHz produce strong common‑mode currents that convert into differential‑mode noise due to impedance imbalance, causing jitter of the tail fins.
- The interference effect is highly frequency‑selective. The lowest threshold field strength (52.6 V/m) occurs at 165 MHz under horizontal polarization with left‑broadside incidence. Changing polarization or incidence direction increases the threshold but does not alter the sensitive frequencies.
- The jitter amplitude grows continuously with field strength, consistent with a linear conversion from common‑mode current to differential‑mode voltage.
These results provide a solid theoretical and experimental basis for designing electromagnetic hardening measures for small fixed‑wing UAVs. Future work could explore the effects of cable shielding, twisting pitch, and termination impedance on the common‑mode to differential‑mode conversion, as well as the susceptibility under modulated or pulsed waveforms. Understanding the coupling mechanism is the first step toward developing effective protection strategies and also informs countermeasure techniques that exploit these vulnerabilities.