
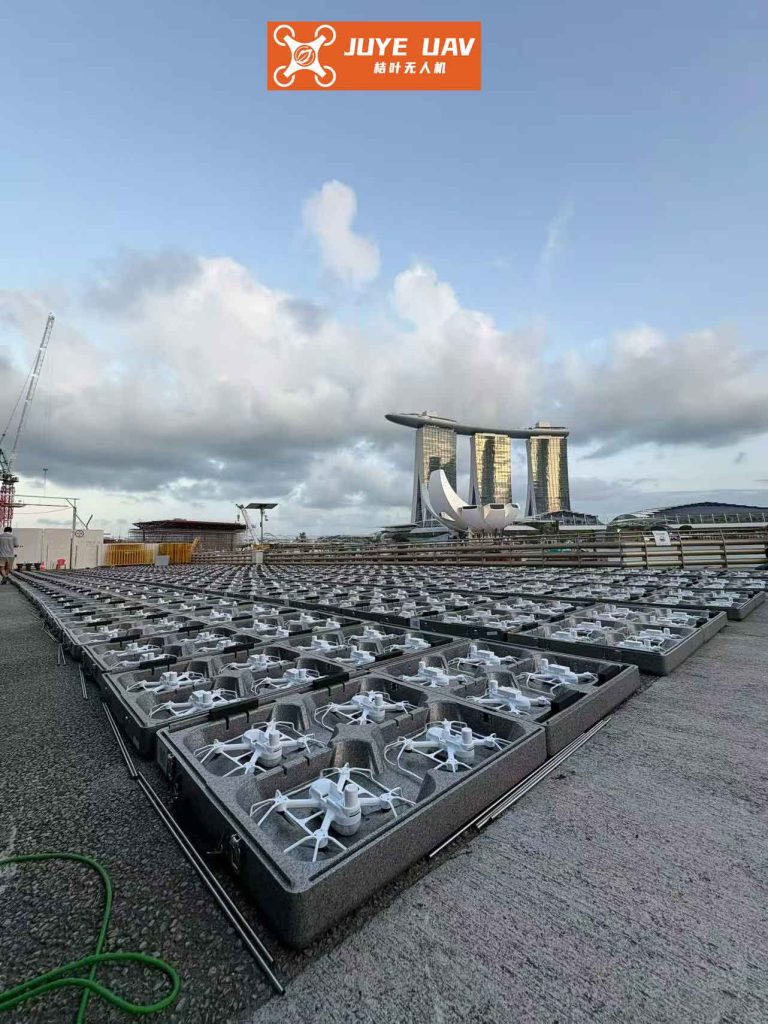
The night sky, once a passive backdrop, has been transformed into a dynamic, luminous stage by the advent of formation drone light shows. This spectacular fusion of art and technology relies not on magic, but on the precise, coordinated control of hundreds, sometimes thousands, of unmanned aerial vehicles (UAVs). Each drone acts as a single pixel of light, and together, they form breathtaking, animated three-dimensional shapes. The core challenge enabling this modern marvel is formation drone light show control—the algorithms and systems that allow a swarm to behave as a cohesive, intelligent entity. Unlike single drone operations, a synchronized formation drone light show offers unparalleled scalability, reliability through redundancy, and the ability to create complex, moving artworks impossible for any single craft. This article delves into the technical heart of this phenomenon, presenting an advanced control framework based on an improved consensus algorithm, designed specifically to meet the rigorous demands of safe, reliable, and stunning aerial performances.
The foundation of any formation drone light show is a precise mathematical description of the desired aerial sculpture. We define the formation shape using relative position matrices. For a swarm of $n$ drones, we establish three matrices, $\mathbf{R}_x$, $\mathbf{R}_y$, and $\mathbf{R}_z$, which define the ideal relative distances between every pair of drones along the North ($X$), East ($Y$), and vertical ($Z$) axes of a global coordinate frame, respectively. The element $x_{ij}$ in $\mathbf{R}_x$ specifies how far drone $i$ should be from drone $j$ in the $X$-direction when the formation is perfectly achieved. A stable formation drone light show requires that for all drones $i$ and $j$, the following conditions hold as time progresses:
$$ x_i(t) – x_j(t) \rightarrow x_{ij}, \quad y_i(t) – y_j(t) \rightarrow y_{ij}, \quad z_i(t) – z_j(t) \rightarrow z_{ij}, \quad V_i(t) – V_j(t) \rightarrow 0 $$
Where $[x_i, y_i, z_i]^T$ is the position of drone $i$, and $V_i$ is its speed. The matrices are typically skew-symmetric ($x_{ij} = -x_{ji}$) with zeros on the diagonal. Common formations for a formation drone light show, like geometric shapes or logos, are encoded in these matrices.
To control such a swarm, we must first model the dynamics of individual drones. For the high-level planning of a formation drone light show, we often use a simplified, decoupled 3-Degree-of-Freedom (3-DOF) kinematic model with autopilot loops. This model separates horizontal motion from vertical motion, which is suitable for trajectory generation. The model is given by:
$$
\begin{align}
\dot{x}_i &= v_{xi} \\
\dot{y}_i &= v_{yi} \\
\dot{z}_i &= v_{zi} \\
\dot{v}_{xi} &= \frac{1}{\tau_v} (v_{xi}^c – v_{xi}) \\
\dot{v}_{yi} &= \frac{1}{\tau_v} (v_{yi}^c – v_{yi}) \\
\ddot{z}_i &= -\frac{1}{\tau_{\dot{z}}} \dot{z}_i + \frac{1}{\tau_z} (z_i^c – z_i)
\end{align}
$$
Here, $[v_{xi}, v_{yi}]^T$ is the horizontal velocity, $v_{zi}$ is the climb rate (vertical speed), and $\dot{z}_i$ is equivalent to $v_{zi}$. The control inputs are the commanded horizontal velocities $v_{xi}^c, v_{yi}^c$ and the commanded altitude $z_i^c$. The time constants $\tau_v, \tau_z, \tau_{\dot{z}}$ represent the response characteristics of the drone’s autopilot. Crucially, a real formation drone light show must operate within strict physical and safety constraints:
| Constraint Type | Variable | Limit | Physical Meaning |
|---|---|---|---|
| Horizontal Motion | Speed $v_i$ | $v_{min} \le v_i \le v_{max}$ | Limits drone speed for safety and battery life. |
| Acceleration $a_i$ | $a_{min} \le a_i \le a_{max}$ | Limits physical stress and motor capability. | |
| Turn Rate $\dot{\phi}_i$ | $\omega_{min} \le \dot{\phi}_i \le \omega_{max}$ | Limits how sharply a drone can turn. | |
| Vertical Motion | Climb Rate $v_{zi}$ | $\dot{z}_{min} \le v_{zi} \le \dot{z}_{max}$ | Limits vertical speed for stability. |
| Climb Accel. $\ddot{z}_i$ | $\ddot{z}_{min} \le \ddot{z}_i \le \ddot{z}_{max}$ | Limits vertical acceleration. | |
| Safety | Inter-Drone Distance $d_{ij}$ | $d_{ij} \ge d_{safe}$ | Prevents collisions between drones. |
Any control algorithm for a formation drone light show must generate commands that respect these constraints at all times.
Consensus theory provides a powerful, distributed framework for formation drone light show control. The core idea is simple yet profound: each drone communicates only with its “neighbors” in the network and adjusts its own state based on the differences between its state and its neighbors’ states. Over time, this local interaction drives the entire swarm to a global agreement. For a basic double-integrator agent model $\dot{x}_i = v_i, \dot{v}_i = u_i$, the consensus control law is:
$$ u_i = -\sum_{j=1}^{n} a_{ij} \left[ (x_i – x_j) + \alpha (v_i – v_j) \right] $$
Here, $a_{ij}$ is an element of the adjacency matrix representing the communication topology (e.g., $a_{ij}=1$ if drones $i$ and $j$ can talk). The parameter $\alpha > 0$ is a gain. Under a connected communication graph, this law ensures that $x_i \rightarrow x_j$ and $v_i \rightarrow v_j$ for all $i, j$ as $t \rightarrow \infty$. For a formation drone light show, we need consensus not just on positions and velocities, but on maintaining specific, pre-defined offsets—this is formation consensus.
We develop the formation control law by adapting the basic consensus principle to our 3-DOF model and incorporating the formation shape matrices $\mathbf{R}_x, \mathbf{R}_y, \mathbf{R}_z$. The control objective is to generate commanded inputs $(v_{xi}^c, v_{yi}^c, z_i^c)$ for each drone. The proposed distributed control laws are:
$$
\begin{align}
\text{Horizontal X:} \quad & v_{xi}^c = v_{xi} + \tau_v u_{xi}, \quad u_{xi} = -\sum_{j=1}^{n} a_{ij} \left[ (v_{xi} – v_{xj}) + k_x (x_i – x_j – x_{ij}) \right] – b_i(v_{xi} – v_x^*) \\
\text{Horizontal Y:} \quad & v_{yi}^c = v_{yi} + \tau_v u_{yi}, \quad u_{yi} = -\sum_{j=1}^{n} a_{ij} \left[ (v_{yi} – v_{yj}) + k_y (y_i – y_j – y_{ij}) \right] – c_i(v_{yi} – v_y^*) \\
\text{Vertical:} \quad & z_i^c = z_i + \tau_z \tau_{\dot{z}} v_{zi} + \tau_z u_{zi}, \quad u_{zi} = -\sum_{j=1}^{n} a_{ij} \left[ (z_i – z_j – z_{ij}) + \gamma (v_{zi} – v_{zj}) \right] – d_i(z_i – z^*)
\end{align}
$$
In these equations, $u_{xi}, u_{yi}$ act as virtual horizontal acceleration commands, and $u_{zi}$ acts as a virtual vertical (climb) acceleration command. The terms $(v_x^*, v_y^*)$ and $z^*$ are the desired swarm velocity and altitude. The critical addition for formation drone light show control is the incorporation of the formation errors $(x_i – x_j – x_{ij})$, etc. This term ensures drones not only try to match each other’s states but also strive to maintain the specific pattern defined by $\mathbf{R}$. The gains $k_x, k_y, \gamma, b_i, c_i, d_i$ are positive tuning parameters that affect convergence rate and stability.
The raw commands $(u_{xi}, u_{yi}, u_{zi})$ generated by the consensus algorithm may violate the physical constraints listed earlier. A key contribution for practical formation drone light show deployment is a “Minimal Adjustment” constraint-handling strategy. This strategy modifies the raw commands just enough to satisfy all constraints, prioritizing minimal deviation from the consensus algorithm’s intended control action. The adjustment is performed in two decoupled steps: first for the horizontal plane $(u_{xi}, u_{yi})$, then for the vertical axis $(u_{zi})$.
Step 1: Horizontal Constraint Handling. The horizontal acceleration magnitude is $a_i = \sqrt{u_{xi}^2 + u_{yi}^2}$. We first enforce speed and acceleration limits. From the current speed $v_i(t)$, we compute the acceleration limits required to keep the next timestep’s speed within $[v_{min}, v_{max}]$:
$$ a’_{min,i} = \frac{v_{min} – v_i}{\Delta t}, \quad a’_{max,i} = \frac{v_{max} – v_i}{\Delta t} $$
The final feasible acceleration bounds are:
$$ a^{new}_{min,i} = \max(a_{min}, a’_{min,i}), \quad a^{new}_{max,i} = \min(a’_{max,i}, a_{max}) $$
If $a_i$ is outside $[a^{new}_{min,i}, a^{new}_{max,i}]$, we scale the acceleration vector to the nearest bound:
$$ (u’_{xi}, u’_{yi}) = \left( \frac{a^{new}_{bound,i}}{a_i} u_{xi}, \frac{a^{new}_{bound,i}}{a_i} u_{yi} \right) $$
Next, we enforce the turn rate constraint $\dot{\phi}_i \in [\omega_{min}, \omega_{max}]$. The predicted next heading based on $(u’_{xi}, u’_{yi})$ is $\phi_i(t+\Delta t) = \arctan\left( \frac{v_{yi}+u’_{yi}\Delta t}{v_{xi}+u’_{xi}\Delta t} \right)$. If this violates the heading change limit derived from $\dot{\phi}$, we solve for a new acceleration vector $(u”_{xi}, u”_{yi})$ that lies on the circle of radius $a^{new}_{bound,i}$ and points to a just-feasible heading. Among the two mathematical solutions, we choose the one that minimizes the change in the acceleration vector’s direction, adhering to the “minimal adjustment” principle.
Step 2: Vertical Constraint Handling. For the climb acceleration $u_{zi}$, the process is more direct. We combine the climb rate and climb acceleration constraints. The climb rate limits $[\dot{z}_{min}, \dot{z}_{max}]$ are translated into equivalent acceleration limits for the current timestep:
$$ \ddot{z}’_{min,i} = \frac{\dot{z}_{min} – v_{zi}}{\Delta t}, \quad \ddot{z}’_{max,i} = \frac{\dot{z}_{max} – v_{zi}}{\Delta t} $$
The final feasible climb acceleration bounds are:
$$ \ddot{z}^{new}_{min,i} = \max(\ddot{z}_{min}, \ddot{z}’_{min,i}), \quad \ddot{z}^{new}_{max,i} = \min(\ddot{z}’_{max,i}, \ddot{z}_{max}) $$
The adjusted climb command is simply:
$$ u’_{zi} = \max\left( \ddot{z}^{new}_{min,i}, \min(u_{zi}, \ddot{z}^{new}_{max,i}) \right) $$
This two-step process ensures all kinematic constraints are met for a safe formation drone light show.
Meeting kinematic constraints does not guarantee collision avoidance. Drones might still breach the minimum safe distance $d_{safe}$ during aggressive maneuvers or formation transitions. To address this, we introduce a collision avoidance strategy that operates on the vertical ($Z$) axis control, as modifying horizontal motion might re-violate previously satisfied constraints. After obtaining the vertically adjusted command $u’_{zi}$ from Step 2 above, we predict positions at the next timestep. If any pair of drones is forecast to have a distance $d_{ij} < d_{safe}$, we optimize the vertical climb accelerations $u”_{zi}$ for all drones.
We formulate this as a constrained optimization problem solved using a Particle Swarm Optimization (PSO) algorithm at each control step if a collision is imminent. The optimization vector is $\mathbf{u}”_z = [u”_{z1}, u”_{z2}, …, u”_{zn}]$. The objective is to minimize the total adjustment from the kinematically-feasible commands:
$$ J = \sum_{i=1}^{n} | u”_{zi} – u’_{zi} | $$
The optimization is subject to two sets of constraints: 1) Each $u”_{zi}$ must remain within its feasible bounds $[\ddot{z}^{new}_{min,i}, \ddot{z}^{new}_{max,i}]$, and 2) The predicted distance between any two drones $i$ and $j$ must satisfy $d_{ij} \ge d_{safe}$. The PSO algorithm efficiently searches for a set of vertical adjustments that resolves the collision while staying as close as possible to the original formation control intent, a critical feature for maintaining the visual integrity of a formation drone light show.
The complete, improved consensus algorithm for formation drone light show control is robust and versatile. It can handle both formation assembly (drones starting from random positions converging into a shape) and formation transitioning (smoothly morphing from one shape to another by updating the $\mathbf{R}$ matrices). The integration of the “minimal adjustment” strategy and the PSO-based collision avoidance ensures the generated flight commands are not only effective but also safe and physically realizable. The stability of the overall closed-loop system can be analyzed using Lyapunov theory, showing that the swarm states converge to a small region around the desired formation despite the bounded adjustments made to handle constraints.
| Feature / Method | Basic Consensus | Improved Consensus (Proposed) |
|---|---|---|
| Formation Shape Keeping | Yes, with shape matrices | Yes, with shape matrices |
| Velocity/State Consensus | Yes | Yes |
| Kinematic Constraint Handling | No | Yes (“Minimal Adjustment” Strategy) |
| Collision Avoidance | No | Yes (PSO-based Vertical Optimization) |
| Distributed Computation | Yes | Yes (Local neighbor info required) |
| Suitability for Real Shows | Low (Unsafe) | High (Safe & Practical) |
The technological framework described here represents a significant step towards more complex, reliable, and awe-inspiring formation drone light shows. By grounding the artistic vision in rigorous multi-agent control theory and robust safety engineering, we enable swarms to act as truly programmable aerial pixels. Future directions include integrating robust communication protocols to handle real-world signal loss, adaptive algorithms for wind disturbance rejection, and even higher-level choreography planning tools that automatically translate artistic intent into the low-level $\mathbf{R}$ matrices and trajectories. As these technologies mature, the scale and complexity of formation drone light shows will continue to grow, further solidifying their place as a dominant form of public spectacle and artistic expression in the 21st century, painting the night sky with intelligence and light.