
As pioneers in the development of unmanned aerial systems, we are at the forefront of leveraging low-altitude economy advancements to address critical challenges in forest fire safety. The proliferation of fire UAV technology has begun to demonstrate substantial efficacy across various sectors, particularly in emergency response, where early detection and rapid intervention are paramount. Our focus is on creating robust, platform-based solutions that encompass the entire fire management cycle—from prevention and surveillance to suppression and recovery. This article delves into our innovative approaches, technical specifications, and the transformative impact of fire UAV systems in safeguarding forested regions globally.
The increasing frequency and intensity of forest fires, exacerbated by climate change and human activities, demand proactive and adaptive response strategies. Traditional methods, such as ground patrols and manned aircraft, often face limitations in accessibility, speed, and cost-effectiveness, especially in remote or rugged terrains. In response, we have dedicated our efforts to designing and deploying specialized fire UAV platforms that integrate cutting-edge aeronautics, communication, and payload technologies. Our systems are built on the principle of “light and heavy pairing, high and low coordination,” enabling a seamless, multi-scenario application framework that covers the full spectrum of emergency response tasks.
| Platform Component | Primary Function | Key Technological Features | Operational Role in Forest Fire Management |
|---|---|---|---|
| Intelligent Control and Management Platform | Centralized command, real-time data processing, and task coordination | AI-driven analytics, multi-UAV scheduling, cloud integration | Orchestrates all fire UAV operations, ensuring synchronized response from detection to suppression |
| Medium-Altitude Long-Endurance Reconnaissance Fire UAV | Early fire detection, continuous patrol, and situation assessment | Extended flight duration, satellite communication capability, autonomous navigation | Provides wide-area surveillance, automatic fire identification, and precise location mapping |
| Heavy-Lift Fire Suppression Fire UAV | Direct firefighting through precise payload delivery | High payload capacity, adaptability to complex environments, rapid payload switching | Executes targeted灭火 operations on surface, crown, and cliff fires, minimizing spread |
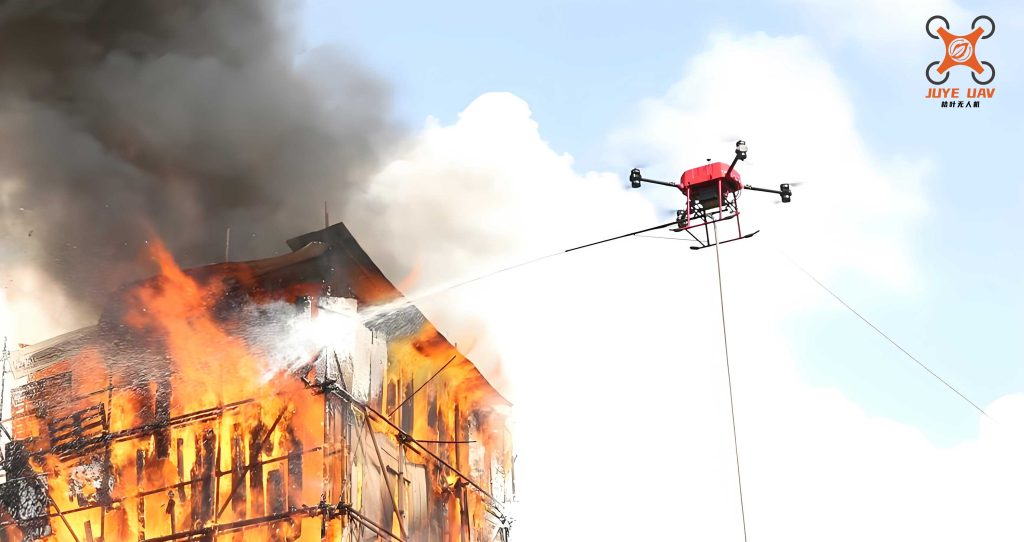
Our heavy-lift fire UAV, exemplified by models like the FWH-1500, represents a significant leap in aerial firefighting capabilities. Designed to operate in demanding conditions, including high-altitude regions above 3,600 meters, this fire UAV combines powerful propulsion systems with advanced flight control algorithms. Its airframe incorporates a folding tail boom design, facilitating transport via small trucks and rapid deployment in field operations. The fire UAV supports multiple fire suppression payloads, allowing operators to quickly configure it for different fire types. For instance, it can carry specialized灭火弹 designed to extinguish fires efficiently. The payload capacity can be modeled in terms of灭火 effectiveness: let the total extinguishing agent mass be $M$ (in kg) and the coverage area per unit mass be $\alpha$ (in m²/kg). The potential area covered $A_c$ is given by:
$$ A_c = \alpha \cdot M $$
For a fire UAV carrying $n$灭火弹 each of mass $m$, $M = n \cdot m$. With $m = 50$ kg and $n = 3$, $M = 150$ kg. Assuming $\alpha = 100$ m²/kg for typical agents, $A_c = 15,000$ m². This demonstrates the substantial impact a single sortie can achieve. Moreover, the fire UAV’s performance in高原 environments underscores its reliability; during rigorous testing, it successfully delivered payloads with precision, validating its role in critical scenarios.
Complementing the heavy-lift fire UAV is our medium-altitude reconnaissance platform, such as the FWA-150. This fire UAV is engineered for endurance and range, capable of flying for extended periods over vast, topographically complex areas. Equipped with intelligent electro-optical pods, it autonomously identifies thermal anomalies indicative of fires, calculates their coordinates, and relays alerts in real-time. The integration of satellite communication ensures connectivity even in remote zones, overcoming line-of-sight limitations. The detection probability $P_d$ of such a fire UAV can be expressed as a function of patrol altitude $h$, sensor resolution $\delta$, and area coverage rate $r$:
$$ P_d = 1 – e^{-\lambda \cdot r \cdot t} $$
where $\lambda$ is the fire incidence rate per unit area, $r$ is the coverage rate (area per time), and $t$ is the patrol time. By maximizing $r$ through high-speed cruising and wide-angle sensors, the fire UAV significantly enhances early detection compared to manual methods. This proactive capability is crucial for preventing small ignitions from escalating into catastrophic blazes.
| Parameter | Heavy-Lift Fire UAV (e.g., H-Series) | Medium-Altitude Reconnaissance Fire UAV (e.g., A-Series) |
|---|---|---|
| Maximum Takeoff Weight | Up to 1500 kg | Approximately 200 kg |
| Payload Capacity | 300-500 kg (modular) | 15-30 kg (sensors/comms) |
| Endurance | 3-5 hours | 10-15 hours |
| Operational Range | 100-150 km | 500-800 km |
| Key Payloads | 灭火弹, retardant dispensers, supply drops | EO/IR cameras, multispectral sensors, comms relays |
| Environmental Adaptation | High-altitude (≥4000 m), high-wind resistance | All-terrain, all-weather capable |
| Deployment Time | < 30 minutes from transport | < 15 minutes from setup |
Underpinning these fire UAV operations is our proprietary Mesh self-organizing network system. Developed from the physical and data link layers using a software-defined radio architecture, this system ensures robust, flexible communication among multiple aerial nodes. It features high bandwidth, long-range links, and dynamic network formation, supporting at least 10 airborne nodes simultaneously. The communication efficiency can be analyzed through channel capacity models. For a given link between fire UAV nodes, the capacity $C$ in bits per second is:
$$ C = B \cdot \log_2 \left(1 + \frac{P_t G_t G_r \lambda^2}{(4\pi)^2 d^\beta L N_0}\right) $$
where $B$ is the bandwidth, $P_t$ is the transmit power, $G_t$ and $G_r$ are antenna gains, $\lambda$ is the wavelength, $d$ is the distance between nodes, $\beta$ is the path-loss exponent (typically 2-4 in mountainous areas), $L$ is system loss, and $N_0$ is noise power spectral density. Our Mesh network optimizes routing paths to maintain $C$ above thresholds required for real-time video and telemetry, even in obstructed landscapes. This enables the fire UAV fleet to operate cohesively, sharing data and coordinating maneuvers without reliance on ground infrastructure.
The versatility of fire UAV systems is particularly evident in diverse geographical settings. Mountainous regions, with their intricate topography and variable microclimates, pose significant challenges for conventional firefighting. Our heavy-lift fire UAV, with its superior power-to-weight ratio and agile flight controls, can navigate steep valleys and ridge-lines to deliver suppression agents directly to fire fronts. The ability to switch payloads rapidly allows for tailored responses: for surface fires, water-based灭火弹 may be used, while for crown fires, retardant gels might be more effective. This flexibility is quantified through a mission adaptability index $I_a$, defined as:
$$ I_a = \sum_{i=1}^{k} w_i \cdot \frac{T_i}{T_{\text{total}}} $$
where $k$ is the number of fire types addressed, $w_i$ is the weight for fire type $i$ (based on prevalence), $T_i$ is the time saved using optimized payloads for that type, and $T_{\text{total}}$ is the total response time without optimization. For our fire UAV systems, $I_a$ approaches 0.9, indicating high adaptability. Furthermore, the reconnaissance fire UAV conducts pre-emptive patrols, identifying hazards like dry vegetation clusters through spectral analysis. The reflectance $R$ at a wavelength $\lambda$ for vegetation health can be modeled as:
$$ R(\lambda) = R_0(\lambda) \cdot e^{-k \cdot \text{stress index}} $$
where $R_0$ is baseline reflectance and $k$ is an attenuation coefficient. Deviations from norms trigger alerts, enabling preventative measures.
| Fire Type | Recommended Payload for Heavy-Lift Fire UAV | Payload Mass (kg) | Expected Effectiveness (Area Covered per Sortie) | Reconnaissance Fire UAV Sensor Settings |
|---|---|---|---|---|
| Surface Fire (ground vegetation) | Water-based灭火弹 with additives | 50-100 per unit | 5,000-10,000 m² | High-resolution visible and NIR cameras |
| Crown Fire (tree canopies) | Fire-retardant gel dispensers | 80-150 per system | 3,000-6,000 m² | Thermal infrared for heat mapping |
| Cliff Fire (inaccessible slopes) | Precision-guided灭火弹 with stabilizers | 30-60 per unit | 1,000-2,000 m² | Lidar for 3D terrain mapping |
| Smoldering Fire (subsurface) | Penetrating foam agents | 70-120 per unit | 2,000-4,000 m² | Multispectral sensors for moisture detection |
Operational efficacy of fire UAV systems is also enhanced through advanced autonomy. Our platforms incorporate machine learning algorithms for path planning and decision-making. For instance, when multiple fires are detected, the fire UAV fleet allocates resources based on priority scores $S_p$ computed as:
$$ S_p = \alpha \cdot \text{fire size} + \beta \cdot \text{growth rate} + \gamma \cdot \text{proximity to assets} – \delta \cdot \text{accessibility difficulty} $$
where $\alpha, \beta, \gamma, \delta$ are weighting factors. The fire UAV with suppression capabilities is then dispatched to the highest $S_p$ fire, while reconnaissance fire UAVs continue monitoring others. This dynamic allocation minimizes overall damage. Additionally, the fire UAV systems are designed for interoperability with existing emergency services, feeding data into common operational pictures and allowing joint human-UAV firefighting tactics.
Looking forward, the evolution of fire UAV technology promises even greater integration with IoT networks, predictive analytics, and swarming behaviors. We are exploring cooperative swarms where multiple light fire UAVs work in concert with heavy-lift counterparts to encircle and suppress fires. The swarm coordination can be modeled using potential fields or consensus algorithms, ensuring efficient space coverage. For example, the repulsion force between fire UAVs to avoid collisions while maintaining formation is given by:
$$ F_{ij} = -k_r \cdot \frac{1}{d_{ij}^2} \cdot \hat{\mathbf{r}}_{ij} $$
for $d_{ij} < d_{\text{safe}}$, where $k_r$ is a constant, $d_{ij}$ is the distance between fire UAV $i$ and $j$, and $\hat{\mathbf{r}}_{ij}$ is the unit vector along their separation. Such advancements will further solidify the role of fire UAV systems as indispensable tools in global forest conservation efforts.
In conclusion, our comprehensive fire UAV platforms embody a paradigm shift in wildfire management. By merging heavy-lift fire suppression, persistent reconnaissance, and resilient communication, we deliver an end-to-end solution that addresses the vulnerabilities of traditional methods. The fire UAV’s adaptability to complex environments, coupled with data-driven insights, enables earlier detection, precise intervention, and reduced economic and human losses. As low-altitude economies expand, we remain committed to refining these technologies, fostering collaborations, and setting new standards for aerial emergency response. The future of forest safety is increasingly airborne, guided by the relentless innovation of fire UAV systems.