
As a professional deeply involved in the field of natural disaster prevention and forestry management, I have witnessed firsthand the devastating impact of forest fires. These catastrophic events pose a significant threat to ecosystems, biodiversity, and human safety. Traditional forest fire monitoring and fighting systems, while foundational, often present critical gaps in coverage, timeliness, and safety. In recent years, the integration of Unmanned Aerial Vehicle (UAV) systems, specifically designed as or repurposed into fire drone platforms, has emerged as a revolutionary force. These systems are not merely supplements but are becoming central to a modern, responsive, and data-driven approach to forest fire management. The application of a fire drone is multifaceted, addressing needs from pre-ignition patrols to post-fire analysis, thereby offering a versatile and powerful tool for authorities.
The limitations of conventional methods are well-documented. Satellite remote sensing, though excellent for large-scale thermal anomaly detection, suffers from low temporal resolution and can be obscured by cloud cover. Manned aerial patrols, the gold standard for speed and range, are constrained by high operational costs, stringent weather dependencies, and inherent pilot safety risks. Ground-based watchtowers and patrols are labor-intensive and limited by line-of-sight and terrain accessibility. It is within this operational landscape that the fire drone system presents a paradigm shift. By offering a low-cost, highly flexible, and risk-averse aerial platform, fire drone technology effectively bridges the critical gaps in the existing “space-air-ground” integrated monitoring network.
The core advantage of deploying a fire drone lies in its operational flexibility and economic efficiency. Unlike manned aircraft, a fire drone can be rapidly deployed from virtually any location, operates effectively at very low altitudes for detailed inspection, and can fly in conditions that would ground traditional pilots, such as at night or in smoky environments. This capability for persistent, close-range surveillance is transformative for early detection. The economic argument is equally compelling. The acquisition, operation, and maintenance costs of a sophisticated fire drone fleet are a fraction of those for manned helicopters, democratizing aerial surveillance for local forestry departments and enabling more frequent and targeted patrols.
| Methodology | Key Advantages | Primary Limitations | Role of Fire Drone Integration |
|---|---|---|---|
| Satellite Remote Sensing | Global coverage, excellent for large fire detection and burn scar mapping. | Low revisit frequency (hours/days), coarse spatial resolution, cloud obstruction. | Provides high-resolution, real-time ground truthing and fills temporal gaps between satellite passes. |
| Manned Aerial Patrol | High speed, large area coverage, capable of direct intervention (water bombing). | Extremely high cost, weather-dependent, significant safety risk to crew, limited flight duration. | Complements with cost-effective, small-area, high-risk environment patrols, and extended loitering for post-fire monitoring. |
| Ground Watchtowers & Patrols | Simple, provides direct human observation for small areas. | Limited range, terrain blind spots, labor-intensive, slow response time to remote fires. | Extends patrol radius dramatically, accesses rugged terrain, and provides immediate aerial verification of suspected smoke. |
| Ground Sensor Networks | Provides continuous, real-time micro-climate and smoke data. | Very high infrastructure and maintenance cost, limited coverage density, vulnerable to fire damage. | Offers a mobile, redeployable sensor platform that can investigate alerts from fixed sensors and cover areas between them. |
A fire drone system is far more than just the aircraft itself. It is a complex system-of-systems comprising several integrated components:
- The Unmanned Aerial Vehicle (UAV/Aircraft): The physical platform, which can be a fixed-wing, single-rotor, or multi-rotor design.
- Ground Control Station (GCS): The command center where pilots and mission planners control the drone, monitor its status, and receive telemetry and payload data.
- Data Link: The secure communication channel (often RF or satellite-based) between the GCS and the fire drone, enabling control and data transmission.
- Payload Suite: The mission-critical sensors and equipment carried by the fire drone. This is what defines its specific role.
- Launch and Recovery System: Equipment for safe take-off and landing, which can range from a simple hand launch for small drones to catapults or net systems.
- Support Equipment: Including transport vehicles, spare parts, batteries/fuel, and maintenance tools.
The choice of UAV type for a fire drone mission is a critical trade-off analysis. Fixed-wing drones offer superior endurance and speed for covering vast, open areas, making them ideal for large-scale pre-fire patrols. Their flight dynamics are often more energy-efficient. Rotary-wing drones (multicopters and helicopters), while having shorter flight times, provide the invaluable capability of vertical take-off and landing (VTOL) and stationary hover. This makes them perfect for detailed inspection of a specific area, close-range fire monitoring, and precision payload delivery. A hybrid concept, the VTOL fixed-wing fire drone, is increasingly popular, combining the range of fixed-wing with the hover capability of rotors.
| Platform Type | Endurance | Key Strengths | Ideal Fire Management Missions |
|---|---|---|---|
| Fixed-Wing Fire Drone | High (2-24+ hours) | Long range, high speed, efficient cruise. | Large-area preventive patrols, rapid response scouting over long distances, post-fire damage assessment mapping. |
| Multi-Rotor Fire Drone | Low to Medium (20-60 mins) | VTOL, stable hover, high maneuverability in tight spaces. | Targeted hotspot inspection, structure fire assessment, precision payload (sensor/retardant) delivery, close-support for ground teams. |
| Single-Rotor (Helicopter) Fire Drone | Medium (1-4 hours) | VTOL, higher payload capacity than multi-rotor, good endurance. | Heavier payload delivery (e.g., larger fire retardant canisters), long-duration hover over a critical fire front. |
| VTOL Fixed-Wing Fire Drone | Medium to High (1-8 hours) | Combines VTOL with efficient forward flight. | Versatile missions requiring both long transit and detailed inspection (e.g., patrol a forest, then hover over a suspicious area). |
The true power of a fire drone is unlocked by its payload. A modular approach allows the same drone to perform different tasks. The primary sensor for fire detection and monitoring is the thermal imaging camera. It detects heat signatures invisible to the naked eye, allowing a fire drone to “see” through smoke, identify hotspots, and find survivors or personnel. The heat intensity $I$ detected by a microbolometer pixel at a given wavelength can be related to the temperature $T$ of the target via Planck’s radiation law approximations:
$$ I \approx \frac{2\pi h c^2}{\lambda^5} \cdot \frac{1}{e^{\frac{hc}{\lambda k_B T}} – 1} $$
where $h$ is Planck’s constant, $c$ is the speed of light, $\lambda$ is the wavelength, and $k_B$ is Boltzmann’s constant. This allows the fire drone system to not just detect fire, but estimate its temperature and intensity.
Complementing thermal sensors are high-resolution visual (RGB) and multispectral cameras. RGB cameras provide contextual imagery for mapping and visual assessment. Multispectral sensors, capturing specific bandwidths like near-infrared (NIR), are crucial for assessing vegetation health and moisture content pre-fire, a key factor in fuel load modeling. For communication support, a fire drone can act as a temporary communications relay, carrying a pod to extend radio and data network coverage for ground teams in terrain-blocked areas. The most direct intervention payloads are fire suppression systems, ranging from dropped fire retardant balls to integrated liquid discharge systems for direct attack on small fires or creating firebreaks.
| Payload Type | Data/Output | Primary Application Phase | Key Metric/Formula |
|---|---|---|---|
| Thermal Imaging Camera | Heat signature maps, temperature gradients, hotspot GPS coordinates. | Detection, Active Fire Monitoring, Post-Fire Mop-up. | Temperature Resolution (e.g., <50 mK), Spatial Resolution (e.g., 640×512 pixels). Fire Front Progression Rate: $v_f = \Delta x / \Delta t$. |
| High-Resolution RGB Camera | Geotagged orthomosaics, high-definition video streams. | Pre-fire mapping, Damage Assessment, Public Information. | Ground Sample Distance (GSD): $GSD = \frac{sensor\ width}{focal\ length} \times altitude$. Burned Area: $A_{burn} = \sum_{i=1}^{n} PixelArea_i$. |
| Multispectral Sensor | Vegetation Indices (e.g., NDVI), moisture stress maps. | Pre-fire Risk Assessment, Post-fire Recovery Monitoring. | Normalized Difference Vegetation Index: $NDVI = \frac{NIR – Red}{NIR + Red}$. Lower NDVI indicates drier, more flammable fuel. |
| Communication Relay Pod | Extended radio/data network coverage radius. | Active Fire Fighting, Search and Rescue. | Coverage Area: $A_{cov} \approx \pi \cdot (h \cdot \tan(\theta))^2$, where $h$ is drone altitude and $\theta$ is antenna beamwidth. |
| Fire Suppression Module | Deployed retardant or water. | Initial Attack, Mop-up, Firebreak Creation. | Payload Mass: $m_{payload}$. Drop Precision Error: $\sigma_{drop} = f(wind\ speed,\ altitude,\ GNC\ accuracy)$. |
The operational lifecycle of forest fire management with fire drone systems can be broken down into four critical phases where their impact is profound.
1. Pre-Fire: Prevention, Patrol, and Risk Assessment. In this phase, the fire drone acts as a force multiplier for ground teams. Regularly scheduled autonomous patrols along predefined routes can monitor for illegal activities (campfires, smoking), assess vegetation health, and map fuel loads. Multispectral data helps in calculating drought indices and identifying high-risk zones. The drone’s ability to access remote and rugged terrain means patrols are more thorough and less labor-intensive. The real-time video feed allows a single operator to surveil a vast area, making the fire drone an indispensable tool for proactive prevention.
2. Active Fire: Detection, Intelligence, and Suppression Support. This is where the fire drone provides its most immediate value. Upon a fire report, a fire drone can be airborne in minutes, arriving at the scene ahead of ground crews. It provides the incident commander with a real-time, bird’s-eye view of the situation. Key intelligence delivered includes:
- Fire Perimeter and Direction: Mapping the exact fire edge and calculating its rate of spread (ROS). The ROS can be modeled using empirical formulas like the Rothermel model, which considers fuel, slope, and wind: $R = I_R \cdot \xi \cdot (1 + \phi_w + \phi_s)$, where $R$ is rate of spread, $I_R$ is reaction intensity, $\xi$ is propagating flux ratio, and $\phi_w$, $\phi_s$ are wind and slope factors.
- Spot Fire Detection: Thermal sensors can identify new ignitions ahead of the main fire front.
- Safe Route Identification: Visual and thermal data can help identify safe access and egress routes for ground personnel.
- Structural Threat Assessment: Assessing the threat to cabins, infrastructure, or villages.
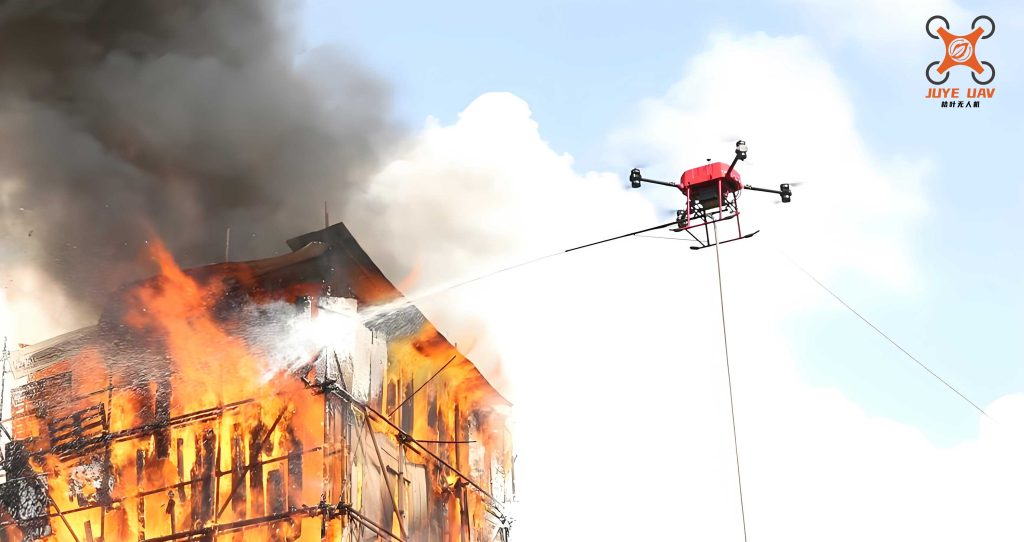
Furthermore, the fire drone can directly support suppression. It can accurately drop incendiary spheres for backburning operations or deliver water/retardant on small flare-ups or to cool hotspots threatening fireline construction. This direct intervention capability makes a fire drone a key asset in the initial attack phase, crucial for containing fires while they are still small.
3. Post-Fire: Mop-up and Damage Assessment. After the main fire front has passed, dangerous hotspots and smoldering roots (holdover fires) can persist for days. A fire drone equipped with a thermal camera is the perfect tool for efficiently scanning the entire burn area. It can pinpoint these residual heat sources with GPS accuracy, directing mop-up crews precisely and preventing re-ignition. For damage assessment, drones perform rapid photogrammetric surveys, creating highly accurate 2D orthomosaics and 3D models of the burn scar. This allows for precise calculation of the burned area, assessment of tree mortality, and planning of rehabilitation efforts. The data collection speed and accuracy of a fire drone in this phase are orders of magnitude greater than ground-based surveys.
4. Investigation and Analysis. Following a fire, determining the point of origin and cause is essential. A fire drone can document the scene comprehensively from the air before ground disturbance occurs. The high-resolution imagery and 3D models can reveal burn patterns that point to the origin. This aerial perspective provides investigators with critical context that is impossible to gain from the ground alone.
Despite their transformative potential, the widespread operational deployment of fire drone systems faces several intertwined technical and logistical challenges. A primary constraint is endurance, particularly for electric multi-rotor systems commonly used for close-in work. The flight time $t$ is fundamentally limited by the battery’s energy density $E_{bat}$ (Wh/kg), the drone’s mass $m$, and its power consumption $P$ (W):
$$ t \approx \frac{E_{bat} \cdot m_{bat}}{P} $$
where $m_{bat}$ is the mass of the battery pack. Advancements in battery technology (e.g., solid-state) and hybrid power systems are critical to breaking this barrier. Payload capacity is another limit; carrying heavy thermal cameras, communication gear, and suppression systems reduces flight time. This leads to a classic optimization problem: maximize the utility function $U$ (a combination of sensor performance, flight time, and suppression capacity) subject to weight $W$, power $P$, and cost $C$ constraints:
$$ \max\ U(Sensor,\ Endurance,\ Payload) $$
$$ \text{subject to: } W_{total} \leq W_{max}, P_{required} \leq P_{available}, Cost \leq Budget $$
Operational challenges include regulatory airspace integration, ensuring robust command and control links in remote, mountainous regions, and developing standardized training and procedures for fire drone operators working alongside manned aviation and ground crews. The “sense-and-avoid” capability for autonomous navigation in complex, smoky environments remains a significant research area in artificial intelligence and sensor fusion.
The future of fire drone technology is incredibly promising, driven by convergence with other cutting-edge fields. We are moving towards autonomous swarms, where multiple fire drone units collaborate. One drone could map the perimeter, another monitor atmospheric conditions, and a third perform targeted suppression, all coordinated by an AI “hive mind.” This can be modeled as a multi-agent coverage problem, optimizing the positions of $n$ drones to maximize the monitored area $A_{total}$ or minimize the time to scan an area:
$$ \max\ A_{total} = \bigcup_{i=1}^{n} A_{sensor}(drone_i) $$
$$ \text{or} \quad \min\ T_{scan} = f(n, v, sensor\ footprint, area\ geometry) $$
Enhanced AI and machine learning will enable real-time fire behavior prediction directly on the drone’s video feed, automated hotspot detection, and identification of people or assets at risk. Integration with other data layers—satellite imagery, weather forecasts, historical fire data—will create a common operational picture that is dynamically updated by fire drone fleets. Ultimately, the vision is a fully integrated, intelligent fire management system where fire drone networks serve as the responsive, data-collecting, and intervening nervous system, working seamlessly with satellites, manned assets, and ground teams to predict, detect, and extinguish wildfires with unprecedented speed and efficiency, while keeping human responders out of harm’s way. The fire drone has ceased to be just a tool; it is becoming the cornerstone of next-generation wildland firefighting strategy.