
In modern power systems, transmission lines are critical components whose reliability directly impacts grid stability. Traditional inspection methods, relying on manual labor, face significant challenges such as low efficiency, high safety risks, subjective assessments, and inadequate coverage, especially in expansive or rugged terrains. With the rapid advancement of unmanned aerial vehicle (UAV) technology and artificial intelligence, collaborative UAV drone systems offer a transformative solution for intelligent inspection and fault diagnosis. This paper presents a comprehensive study on a UAV drone-based collaborative system designed to enhance the automation and intelligence of transmission line inspections. We develop a multi-drone task allocation and path planning framework, integrate deep learning models for defect recognition, and validate the system through experiments. Our approach aims to significantly improve inspection efficiency, fault diagnosis accuracy, and operational safety while reducing costs. The research contributes to the development of smart grid infrastructure by providing a scalable and robust technological foundation.
The integration of UAV drones into power line inspections addresses long-standing limitations. UAV drones enable rapid data collection over large areas, access to hard-to-reach locations, and real-time monitoring capabilities. However, single-drone operations often suffer from limited endurance, computational constraints, and incomplete coverage. To overcome these, we propose a collaborative system where multiple UAV drones work in unison, leveraging synergies in task distribution, data fusion, and adaptive control. This paper details the architecture, algorithms, and applications of our system, emphasizing practical implementation and performance metrics. By incorporating advanced communication networks, sensor fusion, and machine learning, our system represents a leap forward in predictive maintenance and grid resilience. We begin by outlining the system design, followed by algorithmic innovations, experimental validation, and future directions.
System Architecture Design for Collaborative UAV Drone Inspection
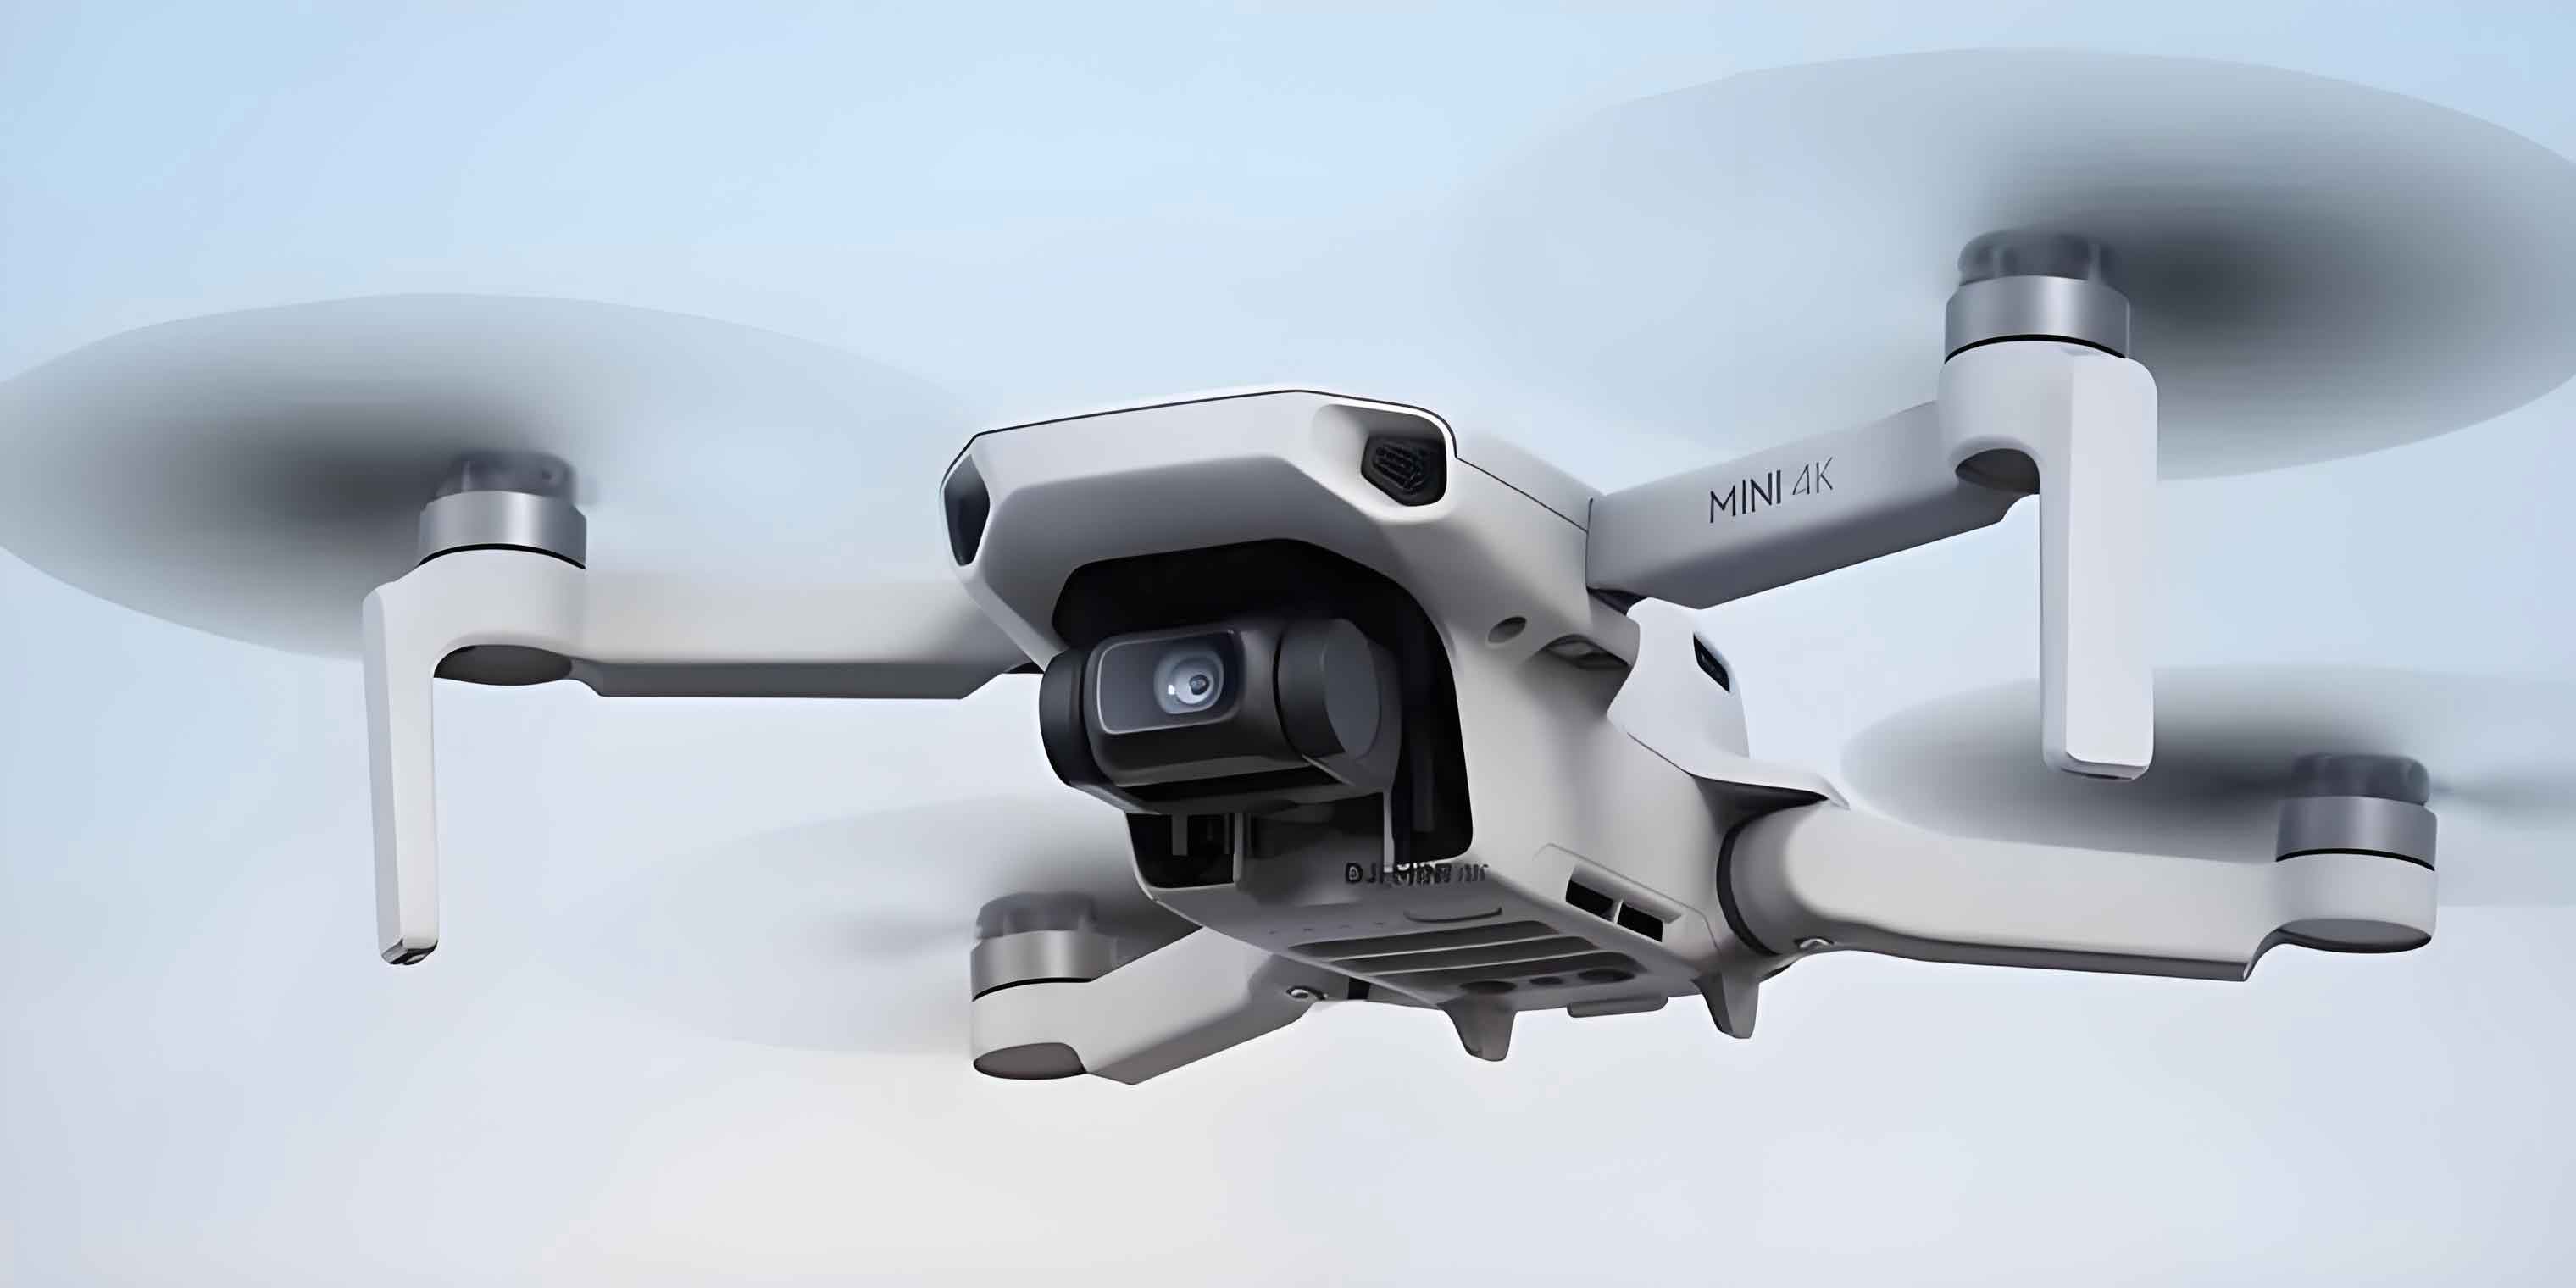
The collaborative UAV drone inspection system is built on a holistic framework comprising hardware platforms, communication networks, and software systems. This integrated design ensures seamless operation from task initiation to data analysis. The hardware platform features a hybrid fleet of multi-rotor and fixed-wing UAV drones, each equipped with specialized sensors for diverse inspection needs. Multi-rotor UAV drones are ideal for close-range, high-detail imaging of components like insulators, towers, and fittings, while fixed-wing UAV drones cover vast corridors quickly, enabling broad surveys and 3D modeling. Sensors include visible-light cameras, infrared thermal imagers, and LiDAR, all chosen for their precision and reliability in electrical environments. For instance, visible-light cameras capture surface defects, infrared sensors detect overheating anomalies, and LiDAR generates precise point clouds for structural analysis. The UAV drones are powered by lithium-sulfur batteries with solar assistance, extending flight times to over 90 minutes for multi-rotors and 180 minutes for fixed-wing models, thus supporting prolonged missions.
Communication is vital for coordinating UAV drone fleets. Our system employs a multi-level redundant network combining 5G, fiber optics, and BeiDou short messaging. 5G provides high bandwidth and low latency for real-time transmission of high-definition video and LiDAR data; fiber ensures stable links between fixed nodes and control centers; and BeiDou handles command relay in remote areas with poor coverage, achieving response times under 3 seconds. To mitigate electromagnetic interference common in power grids, we use WAPI 2.0 protocols with dynamic frequency hopping, reducing bit error rates below $10^{-8}$ in extreme environments like 500 kV substations. This robust network guarantees reliable data flow and control, enabling real-time adjustments during inspections.
The software system adopts a microservices architecture, encapsulating task management, data handling, and intelligent analysis. Task management services utilize GIS-based mapping for route planning, conflict resolution, and dynamic adaptation to field conditions. Data management services cleanse, annotate, and store heterogeneous data from UAV drones, while analysis services leverage deep learning libraries for defect detection and fault classification. The platform supports web and mobile interfaces for visualization and reporting, with algorithms implemented in TensorFlow and PyTorch. Containerization allows scalable deployment, ensuring high concurrency and stability. Table 1 summarizes the hardware configuration, highlighting how each component contributes to system performance.
| Device Type | Technical Parameters | Application Scenario |
|---|---|---|
| Multi-rotor UAV Drone | Endurance: 90 min, Payload: 2 kg, Wind Resistance: Level 6 | Fine inspection of towers and insulators |
| Fixed-wing UAV Drone | Endurance: 180 min, Range: 60 km, Speed: 72 km/h | Rapid corridor surveying |
| Visible-light Camera | Resolution: 1920×1080, Optical Zoom: 20× | Surface defect identification |
| Infrared Thermal Imager | Resolution: 640×512, Temperature Range: -20 to 150 °C | Hotspot detection |
| LiDAR | Scan Frequency: 100 Hz, Accuracy: 3 cm | 3D modeling and vegetation analysis |
Collaborative Control and Path Planning Algorithms
Effective coordination of UAV drone fleets requires sophisticated task allocation and path planning. We formulate a multi-drone task allocation model that maximizes coverage and minimizes energy consumption. The inspection area is partitioned into subregions based on UAV drone capabilities, sensor ranges, and priority constraints. An improved genetic algorithm solves for optimal assignments, incorporating time-balancing factors and risk weights to ensure fairness and safety. The objective function is defined as:
$$ \min Z = \sum_{i=1}^{n} \sum_{j=1}^{m} C_{ij} X_{ij} + \alpha \max(T_i) + \beta \sum_{i=1}^{n} E_i $$
where $C_{ij}$ is the cost for UAV drone $i$ to execute task $j$, $X_{ij}$ is the allocation variable (1 if assigned, 0 otherwise), $T_i$ is the task time for UAV drone $i$, $E_i$ is its energy consumption, and $\alpha$ and $\beta$ are weighting coefficients that tune the trade-off between time efficiency and energy usage. This model accounts for real-world variables like wind conditions and battery degradation, which are critical for long-duration missions. The genetic algorithm iteratively refines solutions through selection, crossover, and mutation, converging to a distribution that reduces total inspection time by up to 40% compared to sequential single-drone operations.
Path planning integrates geographical data and obstacle avoidance to generate safe, efficient routes. We combine A* algorithm for global coarse planning with ant colony optimization for detailed trajectory smoothing. The A* algorithm quickly identifies high-level paths around major obstacles, while ant colony optimization refines these to minimize travel distance and ensure comprehensive coverage. Constraints include UAV drone dynamics (e.g., turn radius, speed limits) and sensor field-of-view requirements to guarantee image quality. For dynamic obstacles or weather changes, a real-time replanning module uses sensor feedback to adjust paths on-the-fly. The path cost function is:
$$ P = \int_{0}^{L} \left( w_1 \cdot d(l) + w_2 \cdot \kappa(l) + w_3 \cdot \rho(l) \right) dl $$
where $d(l)$ is the distance traveled, $\kappa(l)$ is the curvature (to promote smooth turns), $\rho(l)$ is the risk density along the path, and $w_1$, $w_2$, $w_3$ are weights. Simulation results show that this approach reduces redundant coverage by 25% and increases effective data acquisition rates.
To address endurance limitations, we deploy a network of preset takeoff and landing points along inspection routes. UAV drones continuously monitor their remaining battery and location, transmitting data to the ground control platform. Algorithms dynamically compute whether a UAV drone can safely reach the next task point or must divert to the nearest charging station. This enables relay-style operations, where multiple UAV drones seamlessly hand off tasks, extending effective range and enabling continuous inspection of long lines without human intervention. Such strategies are pivotal for operations in remote or hazardous terrains.
Collaborative control employs a master-slave distributed architecture. One UAV drone acts as a master node, coordinating task distribution and conflict resolution, while others follow commands for autonomous flight and data capture. The master node aggregates status updates via the communication network and adjusts plans as needed. Fault tolerance is embedded: if the master fails, a new leader is elected automatically using consensus protocols. Control modules include formation keeping, collision avoidance, and shape transformation, all implemented with PID controllers and model predictive control. Experiments confirm that this strategy maintains system stability even with communication delays up to 2 seconds or node failures, ensuring robust performance in field conditions.
Fault Diagnosis and Intelligent Recognition Models
Data acquired by UAV drones undergoes preprocessing to enhance analysis accuracy. Raw images often suffer from uneven lighting, blur, and perspective distortions. Our preprocessing pipeline includes grayscaling, histogram equalization, median filtering, and geometric correction. Grayscaling reduces computational load, histogram equalization improves contrast, median filtering removes noise, and geometric correction aligns images based on feature matching. For specific components like insulators or fittings, we apply image segmentation (e.g., using Otsu’s method or edge detection) to isolate regions of interest. Metrics show that preprocessing boosts peak signal-to-noise ratio (PSNR) by 15 dB and structural similarity index (SSIM) by 0.3, laying a strong foundation for subsequent analysis.
Defect recognition leverages deep learning models, specifically a fusion of Faster R-CNN and U-Net architectures. Faster R-CNN detects and localizes components (e.g., insulators, dampers, spacers), while U-Net performs pixel-wise segmentation of defects such as cracks, corrosion, or breakages. The model is trained on annotated datasets comprising thousands of images from UAV drone inspections. We optimize anchor box sizes and network parameters for small objects common in power line imagery, achieving high precision. The loss function for training combines classification and segmentation losses:
$$ L = \lambda_{cls} L_{cls} + \lambda_{reg} L_{reg} + \lambda_{seg} L_{seg} $$
where $L_{cls}$ is the cross-entropy loss for object classification, $L_{reg}$ is the smooth L1 loss for bounding box regression, $L_{seg}$ is the dice loss for segmentation, and $\lambda$ terms balance contributions. Our model achieves mean average precision (mAP) of 0.95 on test sets, outperforming traditional methods by over 20%.
To handle the massive data influx from UAV drone fleets, we adopt an edge-cloud collaborative processing framework. Onboard lightweight AI processors run pruned neural networks for real-time preliminary identification, filtering out irrelevant images and transmitting only suspicious data. Edge nodes with greater compute power perform finer analysis and generate initial reports, while the cloud aggregates all data for deep mining, trend analysis, and model retraining. This hierarchy reduces bandwidth requirements by 70% and enables offline operation in areas with poor connectivity, all while maintaining high accuracy. For instance, in mountainous regions, UAV drones can store processed data locally and sync when network access resumes.
Fault diagnosis integrates multi-source data fusion, combining image features, infrared temperatures, and LiDAR point clouds. The process extracts defect features from images, correlates them with thermal anomalies (e.g., temperatures exceeding thresholds), and assesses structural risks from point cloud deviations (e.g., sagging conductors or tower tilts). A Bayesian network models fault probabilities:
$$ P(F | D) = \frac{P(D | F) P(F)}{P(D)} $$
where $P(F | D)$ is the posterior probability of fault $F$ given data $D$, $P(D | F)$ is the likelihood, and $P(F)$ is the prior. Early warning systems use time-series analysis to track defect evolution, predicting remaining useful life and failure risks. In practice, this approach identifies common faults like insulator flashover, conductor strand breakage, and connector overheating with a false alarm rate below 5%. Case studies, such as a 110 kV substation inspection, demonstrate how fusion of laser-measured spacing changes and infrared data enabled a 72-hour advance warning of contact degradation, preventing equipment damage.
Experimental Analysis and Application Validation
We conducted extensive field experiments to evaluate system performance. A 100 km segment of 110 kV transmission lines, spanning mountains, plains, and rivers, served as the testbed. Five UAV drones—three multi-rotors and two fixed-wing—were deployed in a collaborative fleet. Over 30 days, they collected 12,500 visible-light images, 8,500 infrared images, and 350 km of LiDAR point cloud data. Professional engineers labeled defects into 12 categories (e.g., insulator cracks, foreign objects, corrosion) to create a benchmark dataset. We compared three inspection modes: traditional manual, single-drone, and collaborative UAV drone systems, measuring efficiency, cost, accuracy, and data completeness.
Results, summarized in Table 2, reveal substantial improvements. The collaborative UAV drone system achieved an inspection efficiency of 80 km per day, eight times faster than manual methods (10 km/day) and nearly double that of single-drone operations (45 km/day). Defect recognition accuracy reached 95.2%, significantly higher than manual (65.2%) and single-drone (88.5%) approaches. Costs per kilometer dropped to $50, compared to $150 for manual and $80 for single-drone, due to reduced labor and optimized resource use. Data completeness—the percentage of line segments thoroughly inspected—hit 98%, ensuring near-total coverage. UAV drones detected minute defects, such as 2 mm conductor strand breaks and 0.5 mm insulator cracks, with thermal accuracy within 1°C. The fusion of infrared and visible-light data boosted electrical fault detection rates by 30%, highlighting the value of multi-sensor integration.
| Performance Metric | Manual Inspection | Single-Drone Inspection | Collaborative UAV Drone Inspection |
|---|---|---|---|
| Inspection Efficiency (km/day) | 10 | 45 | 80 |
| Defect Recognition Accuracy (%) | 65.2 | 88.5 | 95.2 |
| Average Cost per Kilometer ($) | 150 | 80 | 50 |
| Data Completeness (%) | 75 | 85 | 98 |
In real-world applications, the system has been adopted by several provincial grid companies, identifying 35 potential faults—including broken strands, insulator damage, and overheated joints—that were missed by routine checks. These successes have reduced outage times by an estimated 15% and lowered annual maintenance expenses by 20%. However, challenges persist, such as maintaining stability in adverse weather (e.g., strong winds or heavy rain), ensuring real-time processing of big data streams, and navigating regulatory constraints on UAV drone flights. Future work will focus on enhancing algorithm generalization to more equipment types and fault modes, improving system integration, and developing fully autonomous inspection cycles. We also plan to incorporate advanced sensors like hyperspectral cameras for material degradation analysis.
Conclusion
This research systematically explores intelligent inspection and fault diagnosis technology for transmission lines using collaborative UAV drones. We have developed a comprehensive framework encompassing hardware architecture, communication networks, software systems, and advanced algorithms. The multi-drone task allocation and path planning models optimize coverage and resource utilization, while deep learning-based recognition and multi-source data fusion enable accurate fault diagnosis. Experimental validation confirms that our system dramatically improves inspection efficiency, diagnostic precision, and cost-effectiveness, while mitigating safety risks associated with manual methods. Key innovations include the distributed collaborative control scheme, edge-cloud computing synergy, and robust communication protocols tailored for power grid environments.
The practical deployment of UAV drone fleets in grid inspections underscores the technology’s transformative potential. By enabling rapid, detailed, and continuous monitoring, UAV drones support predictive maintenance strategies that enhance grid reliability and resilience. Looking ahead, we will pursue algorithm lightweighting for real-time onboard processing, adaptability to extreme environmental conditions, and integration with digital twin platforms for simulation and planning. These efforts aim to further automate inspection processes, reduce operational dependencies, and scale the system for global smart grid initiatives. Collaborative UAV drone systems represent a cornerstone of future power infrastructure management, driving forward the intelligence and sustainability of energy networks.