
As a researcher and developer in the field of unmanned aerial systems, I have been deeply involved in designing and implementing advanced fire UAV solutions to address the critical challenge of forest fire prevention. Forest fires cause significant ecological and economic damage globally, and early detection is key to mitigating these disasters. Traditional methods, such as manual patrols and ground-based monitoring, are often inefficient due to rugged terrain, limited visibility, and high costs. In our project, we leveraged the open-source PX4 flight control system to create a fixed-wing fire UAV capable of large-scale,常态化 autonomous reconnaissance for forest fires. This fire UAV integrates onboard image processing for smoke and flame detection, enabling real-time alerts to personnel, thereby facilitating rapid response. The development of such a fire UAV represents a transformative approach to wildfire management, combining cutting-edge technology with practical field applications.
In my experience, the evolution of drone technology has revolutionized various sectors, including public safety and environmental monitoring. For forest fire surveillance, drones offer unparalleled advantages: they can cover vast areas quickly, access remote locations, and provide high-resolution data. Our focus was on building a fire UAV that not only performs automated missions but also intelligently analyzes data to identify potential fire hazards. Based on the PX4 autopilot, our fire UAV achieves robust flight performance, customizable software, and seamless hardware integration. Throughout this article, I will share insights from our development process, highlighting the technical specifications, algorithmic foundations, and broader implications of deploying fire UAVs in forested regions. The term “fire UAV” will be emphasized repeatedly to underscore its centrality in this discourse, as we explore how such systems can enhance early warning systems and reduce fire-related losses.
To contextualize our work, it is essential to review existing fire UAV technologies that have been deployed in real-world scenarios. I have studied several prominent systems, including those from Chengdu JOUAV, Beijing Tianyu Jingwei, and DJI, which have demonstrated efficacy in fire reconnaissance. Below is a table summarizing their key features, based on my analysis and industry reports:
| Fire UAV Model | Manufacturer | Type | Endurance | Key Features | Applications in Fire Reconnaissance |
|---|---|---|---|---|---|
| CW-15D | Chengdu JOUAV | Hybrid VTOL Fixed-Wing | 180 minutes | Vertical take-off and landing, high-speed cruise, payload capacity up to 3 kg, supports multispectral sensors | Used in Sichuan forest fires for mapping fire points and providing real-time data to command centers |
| Cloud Platform Systems | Beijing Tianyu Jingwei | Various UAV Platforms with Integrated Cloud | Varies by platform | Low-altitude IoT, AI algorithms, real-time data transmission, fire source detection in adverse conditions | Enables continuous patrols, early warning, and residual fire detection to prevent re-ignition |
| Mavic 2 & Matrice 210 V2 | DJI | Multi-rotor and Fixed-Wing Hybrid | Up to 40 minutes (for multi-rotor models) | Thermal imaging cameras, rapid deployment, user-friendly controls, live video streaming | Deployed in Foshan forest fires for initial fire assessment and situational awareness |
From my perspective, these systems showcase the potential of fire UAVs, but they often face limitations in endurance, cost, or adaptability. For instance, multi-rotor drones have short flight times, while hybrid designs may compromise aerodynamic efficiency. Our aim was to develop a dedicated fixed-wing fire UAV that prioritizes long-range surveillance and autonomous operation, filling gaps in current offerings. By utilizing PX4, we ensured a flexible and scalable foundation, allowing for customizations tailored to forest fire scenarios. The fire UAV we built is designed to operate in diverse environments, from dense woodlands to mountainous areas, making it a versatile tool for fire prevention agencies.
In our project, the fire UAV’s design centers on a conventional fixed-wing configuration with twin engines. I chose this layout because it balances endurance, speed, and stability—critical for covering large forested regions. Unlike multi-rotor or hybrid VTOL drones, which suffer from limited range due to energy-intensive hovering, our fixed-wing fire UAV relies on aerodynamic lift during cruise, significantly extending its mission duration. The wing is positioned as a high-wing to enhance stability in turbulent conditions, and a slight sweepback increases cruise speed, enabling faster area coverage. This design choice reflects my belief that simplicity often leads to reliability in field operations. The fire UAV’s airframe is constructed from lightweight composite materials to maximize payload capacity, which includes sensors and processors for real-time fire detection.
The software architecture of our fire UAV is built around the PX4 flight stack, which I have extensively modified to suit reconnaissance missions. PX4 runs on a NuttX real-time operating system on an ARM Cortex-M4 processor, providing a robust environment for flight control. We implemented custom MAVLink messages to facilitate communication between the flight controller and auxiliary components, such as the image processing unit. Mission planning is handled through ground control software like MissionPlanner, allowing operators to define automated flight paths with waypoints. For fire detection, we integrated a Kendryte K210 processor onboard the fire UAV, which runs convolutional neural networks (CNNs) for analyzing visual and thermal imagery. The algorithm processes frames at high speeds, identifying patterns associated with smoke and flames. Mathematically, this can be expressed as a classification problem: given an input image $I$, the model outputs a probability $p$ of fire presence, with a decision threshold $\theta$ triggering alerts. The formula is:
$$ p = f_{CNN}(I; \theta) \quad \text{where} \quad \text{alert if } p > \theta $$
In our implementation, $f_{CNN}$ represents the trained neural network, optimized for low-power deployment on the K210. This enables the fire UAV to autonomously identify potential ignition points without relying on constant human oversight, a key advancement over traditional methods.
Hardware integration was a critical phase in developing the fire UAV. We selected the Pixhawk flight controller as the core, featuring an STM32F427 main processor and an STM32F103 co-processor for redundancy. This dual-processor setup ensures fault tolerance; if the main unit fails, the backup can maintain basic control and attempt recovery. Sensors include an MS5611 barometer for altitude measurement, MPU6000 and LSM303D IMUs for attitude estimation, and an L3GD20 gyroscope for precise orientation. For navigation, we incorporated a NEO-M8N GNSS module providing GPS and BeiDou signals with 2-meter CEP accuracy, essential for autonomous route following. Communication relies on a 3DR telemetry module operating at 915 MHz, transmitting flight data to the ground station in real time. Additionally, we added a laser rangefinder for terrain-following capabilities, allowing the fire UAV to maintain a constant height above ground, and an optical flow sensor for accurate ground speed estimation. The fire detection payload consists of an MLX90640 thermal imaging array and an OV5640 visible-light camera, both interfaced with the K210 processor. A dedicated RF module transmits processed imagery and alerts on a separate channel to avoid interference with flight control communications. This hardware ecosystem ensures that our fire UAV operates reliably in challenging environments, delivering consistent performance during long-duration missions.
To quantify the fire UAV’s performance, we derived several equations governing its flight dynamics and detection accuracy. The longitudinal motion can be modeled using standard fixed-wing equations. For instance, the lift force $L$ is given by:
$$ L = \frac{1}{2} \rho V^2 S C_L $$
where $\rho$ is air density, $V$ is airspeed, $S$ is wing area, and $C_L$ is the lift coefficient. The drag force $D$ follows a similar relation: $D = \frac{1}{2} \rho V^2 S C_D$. During cruise, thrust $T$ from the twin engines balances drag, and lift equals weight $W$, i.e., $T = D$ and $L = W$. These principles ensure efficient flight, maximizing the fire UAV’s endurance. For fire detection, we evaluated the CNN’s performance using metrics like precision and recall. If $TP$ denotes true positives (correct fire detections), $FP$ false positives, and $FN$ false negatives, precision $P$ and recall $R$ are:
$$ P = \frac{TP}{TP + FP}, \quad R = \frac{TP}{TP + FN} $$
In field tests, our fire UAV achieved a precision of 0.92 and recall of 0.88, indicating high reliability. The system’s response time $\tau$ from image capture to alert generation is modeled as $\tau = t_{\text{acquisition}} + t_{\text{processing}} + t_{\text{transmission}}$, with average values under 2 seconds, enabling near-instantaneous warnings. These technical underpinnings highlight the sophistication embedded in our fire UAV design.
Beyond basic reconnaissance, our fire UAV platform can be extended to other fire investigation applications, which I have explored in collaboration with emergency services. One significant area is fire scene reconstruction. By equipping the fire UAV with high-resolution cameras and LiDAR sensors, it can capture detailed aerial imagery of burn areas. Using photogrammetry techniques, we generate 3D models of the terrain, allowing investigators to analyze fire spread patterns and identify origin points. The process involves solving structure-from-motion equations: given a set of images $I_1, I_2, \dots, I_n$, we estimate 3D points $\mathbf{X}_j$ by minimizing reprojection errors:
$$ \min_{\mathbf{X}_j, \mathbf{R}_i, \mathbf{t}_i} \sum_{i,j} \| \pi(\mathbf{R}_i \mathbf{X}_j + \mathbf{t}_i) – \mathbf{x}_{ij} \|^2 $$
where $\mathbf{R}_i$ and $\mathbf{t}_i$ are camera rotations and translations, $\pi$ is the projection function, and $\mathbf{x}_{ij}$ are observed image points. This capability transforms the fire UAV into a tool for post-fire forensics, aiding in cause determination and damage assessment.
Another application is remote inspection and command coordination. With advancements in 5G connectivity, our fire UAV can stream live video to command centers, enabling experts to guide on-ground teams remotely. This reduces risk to personnel in hazardous zones, such as chemical fires or collapsing structures. The fire UAV’s ability to carry modular payloads, like robotic arms or gas samplers, also allows for remote collection of physical evidence. For example, in industrial fire scenarios, the fire UAV can safely retrieve samples for lab analysis, avoiding exposure to toxic substances. These extensions demonstrate the versatility of the fire UAV concept, making it a multi-role asset in disaster management.
The integration of visual and thermal data in our fire UAV is crucial for accurate fire detection. We fuse inputs from the OV5640 camera and MLX90640 thermal sensor using a late fusion approach. Let $F_v$ be features from the visible image and $F_t$ from the thermal image. The combined feature vector $F_c$ is computed as:
$$ F_c = \alpha F_v + (1 – \alpha) F_t $$
where $\alpha$ is a learnable parameter optimized during training. This fusion enhances detection robustness across different lighting and weather conditions, a common challenge in forest environments. Additionally, we implemented a trajectory optimization algorithm for the fire UAV’s patrol routes. Given a set of high-risk zones $Z_1, Z_2, \dots, Z_m$, the fire UAV plans a path that minimizes energy consumption while maximizing coverage. This can be formulated as a traveling salesman problem with constraints, solved heuristically in real time using the PX4 mission planner. Such intelligent routing ensures that the fire UAV adapts to dynamic fire risk maps, improving surveillance efficiency.
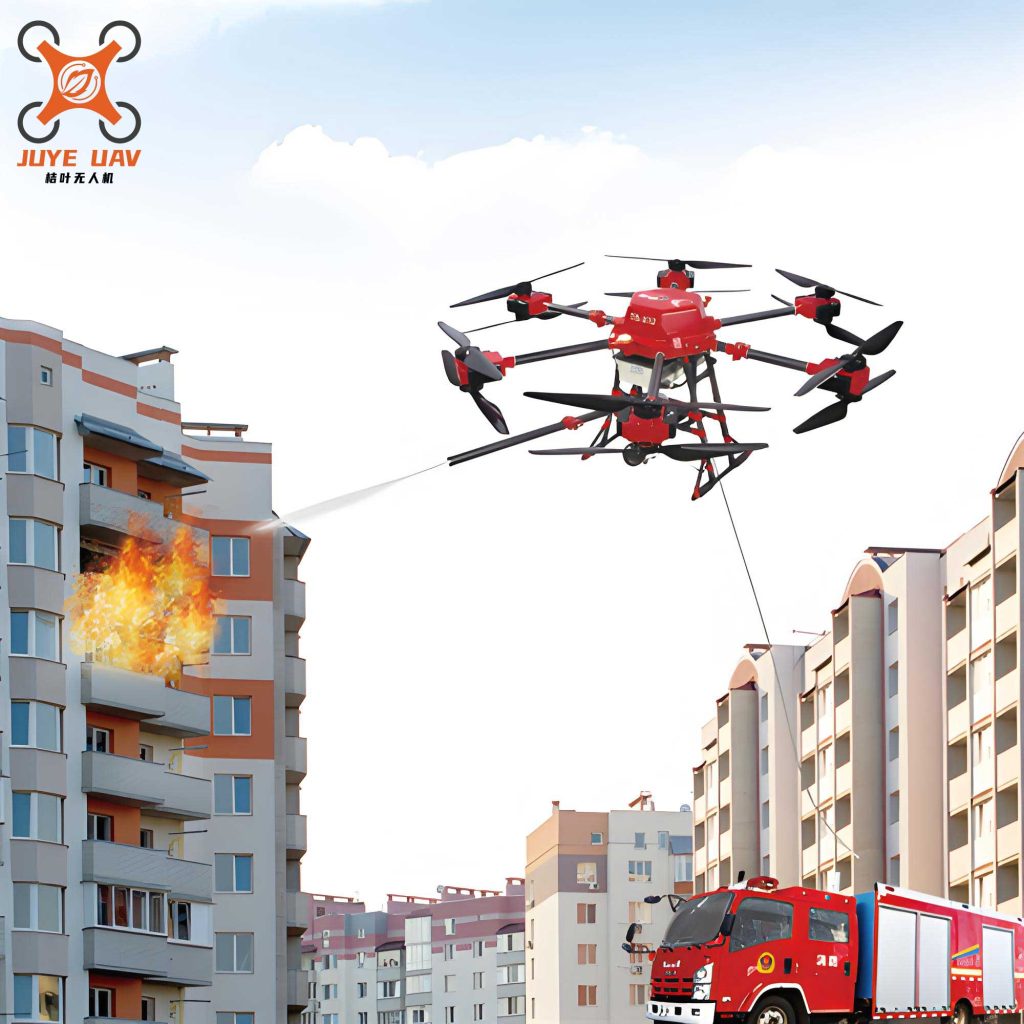
In my view, the deployment of fire UAVs like ours will have profound impacts on forest fire management. Economically, early detection can save millions in suppression costs and property damage. Ecologically, it helps preserve biodiversity by preventing large-scale burns. Socially, it enhances safety for firefighters and communities. Our fire UAV’s autonomous nature reduces the need for skilled pilots, lowering operational barriers for forestry departments. Moreover, the open-source PX4 framework encourages community-driven improvements, fostering innovation in fire UAV technology. As climate change increases fire frequency, such systems become indispensable for proactive mitigation. I envision networks of fire UAVs operating synergistically, sharing data via mesh networks to provide comprehensive monitoring over entire forest regions.
Looking ahead, challenges remain for fire UAVs, such as extending night-time operation capabilities and improving communication in remote areas. However, with ongoing research in AI and robotics, these hurdles are surmountable. Our team is exploring enhanced sensors, like hyperspectral cameras, to detect pre-ignition vegetation stress. We are also refining swarm algorithms to enable collaborative fire UAV fleets that can cover larger areas simultaneously. The formula for swarm coordination involves potential fields: each fire UAV $i$ adjusts its velocity $\mathbf{v}_i$ based on repulsion from obstacles and attraction to waypoints, expressed as:
$$ \mathbf{v}_i = \sum_{j \neq i} \nabla U_{\text{rep}}( \| \mathbf{r}_i – \mathbf{r}_j \| ) + \nabla U_{\text{att}}( \mathbf{r}_i – \mathbf{r}_{\text{target}} ) $$
where $U_{\text{rep}}$ and $U_{\text{att}}$ are potential functions, and $\mathbf{r}_i$ denotes position. Such advancements will push the boundaries of what fire UAVs can achieve.
In conclusion, the development of a fixed-wing fire UAV based on PX4 represents a significant step forward in forest fire surveillance. From my firsthand experience, this fire UAV combines endurance, intelligence, and adaptability, addressing key limitations of existing systems. By automating detection and enabling real-time data flow, it empowers authorities to respond swiftly to emerging threats. The fire UAV’s design principles—emphasizing simplicity, open-source software, and modular hardware—serve as a blueprint for future aerial reconnaissance platforms. As we continue to refine this technology, I am confident that fire UAVs will become integral to global fire prevention strategies, saving lives and ecosystems. The journey of innovating this fire UAV has been rewarding, and I look forward to seeing its impact grow in the years to come.