
In my years of research and development in aerial robotics, I have focused on addressing critical environmental challenges, particularly forest fires, which cause significant economic and ecological damage globally. Traditional methods of fire surveillance, such as manual patrols and static cameras, are often inefficient due to difficult terrain, high costs, and slow response times. To overcome these limitations, I designed and implemented an autonomous fixed-wing drone system based on the open-source PX4 flight control stack, specifically tailored for large-scale,常态化 forest fire reconnaissance. This fire drone leverages advanced onboard processing for real-time smoke and flame detection, enabling early warning and rapid intervention. In this article, I will detail the design, functionality, and broader applications of this system, emphasizing how it transforms fire management through automation and intelligence.
The evolution of drone technology has revolutionized various industries, and fire surveillance is no exception. In my assessment, current commercial solutions, such as those from Chengdu纵横大鹏, Beijing天宇经纬, and Shenzhen大疆, demonstrate the potential of unmanned aerial vehicles (UAVs) in firefighting. For instance,复合式VTOL drones offer vertical take-off and landing capabilities, but they often suffer from reduced巡航效率 due to aerodynamic drag from多余旋翼. My approach prioritizes endurance and speed for wide-area coverage, leading to the choice of a conventional fixed-wing design. This fire drone is engineered to perform automated, long-duration missions, scanning vast forested regions with minimal human intervention. By integrating PX4’s robust flight control with custom image processing algorithms, the system can identify potential fire hotspots and alert operators in real-time, thereby preventing small ignitions from escalating into catastrophic wildfires.
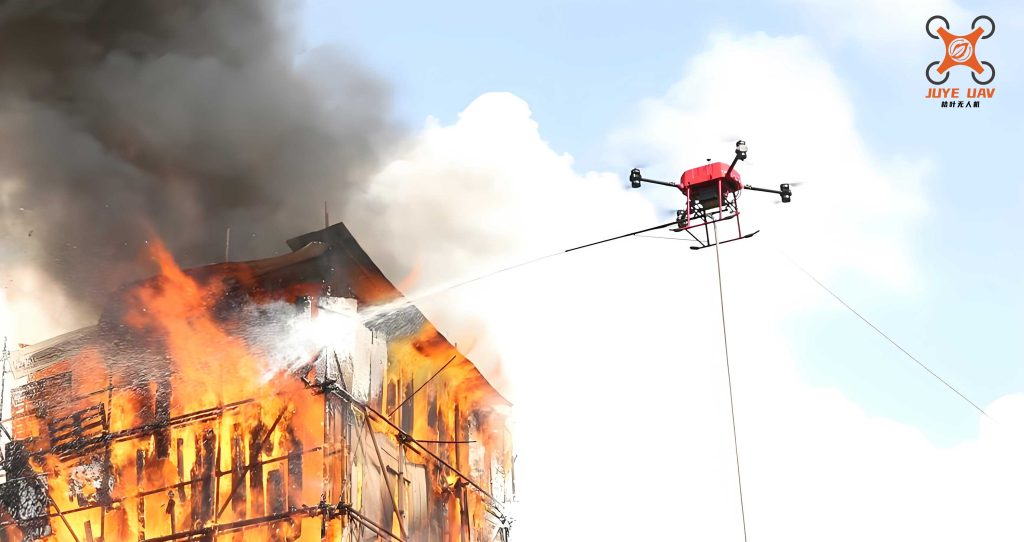
To understand the context, I analyzed several existing fire drone deployments. For example, in Sichuan’s forest fires, drones equipped with multispectral sensors provided critical火势mapping,但 their reliance on复合式designs limited flight time. Similarly, cloud-based platforms enable real-time data transmission, yet they depend on stable communication networks, which can be unreliable in remote areas. My system addresses these gaps by combining a fixed-wing platform for extended range with onboard AI processing to reduce bandwidth dependency. The core functionality of my fire drone includes automated route planning, terrain-following巡航, and intelligent hazard detection. Using weather and topographic data, the drone dynamically adjusts its flight path to focus on high-risk zones, increasing patrol frequency where fire probability is elevated. This proactive surveillance is facilitated by PX4’s mission planning capabilities, which I enhanced with custom algorithms for adaptive航点selection based on historical fire data and real-time sensor inputs.
The primary functions of this fire drone are multifaceted, aiming to create a comprehensive surveillance solution. First, it conducts large-scale autonomous reconnaissance, covering hundreds of square kilometers in a single mission. The onboard processor, a Kendryte K210, runs convolutional neural networks (CNNs) trained to detect smoke patterns and明火in visible-light images, as well as anomalous heat signatures from infrared data. When a potential fire is identified, the system immediately sends alerts to ground stations and mobile devices, along with geotagged imagery and sensor data. This allows firefighters to verify threats and mobilize resources swiftly. Additionally, the fire drone supports real-time telemetry streaming via 3DR telemetry modules, providing operators with live flight data, including altitude, speed, and battery status. To ensure accessibility, I designed the system for automated take-off and landing, reducing the skill barrier for personnel. The integration of these features enables a闭环workflow from detection to response, significantly shortening the time between ignition discovery and suppression行动.
In terms of technical implementation, my fire drone’s design revolves around three key aspects: airframe structure, software architecture, and hardware configuration. For the airframe, I opted for a twin-engine, high-wing conventional layout to maximize stability and巡航efficiency. Unlike multirotor or复合式VTOL drones, this fixed-wing design minimizes drag and weight, allowing for longer endurance at higher speeds. The wings are slightly swept back to enhance cruising performance, with a wingspan optimized for lift in various atmospheric conditions. This configuration enables the fire drone to operate in windy environments common in mountainous regions, ensuring reliable surveillance missions.
The software stack is built upon the PX4 autopilot ecosystem, which I extended to meet specific fire surveillance needs. PX4 runs on a NuttX real-time operating system, utilizing a uORB messaging system for inter-process communication. I modified the MAVLink protocol to incorporate custom messages for sensor data and alert signals, enabling seamless integration with the K210 processor. Mission planning is handled through ground control software like Mission Planner, where I developed scripts for automated航线generation based on risk assessments. The image processing pipeline involves real-time inference using pre-trained models; for instance, smoke detection is formulated as a binary classification problem with a confidence score threshold. The probability of fire presence \( P_{fire} \) can be expressed as:
$$ P_{fire} = \sigma(W \cdot X + b) $$
where \( \sigma \) is the sigmoid activation function, \( W \) represents the model weights, \( X \) is the input image feature vector, and \( b \) is the bias term. If \( P_{fire} > 0.8 \), an alert is triggered. For infrared analysis, the MLX90640 sensor outputs a temperature matrix \( T_{ij} \), and anomalies are detected when localized temperatures exceed ambient levels by a delta \( \Delta T \):
$$ \Delta T = \max(T_{ij}) – \overline{T} $$
where \( \overline{T} \) is the average temperature over a defined region. If \( \Delta T > 10^\circ C \), it flags a potential heat source. These algorithms run continuously during flight, ensuring no missed detections.
Hardwise, the fire drone’s core components are selected for reliability and performance. The flight controller is a Pixhawk board featuring an STM32F427 main processor and an STM32F103 co-processor, providing redundant control for safety. Key sensors include:
| Component | Model | Function | Specifications |
|---|---|---|---|
| Flight Controller | Pixhawk | Autonomous navigation | ARM Cortex-M4/M3, MPU6000, LSM303D |
| GPS Module | NEO-M8N | Positioning | 10 Hz update, 2m CEP accuracy |
| Telemetry | 3DR Radio | Data transmission | 915 MHz, up to 1 km range |
| Imaging Sensor | OV5640 | Visible-light camera | 5 MP, for smoke/flame detection |
| Thermal Sensor | MLX90640 | Infrared imaging | 32×24 pixel array, ±0.5°C accuracy |
| Processor | Kendryte K210 | Onboard AI | Dual-core RISC-V, CNN accelerator |
| Laser Rangefinder | SF30/F | Terrain following | 30m range, for altitude hold |
These components interface through dedicated ports on the Pixhawk, with the K210 communicating via a separate UART to avoid congestion on the flight control bus. Power is supplied by a high-capacity lithium-polymer battery, offering up to 120 minutes of flight time at a巡航speed of 70 km/h. The entire system is housed in a lightweight carbon fiber frame, balancing durability and weight for optimal performance. This hardware synergy allows the fire drone to operate autonomously in diverse environments, from dense forests to rugged hillsides.
Beyond basic surveillance, my fire drone technology extends into several advanced applications for fire investigation and management. One significant area is现场reconstruction. By equipping the drone with high-resolution cameras and LiDAR sensors, it can capture detailed aerial imagery post-fire. Using photogrammetry techniques, these images are processed to generate 3D models of the affected area. For example, the drone’s flight path can be programmed to perform grid patterns over the火场, collecting overlapping photos that are later stitched into orthomosaics. The resulting model provides investigators with precise measurements of burn patterns and structural damage, aiding in cause analysis. Mathematically, this involves solving for camera poses and 3D points using bundle adjustment, minimized by:
$$ \min \sum_{i,j} || x_{ij} – \pi(P_i, X_j) ||^2 $$
where \( x_{ij} \) are image points, \( \pi \) is the projection function, \( P_i \) are camera parameters, and \( X_j \) are 3D points. This application not only documents the scene but also helps in planning rehabilitation efforts.
Another拓展application is remote验and command. With the integration of 5G capabilities, the fire drone can stream live video and sensor data to centralized command centers. This enables experts to conduct virtual inspections without being physically present, reducing risk and improving decision-making. For instance, during a wildfire, the drone can hover over hotspots, transmitting thermal imagery that highlights temperature gradients. Commanders can then allocate resources based on real-time火势spread models, optimizing suppression strategies. I implemented a low-latency communication protocol that prioritizes alert packets, ensuring critical information reaches operators within seconds. This remote capability is crucial for coordinating multi-agency responses in large-scale incidents.
Furthermore, the fire drone can be adapted for微量物证collection. By attaching robotic arms or specialized samplers, it can gather physical evidence from inaccessible or hazardous areas, such as chemical residue or gas samples. This is particularly useful in industrial fire investigations where human entry is dangerous. The drone’s payload capacity allows for modular attachments, and I developed control algorithms for precise manipulation mid-flight. For example, a vacuum pump module can collect particulate matter, with the sampling volume \( V \) calculated as:
$$ V = \int_{0}^{t} Q \, dt $$
where \( Q \) is the flow rate and \( t \) is the sampling time. This application enhances forensic capabilities, providing investigators with tangible evidence while minimizing exposure to risks.
The market impact and significance of deploying such fire drones are profound. In my analysis, the adoption of autonomous surveillance systems can drastically reduce fire-related losses by enabling early detection. Traditional methods often miss incipient fires due to limited coverage, but a fleet of fire drones can patrol vast areas continuously, acting as a force multiplier for forestry agencies. Economically, this translates to lower firefighting costs and reduced property damage. For instance, by detecting a fire in its smoldering phase, containment efforts can begin before it spreads, potentially saving millions in suppression expenses. Moreover, the environmental benefits are substantial, as quicker responses help preserve biodiversity and prevent carbon emissions from large-scale burns.
In regions prone to wildfires, like California or Australia, integrating fire drones into existing monitoring networks can enhance resilience. My system’s ability to operate in remote, signal-poor areas—thanks to onboard processing—makes it suitable for global deployment. As climate change increases fire frequency, such technologies become indispensable for proactive land management. I envision fire drones becoming standard equipment for forest services, working in tandem with卫星monitoring and ground sensors to create a comprehensive early-warning ecosystem. The scalability of the PX4 platform allows for customization based on local needs, whether for urban interface zones or wilderness areas.
In conclusion, my development of a PX4-based fixed-wing fire drone represents a significant advancement in forest fire surveillance. By combining endurance, intelligence, and autonomy, this system addresses the limitations of current solutions, offering a reliable tool for常态化patrols and rapid response. The technical innovations in airframe design, software integration, and hardware selection ensure robust performance in challenging environments. As I continue to refine the algorithms and expand applications, the potential for fire drones to revolutionize fire management grows. Future work may involve swarm coordination for distributed sensing or enhanced AI models for predicting fire behavior. Ultimately, this fire drone technology embodies a shift towards smarter, safer, and more efficient wildfire prevention, contributing to the preservation of our natural resources and communities.
Throughout this article, I have emphasized the role of fire drones in transforming fire surveillance. From automated detection to advanced勘查, these systems empower responders with timely information, turning reactive approaches into proactive strategies. As drone technology evolves, I am confident that innovations like mine will play a pivotal role in mitigating the growing threat of wildfires worldwide.