
As an individual deeply involved in the study and implementation of advanced technologies for disaster response, I have witnessed a transformative shift in forest fire management. The integration of unmanned aerial vehicles, specifically designed as fire drones, is revolutionizing how we monitor, detect, and combat wildfires. Forests, often termed the planet’s lungs, are vital for ecological balance, climate regulation, and biodiversity. However, their susceptibility to wildfires poses a significant threat, demanding innovative solutions. In this comprehensive exploration, I will delve into the current applications, technical necessities, challenges, and future pathways for fire drones in forest fire suppression, emphasizing the critical role of these autonomous systems.
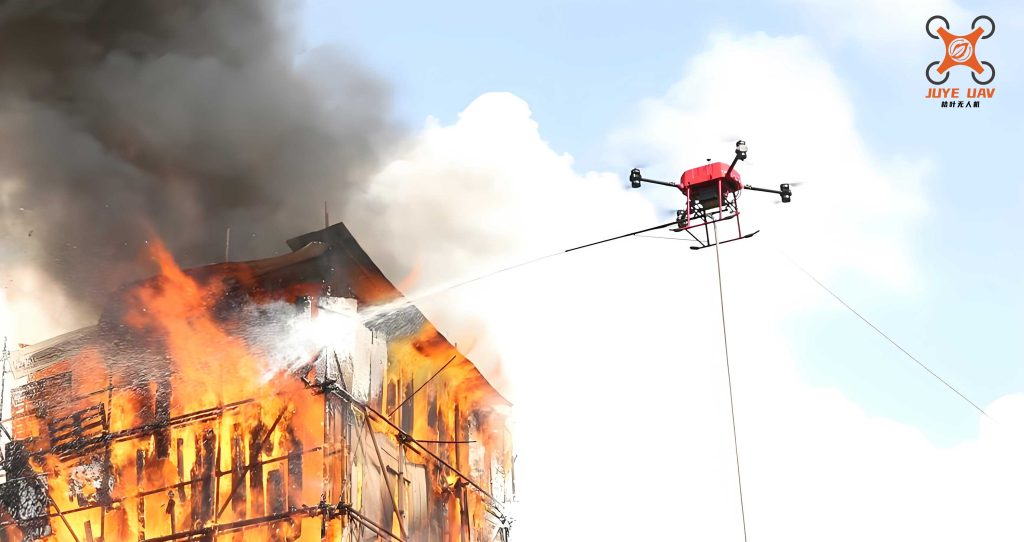
The traditional methods of forest fire surveillance, relying on ground patrols, watchtowers, or manned aircraft, are fraught with limitations. They are often resource-intensive, hazardous to personnel, and limited in coverage and real-time data acquisition. In contrast, fire drones offer a paradigm shift: they are highly mobile, cost-effective, and capable of operating in perilous environments without risking human lives. My observations and research confirm that a well-deployed fire drone system can drastically improve early detection, accurate diagnosis, and effective suppression of wildfires. The core advantage lies in their ability to carry multi-spectral sensors, process data on-board or via telemetry, and execute precise maneuvers over complex terrains. This article systematically outlines the architecture, technologies, and operational frameworks that make fire drones indispensable in modern firefighting.
Current State of Fire Drone Deployment in Wildfire Scenarios
The adoption of fire drones has progressed from experimental trials to integral components of fire management strategies globally. Initially, drones were used primarily for aerial photography and reconnaissance. However, advancements in sensor miniaturization, artificial intelligence, and communication systems have expanded their roles. Today, a typical fire drone mission encompasses three phases: search, confirmation, and persistent observation. During the search phase, multiple fire drones are deployed along pre-programmed or dynamically adjusted flight paths to patrol vast forested areas. Equipped with visual and infrared cameras, these fire drones continuously scan for thermal anomalies or smoke plumes. Upon detecting a potential fire, the fire drone enters a confirmation phase, hovering at a safe distance to validate the alert using advanced image processing algorithms. Once confirmed, the fire drone transitions to the observation phase, providing real-time video feeds, geolocation data, and environmental parameters to ground control stations and firefighting teams on the front lines.
To illustrate the capabilities of different fire drone platforms, consider the following table comparing common types used in wildfire operations:
| Fire Drone Type | Typical Endurance | Payload Capacity | Primary Sensors | Optimal Use Case |
|---|---|---|---|---|
| Multi-rotor (Electric) | 30-60 minutes | 2-5 kg | RGB Camera, Thermal Imager | Close-range inspection, tactical monitoring |
| Fixed-wing (Gasoline) | 2-6 hours | 5-15 kg | Multi-spectral Scanner, Lidar | Large-area surveillance, mapping |
| Hybrid VTOL | 1-3 hours | 3-10 kg | Hyperspectral Camera, Gas Sensor | Versatile missions, difficult terrain |
| Autonomous Helicopter | 1-2 hours | 10-20 kg | Heavy-lift payloads, communication relay | Supply delivery, extended operations |
The operational efficacy of a fire drone is heavily dependent on its sensor suite. A standard sensor package for a fire drone might include a visible-light camera for daytime imagery, a thermal infrared camera for heat signature detection, and sometimes a multispectral sensor for vegetation health assessment. The data fusion from these sensors enables robust fire detection even through smoke or at night. For instance, the thermal camera detects temperature anomalies using the Stefan-Boltzmann law, which relates the radiant emittance of a black body to its temperature:
$$ P = \epsilon \sigma A T^4 $$
where \( P \) is the radiant power, \( \epsilon \) is the emissivity, \( \sigma \) is the Stefan-Boltzmann constant, \( A \) is the area, and \( T \) is the absolute temperature. A fire drone processes these thermal readings to identify pixels exceeding a threshold temperature, indicative of a fire.
Technical Requirements and System Architecture for Effective Fire Drones
Designing a fire drone system for wildfire suppression entails meeting stringent technical requirements. From my analysis, these requirements span hardware robustness, algorithmic intelligence, and systemic integration. Firstly, the fire drone must exhibit exceptional environmental resilience. Operating near a wildfire involves exposure to high temperatures, turbulent winds, and dense smoke. Therefore, a fire drone should have a wind resistance rating of at least Beaufort scale 6 (approximately 40-50 km/h), sealed components for smoke and moisture protection, and heat-resistant materials for critical parts. Secondly, the sensor payload must be capable of high-resolution data acquisition. A typical fire drone might use a thermal camera with a resolution of 640×512 pixels and a thermal sensitivity of <50 mK to detect subtle temperature gradients.
The core of a fire drone’s intelligence lies in its onboard or ground-based processing algorithms. These algorithms perform fire detection, diagnosis, and prognosis. For detection, computer vision techniques are employed. One common approach is to use color segmentation in RGB images combined with thermal analysis. A simple fire detection model can be expressed as:
$$ F(x,y) = \begin{cases} 1 & \text{if } I_{\text{thermal}}(x,y) > T_{\text{th}} \text{ and } I_{\text{R}}(x,y) > I_{\text{G}}(x,y) > I_{\text{B}}(x,y) \\ 0 & \text{otherwise} \end{cases} $$
where \( F(x,y) \) is the fire pixel indicator at coordinates \((x,y)\), \( I_{\text{thermal}} \) is the thermal intensity, \( T_{\text{th}} \) is a temperature threshold, and \( I_{\text{R}}, I_{\text{G}}, I_{\text{B}} \) are the red, green, and blue channel intensities. More advanced methods use machine learning classifiers trained on datasets of fire and non-fire images.
For diagnosis and prognosis, the fire drone system estimates fire perimeter, spread rate, and future behavior. The rate of spread (ROS) can be modeled using empirical equations like the Rothermel model, which considers fuel moisture, slope, and wind velocity:
$$ ROS = I_R \xi (1 + \phi_w + \phi_s) / (\rho_b \epsilon Q_{ig}) $$
where \( I_R \) is the reaction intensity, \( \xi \) is the propagating flux ratio, \( \phi_w \) and \( \phi_s \) are wind and slope factors, \( \rho_b \) is fuel bulk density, \( \epsilon \) is effective heating number, and \( Q_{ig} \) is the heat of ignition. A fire drone can input real-time data into such models to predict fire progression, aiding in resource allocation.
Furthermore, the guidance, navigation, and control (GNC) system of a fire drone must ensure stable flight under disturbances. The dynamics of a multi-rotor fire drone can be described by Newton-Euler equations:
$$ \begin{aligned} m \ddot{\mathbf{r}} &= \mathbf{R} \mathbf{F}_b – m g \mathbf{e}_3 \\ \mathbf{J} \dot{\boldsymbol{\omega}} + \boldsymbol{\omega} \times \mathbf{J} \boldsymbol{\omega} &= \boldsymbol{\tau} \end{aligned} $$
where \( m \) is mass, \( \mathbf{r} \) is position, \( \mathbf{R} \) is rotation matrix, \( \mathbf{F}_b \) is body-frame thrust, \( g \) is gravity, \( \mathbf{J} \) is inertia tensor, \( \boldsymbol{\omega} \) is angular velocity, and \( \boldsymbol{\tau} \) is torque. Advanced control algorithms like PID or model predictive control are implemented to maintain trajectory tracking even in gusty conditions near fires.
Collaboration among multiple fire drones is crucial for covering large areas. A swarm of fire drones can be coordinated using distributed algorithms. For example, a Voronoi-based partitioning ensures optimal area coverage. If \( \mathcal{Q} \) is the mission area and \( p_i \) are the positions of \( n \) fire drones, the Voronoi cell \( V_i \) for the \( i \)-th fire drone is:
$$ V_i = \{ q \in \mathcal{Q} \mid \| q – p_i \| \leq \| q – p_j \|, \forall j \neq i \} $$
The fire drones then move to maximize the coverage of high-risk zones, often determined by fuel maps or historical fire data.
The integration of these components into a cohesive system is summarized in the following architecture table:
| System Layer | Components | Function in Fire Drone Operations |
|---|---|---|
| Sensing Layer | Thermal cameras, RGB cameras, multispectral sensors, GPS, IMU | Data acquisition for fire detection and localization |
| Processing Layer | Onboard computers, edge AI chips, communication modules | Real-time image analysis, sensor fusion, decision-making |
| Control Layer | Flight controllers, propulsion systems, servo actuators | Stable flight, path following, payload manipulation |
| Communication Layer | Radio links, satellite relays, mesh networking | Data transmission to ground control, inter-drone coordination |
| Ground Station | Control software, data visualization tools, mission planners | Human oversight, mission command, data analysis |
Critical Challenges in Deploying Fire Drones for Forest Firefighting
Despite their promise, the widespread adoption of fire drones faces several hurdles. Through my engagement with field operators and technologists, I have identified three primary challenges: lack of standardized technical specifications, insufficient variety and systemic integration, and relative technological immaturity. Firstly, the absence of unified standards hampers interoperability and reliability. Currently, fire drone manufacturers produce devices with disparate communication protocols, data formats, and performance metrics. This makes it difficult for agencies to integrate different fire drones into a coherent fleet. For instance, a fire drone from one vendor might use a proprietary thermal image format that is incompatible with another’s analysis software. This lack of standardization extends to operational protocols, such as frequency bands for control links or safety certifications for flight over populated areas.
Secondly, the diversity of fire drone platforms is limited relative to the multifaceted demands of wildfire suppression. Most available fire drones are small multi-rotors suited for short-duration reconnaissance. However, long-endurance platforms capable of carrying heavy payloads, like fire retardant dispensers or sophisticated sensor arrays, are scarce. This creates a gap between the ideal mission profile and available capabilities. The following table highlights the mismatch between desired tasks and typical fire drone offerings:
| Desired Mission Task | Required Fire Drone Capability | Current Typical Shortfall |
|---|---|---|
| Persistent surveillance over 8 hours | Endurance >6 hours, high-altitude operation | Most fire drones last 1-2 hours; limited by battery |
| Direct fire suppression via water drops | Payload capacity >20 kg, precise delivery | Heavy-lift fire drones are expensive and rare |
| Penetration into thick smoke for close inspection | Advanced obstacle avoidance, heat shielding | Standard fire drones avoid smoke; sensors degrade |
| Autonomous collaborative mapping of fire front | Swarm intelligence, real-time data sharing | Most fire drones operate singly or with minimal coordination |
Thirdly, technological limitations persist in key areas. The autonomy of fire drones is often rudimentary, relying heavily on manual piloting for complex tasks. While waypoint navigation is common, fully autonomous decision-making in dynamic fire environments—such as adapting flight paths based on real-time fire spread—is still experimental. Moreover, data processing speeds can be a bottleneck. A fire drone capturing high-resolution video at 4K resolution generates vast amounts of data. Transmitting this data to the ground station for analysis introduces latency, whereas on-board processing demands powerful, energy-efficient computing that is not yet commonplace in commercial fire drones. Image stabilization is another critical issue; vibrations from motors and wind can blur imagery, reducing detection accuracy. A basic vibration model for a fire drone’s camera can be described as:
$$ \ddot{x}_c + 2\zeta\omega_n \dot{x}_c + \omega_n^2 x_c = f(t) $$
where \( x_c \) is the camera displacement, \( \zeta \) is damping ratio, \( \omega_n \) is natural frequency, and \( f(t) \) is the disturbance force. Advanced gimbals and software correction are needed to mitigate this, adding to cost and complexity.
Pathways to Enhancement and Future Directions for Fire Drone Systems
To overcome these challenges, a multi-faceted approach is necessary. Based on my synthesis of best practices and emerging trends, I propose three strategic pathways: establishing targeted standards, developing a comprehensive and practical equipment ecosystem, and fostering collaborative mechanisms that incorporate societal resources. Firstly, the formulation of industry-specific standards for fire drones is imperative. These standards should cover performance metrics (e.g., minimum wind resistance, thermal operating range), data communication protocols (e.g., using open standards like MAVLink), and safety procedures. A regulatory framework could define certification processes for fire drones intended for wildfire operations, ensuring reliability under extreme conditions. For instance, a standard might require that a fire drone demonstrate an ability to maintain stable flight in crosswinds of 50 km/h while carrying a thermal camera, verified through rigorous testing.
Secondly, building a versatile fire drone fleet requires strategic procurement and development. Agencies should acquire a mix of fire drone types tailored to different mission phases. For example, fixed-wing fire drones for broad-area scanning, multi-rotor fire drones for tactical observation, and heavy-lift fire drones for suppression support. Integration is key; a unified ground control station should be able to manage heterogeneous fire drone platforms, fusing their data into a common operational picture. The payload ecosystem must also expand. Beyond cameras, fire drones could be equipped with lidar for 3D mapping, gas sensors to detect volatile organic compounds from smoldering fires, or even seeding devices for preventive vegetation management. The cost-effectiveness of deploying a fire drone swarm can be analyzed using an optimization formula:
$$ C_{\text{total}} = \sum_{i=1}^{N} (C_{\text{drone},i} + C_{\text{operation},i}) \cdot t_i $$
where \( C_{\text{total}} \) is the total cost, \( N \) is the number of fire drones, \( C_{\text{drone},i} \) is the acquisition and maintenance cost per fire drone, \( C_{\text{operation},i} \) is the cost per hour of operation (including energy, data transmission), and \( t_i \) is the mission time for each fire drone. Minimizing \( C_{\text{total}} \) while maximizing coverage area \( A_{\text{covered}} \) is a typical operational research problem solved via linear programming or heuristic algorithms.
Thirdly, collaboration between government agencies, research institutions, and private sector companies can accelerate innovation. Public-private partnerships can fund the development of next-generation fire drones with enhanced autonomy and resilience. Moreover, training programs for operators are essential. A certified curriculum for fire drone pilots should include not only flight skills but also basics of fire behavior, sensor interpretation, and emergency procedures. This ensures that the human element effectively complements the technological capabilities of the fire drone. Additionally, leveraging volunteer or commercial drone operators during peak fire seasons through coordinated networks can augment official capacity. Such a decentralized system requires robust communication protocols and data sharing agreements to ensure that all fire drones in the airspace contribute synergistically.
Looking ahead, the future of fire drones lies in increased intelligence and interoperability. I envision fire drones evolving into fully autonomous agents capable of not only detecting fires but also making preliminary suppression decisions, such as deploying retardant or igniting backfires in a controlled manner. Advances in artificial intelligence, particularly deep learning for image recognition and reinforcement learning for adaptive path planning, will be pivotal. For example, a fire drone could use a convolutional neural network (CNN) for fire detection, with an architecture defined as:
$$ \mathbf{y} = \sigma(\mathbf{W}_L * \sigma(\mathbf{W}_{L-1} * \dots \sigma(\mathbf{W}_1 * \mathbf{I} + \mathbf{b}_1) \dots + \mathbf{b}_{L-1}) + \mathbf{b}_L) $$
where \( \mathbf{I} \) is the input image, \( \mathbf{W}_l \) and \( \mathbf{b}_l \) are weights and biases at layer \( l \), \( * \) denotes convolution, and \( \sigma \) is an activation function. Training such networks on diverse datasets will improve detection accuracy under varying conditions.
Conclusion
In summary, the integration of fire drones into forest firefighting represents a significant leap forward in our ability to protect vital ecosystems and communities. From my perspective, the journey from early reconnaissance tools to sophisticated, collaborative systems is well underway, yet there is ample room for growth. The fire drone, as a versatile platform, addresses the triage of monitoring, detection, and suppression with unprecedented efficiency. However, realizing its full potential demands concerted efforts in standardization, technological advancement, and systemic integration. By addressing the challenges outlined and pursuing the recommended pathways, we can cultivate a robust fire drone ecosystem that not only enhances wildfire response but also contributes to proactive forest management. As these technologies mature, I am confident that fire drones will become indispensable allies in our ongoing battle against wildfires, safeguarding forests for future generations.