
In the daily operation and maintenance management of power systems, aerial work on overhead transmission lines presents significant hazards due to its high-altitude nature. Violation behaviors during such operations can threaten worker safety. Traditional monitoring methods in grid companies often rely on manual supervision, which struggles to achieve real-time coverage of all work sites and timely detection of all violations. Therefore, to promote the intelligent transformation of power work safety management, there is a pressing need to design smarter methods that replace manual efforts, ensuring both management efficiency and accurate violation behavior recognition. Existing approaches, such as those based on compressed deep learning models or machine vision, face challenges in handling dynamic behavioral features and multi-scale targets, leading to insufficient recognition accuracy in complex scenes. To address these limitations, I propose a novel method for violation behavior recognition in aerial work on overhead transmission lines, leveraging a tethered UAV drone and a spatio-temporal graph convolutional network (ST-GCN). This method aims to dynamically capture behavioral features from continuous image sequences, thereby improving recognition precision.
The core of my approach involves using a tethered UAV drone to collect high-altitude work scene images from overhead transmission lines. The UAV drone is equipped with a high-resolution camera and connected via a tether cable to a ground communication system for real-time image transmission. This setup ensures stable and high-quality data acquisition, even in challenging environments. The collected images are then processed to extract spatio-temporal features of worker behavior using an ST-GCN, which models human skeleton points and their connections over time. This allows for a more comprehensive analysis of dynamic actions compared to single-frame image methods. Finally, a classifier module is constructed to identify violation behaviors by comparing extracted features with a pre-defined database of annotated violations. Throughout this process, the UAV drone serves as a critical tool for data collection, enabling continuous monitoring and enhancing safety oversight.
To elaborate on the methodology, I first focus on feature extraction using the ST-GCN. Human skeleton points are represented as an undirected graph, where joints are nodes and bones are edges. The graph is defined as $$G = (V, E)$$, where $$V$$ is the set of skeleton joint points and $$E$$ is the set of connecting edges. For a sequence of images captured by the UAV drone over continuous time, the spatio-temporal graph convolution operation aggregates features across both spatial and temporal dimensions. The computation can be expressed as:
$$f = \sum_{k} D_{k}^{-\frac{1}{2}} A_{k} D_{k}^{-\frac{1}{2}} W_{k} \cdot K$$
Here, $$f$$ represents the output spatio-temporal graph feature of worker behavior posture, $$k$$ denotes a subset of image data, $$K$$ is the entire set of images collected by the UAV drone, $$D_{k}$$ is the degree matrix of the graph subset, $$A_{k}$$ is the adjacency matrix representing skeleton connections, and $$W_{k}$$ is the convolutional weight. By stacking multiple convolutional blocks and applying pooling operations, the network effectively extracts rich behavioral features that capture motion dynamics. This process addresses the limitation of static feature analysis by incorporating temporal dependencies, which is essential for accurate behavior recognition in aerial work scenarios monitored by the UAV drone.
Next, I construct a classifier module for violation behavior recognition. This module integrates features from different granularities to enhance discrimination. The classifier is formulated as:
$$F = \beta \cdot \arctan\left(\frac{f_1 + f_2}{w \times h}\right) \cdot \rho$$
In this equation, $$F$$ denotes the violation behavior recognition classifier, $$f_1$$ and $$f_2$$ are behavioral features output from the ST-GCN at two adjacent granularities, $$\beta$$ is an attention matrix that weights important regions, $$w$$ and $$h$$ are the width and height dimensions of the feature map, and $$\rho$$ is a weighting function that adjusts the contribution of features. To identify violations, the classifier compares the extracted features with a pre-defined database of annotated violation behaviors. The similarity between joint points in the input data and the database is computed using an embedded normalized Gaussian function:
$$\eta = \frac{e^{\theta(g) \cdot \theta(f)}}{\sum_{c} e^{\theta(g)_c \cdot \theta(f)_c}}$$
Here, $$\eta$$ represents the joint point similarity, $$g$$ is the feature from the violation behavior database, $$f$$ is the feature from the UAV drone-collected images, $$\theta$$ denotes an embedding function, $$c$$ indexes the embedding channel dimensions, and $$e$$ is the base of the natural logarithm. A higher similarity indicates a match with known violation behaviors, allowing the classifier to output recognition results. This multi-granularity analysis ensures robustness in identifying various violation types, such as unsafe postures or equipment misuse, during aerial work on transmission lines.
To validate the proposed method, I conducted experiments in a real-world overhead transmission line work scenario. The experimental setup involved a tethered UAV drone for image acquisition. The UAV drone was a large multi-rotor model with key technical parameters summarized in Table 1. This UAV drone provided stable flight and high payload capacity, essential for carrying the necessary monitoring equipment.
| Parameter Name | Technical Specification |
|---|---|
| Flight Speed (m/s) | 1 to 12 |
| Empty Weight (kg) | 12 |
| Number of Rotors | Eight rotors |
| Flight Distance (km) | ≤ 5 |
| Maximum Flight Altitude (m) | 5000 |
| Maximum Payload Weight (kg) | 20 |
| Hovering Accuracy (m) | Horizontal: ±0.2, Vertical: ±0.5 |
| Diagonal Wheelbase (mm) | 1550 |
| Maximum Wind Resistance Level | Level 7 |
| Maximum Rain Resistance (mm) | 8 |
The UAV drone was equipped with a high-resolution camera for capturing work scene images. The camera specifications are listed in Table 2, which include features like high frame rate and sensitivity to support both daytime and nighttime monitoring. Additionally, the UAV drone was fitted with powerful LED lights for illumination during low-light conditions, ensuring continuous operation.
| Parameter Name | Technical Specification |
|---|---|
| Resolution | 4608 (H) × 3072 (V) |
| Sensor Type | CMOS |
| Target Surface Size | 25.34 mm (H) × 16.90 mm (V) |
| Pixel Size | 5.5 μm × 5.5 μm |
| Frame Rate | 342.5 fps |
| Analog-to-Digital Conversion Accuracy | 12 bit |
| Signal-to-Noise Ratio | 41.6 dB |
| Exposure Time | 1 μs |
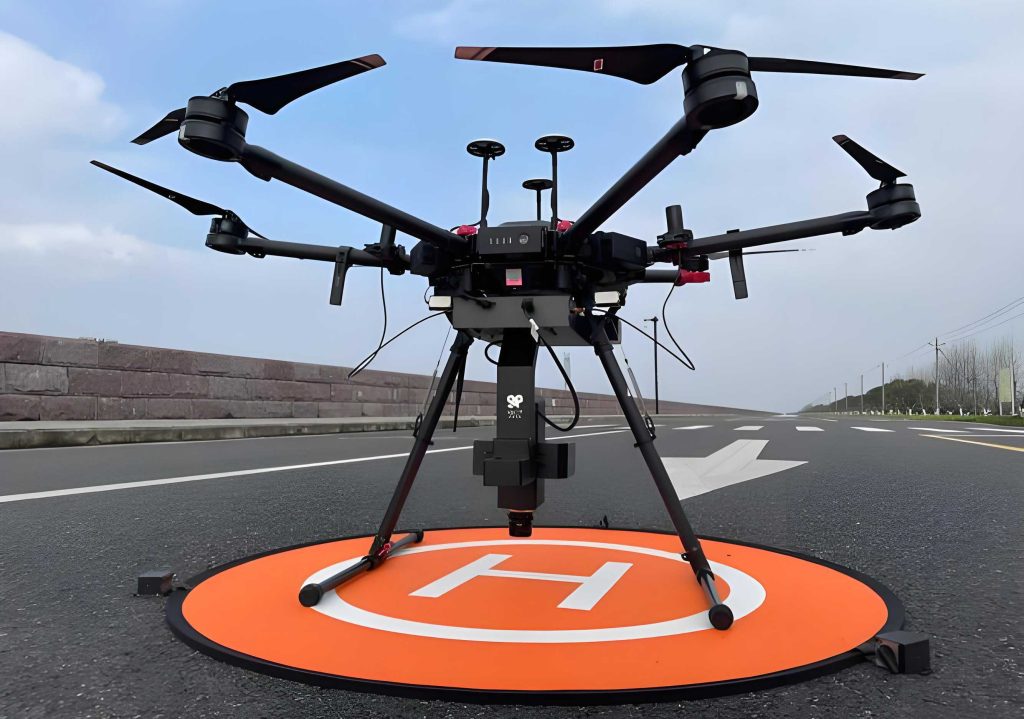
The image above illustrates the tethered UAV drone used in the experiments, showcasing its design and deployment in the field. This UAV drone enabled efficient data collection from aerial work sites, providing a foundation for subsequent analysis. After acquiring images, I input them into the ST-GCN for feature extraction. The performance of the feature extraction process was evaluated by monitoring the loss function during training. The loss curve demonstrated rapid convergence within a few iterations, with low final loss values, indicating that the ST-GCN effectively learned dynamic behavioral features from the UAV drone-captured sequences. This is critical for accurately describing worker postures over time.
To assess the violation behavior recognition accuracy, I compared the proposed method with two existing approaches: one based on a compressed YOLO model and another using machine vision techniques. The recognition performance was analyzed using Receiver Operating Characteristic (ROC) curves, which plot the true positive rate against the false positive rate. The results are summarized in Table 3, which includes the Area Under the Curve (AUC) values for each method. The AUC serves as a metric for overall accuracy, with higher values indicating better performance.
| Method | AUC Value | Key Characteristics |
|---|---|---|
| Proposed Method (UAV Drone + ST-GCN) | 0.96 | Uses spatio-temporal features from UAV drone images; dynamic behavior capture |
| Compressed YOLO-based Method | 0.88 | Relies on single-frame detection; reduced computational cost but lower accuracy in complex scenes |
| Machine Vision Method | 0.85 | Employs 3D reconstruction; struggles with multi-scale targets and feature fusion |
The ROC curve for the proposed method showed a superior shape compared to the others, with an AUC of 0.96. This high value underscores the effectiveness of leveraging spatio-temporal features from UAV drone data. In contrast, the other methods exhibited lower AUCs due to their limitations in handling dynamic behaviors and scale variations. The improvement can be attributed to the ST-GCN’s ability to model temporal dependencies, which is enhanced by the continuous image streams provided by the UAV drone. For instance, the UAV drone’s capability to capture high-frame-rate video allows for detailed motion analysis, leading to more precise identification of violations like improper tool handling or unsafe climbing postures.
Further analysis involved evaluating the feature extraction efficiency. The loss function during ST-GCN training decreased steadily, reaching a plateau after approximately 50 iterations. This rapid convergence indicates that the network quickly learned to associate skeleton points across frames, minimizing errors in behavior representation. The loss can be quantified as:
$$L = \frac{1}{N} \sum_{i=1}^{N} \| y_i – \hat{y}_i \|^2$$
Here, $$L$$ is the mean squared error loss, $$N$$ is the number of training samples, $$y_i$$ is the ground truth behavior label, and $$\hat{y}_i$$ is the predicted output from the UAV drone-based ST-GCN model. The low loss values confirm the model’s robustness in feature extraction, which directly contributes to high recognition accuracy. Additionally, the UAV drone’s role in providing diverse and real-time data cannot be overstated; it ensures that the model is exposed to various scenarios, improving generalization.
In terms of computational efficiency, the proposed method balances accuracy and resource usage. While the ST-GCN involves complex graph operations, the use of a tethered UAV drone reduces latency in data transmission, enabling near-real-time processing. The overall system architecture integrates the UAV drone for data acquisition, the ST-GCN for feature extraction, and the classifier for violation identification. This pipeline is summarized in the following formula representing the end-to-end process:
$$R = C(S(U(I)))$$
Where $$R$$ is the final recognition result, $$C$$ denotes the classifier module, $$S$$ represents the ST-GCN feature extraction, $$U$$ symbolizes the UAV drone image acquisition function, and $$I$$ is the input work scene. This streamlined approach highlights the synergy between the UAV drone and deep learning techniques for safety monitoring.
To delve deeper into the classifier module, I analyzed the attention mechanism that prioritizes key regions in the images. The attention matrix $$\beta$$ is computed based on feature map activations, focusing on areas with high behavioral significance. This is particularly useful in cluttered aerial work environments captured by the UAV drone, where multiple workers or equipment may be present. The attention-weighted feature fusion can be expressed as:
$$\beta = \text{softmax}\left( \frac{Q \cdot K^T}{\sqrt{d}} \right)$$
In this equation, $$Q$$ and $$K$$ are query and key matrices derived from the ST-GCN features, and $$d$$ is the dimensionality. This mechanism enhances the classifier’s ability to discern subtle violation behaviors, such as a worker forgetting to use safety harnesses, which might be overlooked without spatial emphasis. The UAV drone’s high-resolution imagery supports this by providing clear visual details.
Another aspect is the scalability of the method. The tethered UAV drone can be deployed across multiple transmission line sites, offering broad coverage. The ST-GCN model can be trained on diverse datasets collected by UAV drones, ensuring adaptability to different work practices and environments. For future work, integrating more advanced sensors on the UAV drone, such as thermal cameras or LiDAR, could further improve recognition under varying weather conditions. Moreover, the UAV drone-based system can be coupled with automated alert mechanisms, where detected violations trigger immediate warnings to onsite supervisors, thereby preventing accidents.
In conclusion, the proposed method for violation behavior recognition in aerial work on overhead transmission lines demonstrates significant advantages by combining a tethered UAV drone with a spatio-temporal graph convolutional network. The UAV drone enables reliable and continuous image acquisition, while the ST-GCN extracts dynamic behavioral features that capture temporal evolutions. The classifier module accurately identifies violations by comparing features with a pre-annotated database. Experimental results show an AUC of 0.96, outperforming existing methods and validating the approach’s high precision. This UAV drone-based system not only enhances safety monitoring but also paves the way for intelligent power grid management. Future enhancements could involve real-time processing on the UAV drone itself or integration with IoT platforms for comprehensive safety ecosystems. Ultimately, the use of UAV drone technology in this context represents a step forward in automating hazard detection and protecting workers in high-risk industries.