
As an active researcher in the field of autonomous navigation, I have dedicated my recent work to addressing one of the most critical challenges in modern aviation: the path planning of an unmanned aerial vehicle in complex low-altitude environments. The rapid advancement of drone technology has expanded the application scope of an unmanned aerial vehicle to include logistics delivery, power line inspection, agricultural monitoring, and emergency rescue. However, the operational envelope of an unmanned aerial vehicle in mountainous or urban settings presents significant obstacles that traditional planning methods often fail to overcome. The core issue lies in the need for an algorithm that can simultaneously handle environmental constraints, such as terrain elevation and dense obstacles, while maintaining a balance between exploration and exploitation during the search process.
My research focuses on two typical complex environments: mountainous regions characterized by continuous and rugged elevation surfaces, and urban areas filled with dense, regular-shaped obstacles. For these distinct scenarios, I have proposed and validated two improved swarm intelligence optimization algorithms. It is worth noting that while the theoretical development of these algorithms is fundamental to my work, the ultimate goal is to provide a highly effective solution for real-world unmanned aerial vehicle operations, ensuring their safety and efficiency when performing low-altitude flight missions.
1. Problem Formulation and Environmental Modeling for UAV Path Planning
The primary challenge of global path planning for an unmanned aerial vehicle is to find a feasible and safe trajectory from a start point to a destination under multiple kinematic and environmental constraints. To address this, I first established a rigorous three-dimensional environmental modeling framework. For mountainous terrains, a digital elevation model is employed to create a continuous elevation surface covering peaks and slopes. For urban environments, I constructed a block-based map that mimics dense building clusters. In my experimental setup, the total flight area is represented as dimensional bounds, as expressed by the following constraint:
$$ x \in [0, x_{max}], \quad y \in [0, y_{max}], \quad z \in [0, z_{max}] \tag{1} $$
The path planning of an unmanned aerial vehicle requires careful consideration of various physical limits. The design of the cost function is critical to ensuring path quality. I considered four main aspects: the minimum flight height \( H_{min} \), the minimum path segment length \( l_{min} \), the maximum turning angle \( \phi \), the maximum climb/dive angle \( \theta \), and the total path length \( L_{max} \). The path cost function \( C \) is defined to balance these factors:
$$ C = \sum_{i=1}^{n} (\omega_1 l_i + \omega_2 h_i + \omega_3 g_i) \tag{2} $$
where \( l_i \) is the length of the i-th path segment, \( h_i \) is the altitude above ground, and \( g_i \) is the threat index. The weights satisfy \( \omega_1 + \omega_2 + \omega_3 = 1 \). This multi-objective cost function ensures a smooth and safe flight, reflecting a significant improvement over conventional single-objective methods in unmanned aerial vehicle path planning.
2. Performance Evaluation Metrics and Benchmark Functions
After modifying the optimization algorithms, I needed to validate their effectiveness. I utilized the CEC2005 benchmark test suite, which comprises 23 functions with distinct characteristics. These functions are categorized into unimodal, multimodal, and fixed-dimension hybrid functions. The evaluation metrics used in all experiments are the mean and standard deviation of the fitness values across multiple independent runs.
To ensure a fair comparison, the population size for all algorithms in all experiments is set to 30 and the maximum number of iterations is 500 unless otherwise stated. Each algorithm undergoes 50 independent runs to produce statistically significant results. I also use the Friedman test for non-parametric statistical ranking and the Wilcoxon signed-rank test to assess the significance of the performance differences between the proposed algorithms and their counterparts. The sensitivity analysis is performed to determine the optimal pairing of population size and iteration number.
3. A Multi-Strategy Improved Hippopotamus Algorithm for Mountainous Terrain
To overcome the limitations of the standard Hippopotamus Optimization (HO) in mountain environments—such as low convergence accuracy and a tendency to fall into local optima—I developed the DMHO algorithm. This improvement incorporates four distinct strategies. I utilized a Lévy flight mechanism to enhance the population diversity during initialization:
$$ X_i = X_{min} + L(\lambda) \cdot (X_{max} – X_{min}) \tag{3} $$
where \( L(\lambda) \) is a random vector generated by the Lévy distribution, promoting a more extensive coverage of the search space. In the position update phase, I introduced a dynamic growth ratio mechanism instead of the fixed convergence factor \( T \). This dynamic parameter allows individuals with better fitness to stray farther from the group, mimicking the independent exploration of mature hippos:
$$ T_{dyn} = f_{best} / f_{it}(i) \tag{4} $$
By employing the LOBL strategy with an adaptive learning coefficient \( k \) and applying a random diffusion step \( s \), the algorithm significantly reduces the risk of premature convergence. The random diffusion step is defined as:
$$ s = 0.1 \cdot R(1,d) \cdot (u_b – l_b) \tag{5} $$
For the evaluation of DMHO, I compared it against eight established algorithms, including DBO, FHO, GSA, GWO, HBA, HHO, PSO, and the original HO. The results of the CEC2005 benchmark are summarized in the table below, showing the final ranking based on the Friedman test.
| Algorithm | Sum of Ranks | Average Rank | Final Rank |
|---|---|---|---|
| DMHO | 50.5 | 2.1956 | 1 |
| HO | 63 | 2.7391 | 2 |
| GSA | 95 | 4.1304 | 3 |
| HHO | 117 | 5.0870 | 4 |
| HBA | 128.5 | 5.5870 | 5 |
| FHO | 129.5 | 5.6304 | 6 |
| DBO | 134 | 5.8261 | 7 |
| GWO | 155 | 6.7391 | 8 |
| PSO | 162.5 | 7.0652 | 9 |
A sensitivity analysis confirmed that the optimal parameter configuration for DMHO is 30 individuals per population and 500 iterations when the maximum number of fitness evaluations is fixed at 15,000. The convergence curves demonstrated that DMHO not only achieves the highest accuracy but also exhibits a significantly faster convergence speed compared to other methods.
3.1 Practical Application in Mountainous 3D Path Planning
I designed three mountain simulation environments with varying numbers of mountain peaks. In these experiments, the proposed DMHO showed superior performance, finding the shortest path in all scenarios. As can be observed from the statistical results of 10 independent runs on three maps, DMHO not only achieves the lowest average fitness values (such as 2.8381E+03 in environment 1, 2.8285E+03 in environment 2, and 1.2261E+03 in environment 3) but also maintains a much smaller standard deviation than other algorithms, thereby proving its stability and reliability in the path planning of an unmanned aerial vehicle.
| Algorithm | Env1 Mean | Env1 Std | Env2 Mean | Env2 Std | Env3 Mean | Env3 Std |
|---|---|---|---|---|---|---|
| DBO | 2.8886E+03 | 7.7630E+00 | 2.8482E+03 | 1.9768E+00 | 1.2425E+03 | 6.37840E+00 |
| GWO | 2.8591E+03 | 5.1296E+00 | 2.8476E+03 | 6.7888E-01 | 1.2410E+03 | 4.78640E+00 |
| HBA | 2.8562E+03 | 3.5068E+00 | 2.8339E+03 | 7.8623E-01 | 1.2515E+03 | 8.19890E+00 |
| PSO | 2.8501E+03 | 3.5105E+00 | 2.8399E+03 | 1.3923E+00 | 1.5789E+03 | 8.26440E+01 |
| HO | 2.8412E+03 | 2.0993E+00 | 2.8424E+03 | 1.2625E+00 | 1.2268E+03 | 7.22570E+00 |
| DMHO | 2.8381E+03 | 1.3984E+00 | 2.8285E+03 | 3.4326E-01 | 1.2261E+03 | 6.71420E+00 |
To enhance the practical feasibility of the final trajectory, I incorporated a cubic spline interpolation smoothing technique after the global search process. This smoothing stage is essential for eliminating sharp turns and redundant waypoints, ensuring the generated path is gentle enough for an unmanned aerial vehicle to follow accurately.
4. A Multi-Strategy Improved Honey Badger Algorithm for Urban Environments
Urban environments pose a different set of challenges, including dense structural obstacles and highly restrictive airspace. I addressed these issues by proposing the MIHBA. This algorithm employs a Halton sequence for population initialization, which generates a uniform distribution of points in the search space, thereby promoting a very rich diversity at the outset of the optimization process. Additionally, I replaced the traditional exponential density factor with a water-wave dynamic density factor. This factor exhibits oscillatory behavior and is defined as:
$$ \alpha_{new} = 2 \cdot S \cdot \exp(-t / t_{max}) \cdot rand \tag{6} $$
where \( S \) is a random integer in [0,1]. This dynamic adjustment helps the algorithm better balance the transition between exploration and exploitation phases. The LOBL strategy is also integrated into MIHBA to enable the algorithm to efficiently jump out of local optima, which is crucial for navigating the highly cluttered urban landscape.
4.1 Experimental Results and Ablation Study
I conducted comprehensive tests to demonstrate the performance of MIHBA. In comparisons against NO, PSO, GA, DBO, and HBA, MIHBA achieved the best average value on 13 benchmark functions. An ablation study was also performed to quantify the contribution of each improvement strategy. The algorithms with all strategies integrated (MIHBA) showed the best overall performance, proving that the combination of Halton initialization, water-wave factor, and LOBL is an effective approach.
| Function | MIHBA Mean | MIHBA Std | HBA Mean | HBA Std |
|---|---|---|---|---|
| \( f_1 \) | 0.0000E+00 | 0.0000E+00 | 4.7283E-135 | 3.1823E-134 |
| \( f_2 \) | 2.1815E-211 | 0.0000E+00 | 1.8214E-72 | 4.3810E-72 |
| \( f_9 \) | 0.0000E+00 | 0.0000E+00 | 0.0000E+00 | 0.0000E+00 |
| \( f_{15} \) | 1.6665E-03 | 4.3485E-04 | 5.9713E-03 | 9.2543E-03 |
| \( f_{19} \) | -3.8626E+00 | 1.1146E-03 | -3.8615E+00 | 2.9188E-03 |
| \( f_{21} \) | -1.0153E+01 | 3.1420E-08 | -8.7291E+00 | 3.0861E+00 |
In the table above, the results clearly indicate that MIHBA has superior optimization accuracy and stability compared to the original HBA, especially on complex multimodal functions. The Wilcoxon signed-rank test results with a significance level of 0.05 also showed a significant difference between MIHBA and all other comparison algorithms.
4.2 Practical Application in Urban 3D Path Planning
I created three distinct urban digital maps to test the algorithm’s adaptability in different construction layouts. These environments included a suburban-like zone, a commercial district with L-shaped obstacles and narrow flight corridors, and a high-rise residential simulation with varying building heights. In all these test settings, MIHBA consistently generated paths that were shorter, smoother, and safer. The convergence curves indicated that MIHBA could converge to a high-quality solution in the early stages of the iteration process, which is particularly desirable in real-time urban operations where computational time is limited.
| Algorithm | Env4 Mean | Env4 Std | Env5 Mean | Env5 Std | Env6 Mean | Env6 Std |
|---|---|---|---|---|---|---|
| MIHBA | 161.67 | 2.27 | 334.42 | 5.27 | 541.62 | 63.95 |
| HBA | 164.35 | 11.87 | 338.17 | 66.66 | 549.97 | 82.67 |
| PSO | 163.99 | 7.90 | 348.70 | 30.91 | 553.07 | 43.22 |
| DBO | 166.68 | 8.25 | 386.18 | 107.54 | 555.70 | 47.66 |
5. Experimental Verification and System Implementation
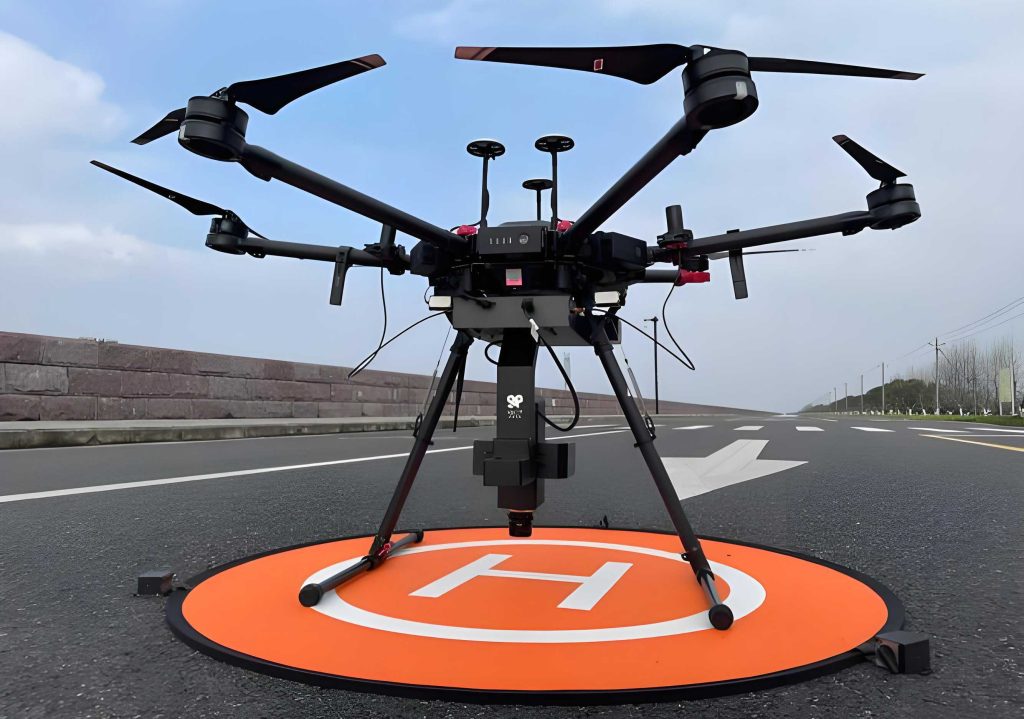
To validate the practical value of the proposed methods, I constructed a robust experimental platform based on a quadrotor hardware system. The core computational unit is an NVIDIA Jetson Orin NX, which is responsible for executing the path planning algorithms. The visual and depth information is collected using an Intel RealSense D435i sensor, and the flight control is managed by a Pixhawk autopilot unit. The high-level commands generated by the algorithms are converted to control signals using the MAVLink communication protocol via ROS.
The system architecture is modular, featuring a clear division between the perception layer, computation layer, and control layer. The flight controller and the companion computer communicate over a UART interface, while the remote telemetry and ground station (QGroundControl) interface is established via wireless data transmission modules. This setup allows me to closely monitor the performance of the algorithms during actual flight in real-time.
6. Results from Real-World Flight Tests
I selected two actual flight test areas that are representative of generic mountain-like and city-like environments. The mountain-like area had continuous elevation changes with several natural obstacles, while the city-like area featured multiple uniformly arranged tree clusters that mimic buildings. I tested the planned paths using the DMHO and MIHBA algorithms in these settings, respectively.
During the distinct flights, I compared the performance of the improved algorithms with their baseline versions. In the mountain-like environment, the path generated by DMHO achieved a fitness value of 246.57, a clear improvement over the baseline HO algorithm which achieved a fitness value of 254.09. This demonstrates an improvement of 2.96%. Similarly, in the city-like environment, MIHBA achieved a fitness value of 153.89, outperforming the basic HBA algorithm which achieved 156.34, showing an improvement of 1.57%. These numerical results across the actual field tests underscore the effectiveness of the improvement strategies in enhancing the application of an unmanned aerial vehicle.
Through these tests, I confirmed that the improved algorithms can successfully adapt to two distinct types of complex environments. The optimization results from the simulation stage are consistent with the outcomes from the real flight tests, thereby proving the transferability of my algorithms from a simulated environment to the real world. This entire process showcases the high performance and robustness of the improved swarm intelligence algorithms in solving the global path planning problem for an unmanned aerial vehicle.
Conclusion
In this research, I have systematically addressed the challenges of 3D path planning for an unmanned aerial vehicle in both mountainous and urban environments by introducing two innovative swarm intelligence algorithms, DMHO and MIHBA. By incorporating diverse strategies such as Lévy flight, dynamic growth ratio, adaptive prism opposition-based learning, and random diffusion, I significantly enhanced the exploratory and exploitative capabilities of the original algorithms. Extensive testing on standard benchmark functions and carefully designed simulations of real-world environments, followed by flight validations on a self-constructed UAV platform, demonstrated that the improved algorithms outperform several state-of-the-art baselines. The proposed DMHO and MIHBA algorithms provide a reliable and highly efficient solution for the practical engineering application of an unmanned aerial vehicle.
With the continued development of intelligent algorithms, I believe the future will bring even more advanced techniques. As part of the ongoing research, I plan to investigate the potential of combining these algorithms with reinforcement learning to handle dynamic moving obstacles and multi-UAV cooperative missions. Such integration could further enhance the autonomy of an unmanned aerial vehicle and expand its operational boundaries to a wider range of low-altitude economic activities. The successful validation of the current algorithms paves a solid theoretical foundation for these future advancements.