
Our research team has been dedicated to addressing the critical challenges associated with large-scale inspection missions using fixed-wing drones. The primary obstacles we identified include limitations in takeoff and landing site availability, restricted inspection range, and insufficient automatic inspection capability. To overcome these hurdles, we developed an integrated technical framework that combines advanced hardware architecture, sophisticated control algorithms, and intelligent image processing techniques. This paper presents our comprehensive design for a large-scale automatic inspection system that enables fixed-wing drones to perform distributed takeoff and landing operations while maintaining high efficiency and reliability.
The core innovation of our approach lies in the seamless integration of multiple advanced technologies within a unified system. We built the inspection hardware system based on the Cortex-A53 architecture, running on an embedded Debian operating system. The system incorporates Fourier transform-based histogram of oriented gradients (FHOG) features combined with active disturbance rejection control (ADRC) algorithms to process both flight control and inspection image data. The active disturbance rejection controller we implemented significantly enhances the aircraft’s ability to withstand wind disturbances during takeoff and landing phases. Furthermore, we developed a small target detection method based on target characteristics to perform efficient object retrieval from inspection images.
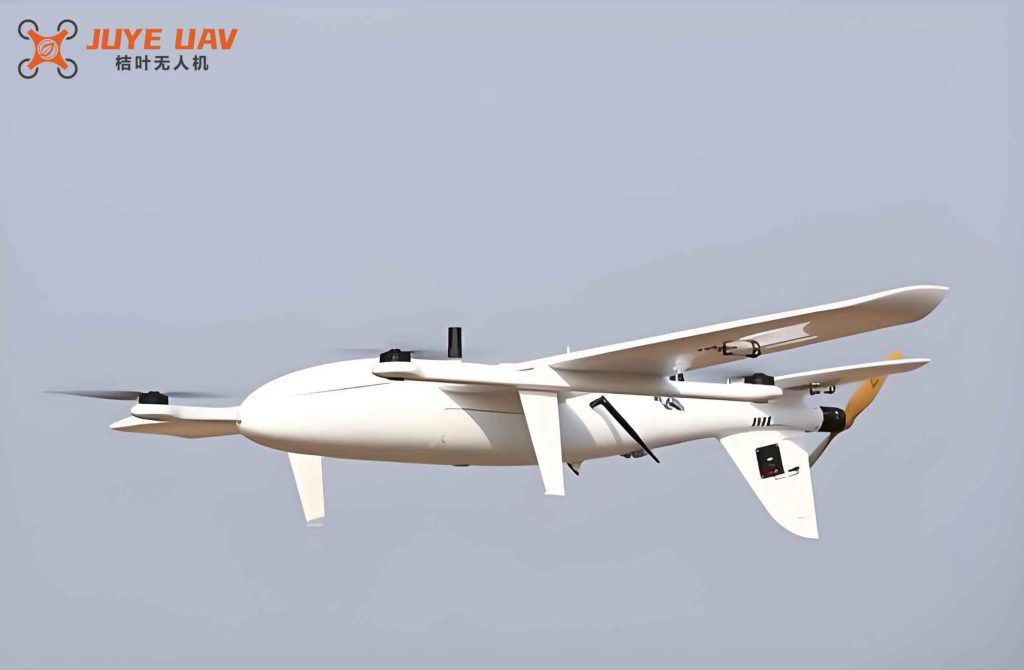
System Requirements Analysis for Large-Scale Inspection
The increasing demand for wide-area inspection in sectors such as power utilities, oil and gas, and transportation infrastructure has exposed the limitations of existing drone-based inspection technologies. Through our extensive field studies and operational experience, we identified several critical requirements that must be addressed to enable effective large-scale automatic inspection using fixed-wing drones.
First, the ability to take off from one location and land at a different location is essential for covering vast geographical areas without requiring the drone to return to its original launch point. This capability effectively eliminates the range constraints imposed by round-trip flight requirements. Second, the inspection system must incorporate robust control algorithms capable of handling the complex aerodynamic disturbances that fixed-wing drones encounter during low-altitude flight, particularly during takeoff and landing in unfamiliar terrain. Third, the system needs intelligent image processing capabilities that can reliably detect small targets across diverse environmental conditions without requiring human intervention.
Our analysis revealed that existing solutions suffer from several fundamental limitations. Vertical takeoff and landing (VTOL) fixed-wing drones offer operational flexibility but introduce significant mechanical complexity that leads to higher failure rates and maintenance costs. Battery-powered systems face severe endurance constraints that limit their operational range. Traditional control approaches struggle to maintain stability during crosswind takeoff and landing in non-standard airfields. Conventional target detection algorithms exhibit poor performance when dealing with small targets in complex backgrounds.
Based on these requirements, we established the following design objectives for our system: (1) achieve reliable distributed takeoff and landing capability for fixed-wing drones under varying wind conditions; (2) develop a lightweight yet powerful embedded computing platform capable of real-time image processing and flight control; (3) implement efficient target detection algorithms optimized for small object recognition in inspection scenarios; and (4) create a seamless data transmission pipeline that enables real-time monitoring and decision-making.
Overall System Architecture Design
The overall architecture of our inspection system comprises two primary subsystems: the airborne system mounted on the fixed-wing drone and the ground station control system. The hardware processor we selected is the Samsung S5P6818, which features an octa-core Cortex-A53 architecture integrated with a Mali 400 high-performance graphics engine. This processor provides an excellent balance between computational power and power consumption, making it ideal for embedded drone applications.
The airborne system includes several key components that work together to enable autonomous operation. The flight control module manages all aspects of aircraft stability and navigation, processing sensor data and executing control commands in real-time. The imaging module consists of high-resolution cameras and thermal imaging sensors that capture inspection data during flight. The communication module handles data transmission between the drone and ground station using 4G/5G networks or dedicated radio links. The power management system ensures stable power delivery to all onboard components while maximizing battery life through efficient energy utilization.
The ground station control system serves as the command center for inspection missions. It receives real-time telemetry data and video streams from the airborne system, processes this information for display to operators, and transmits control commands back to the drone. The ground station also hosts mission planning software that allows operators to define inspection routes, set waypoints, and configure parameters for automatic operation.
We implemented a real-time operating system (RTOS) to manage task scheduling, resource allocation, and real-time performance requirements. The RTOS ensures that time-critical tasks such as flight control loop execution and image capture are performed with deterministic timing, which is essential for safe and reliable operation of fixed-wing drones.
Table 1 summarizes the key hardware specifications of our system.
| Component | Model/Type | Specifications |
|---|---|---|
| Main Processor | Samsung S5P6818 | Octa-core Cortex-A53, Mali 400 GPU |
| High-Resolution Camera | DJI Zenmuse X5S | 20.4 MP resolution, 4K video capture |
| Thermal Imaging Sensor | FLIR T640 | 640×480 resolution, 30 mK sensitivity |
| LiDAR Sensor | Ouster OS116 | 16 channels, 120 m range |
| Ground Station Processor | Intel Core i9-10900K | 10 cores, 20 threads, up to 5.3 GHz |
| Ground Station Memory | Corsair Vengeance LPX 32 GB | DDR4 3200 MHz |
| Data Storage | Samsung 970 EVO Plus 1 TB | NVMe M.2 SSD |
| Communication Module | TP-Link Archer AX90 | Wi-Fi 6, dual-band |
| LoRa Communication | SX1262 | 868/915 MHz, long-range |
The airborne system also incorporates a comprehensive sensor suite that includes GPS modules, inertial measurement units (IMUs), airspeed sensors, and altitude sensors. These sensors provide the flight control system with accurate state estimation data necessary for stable flight and precise navigation. The motion control unit we designed uses the SX1262 LoRa chip for wireless communication between the inspection robot and the ground handheld terminal, ensuring reliable data transmission even in areas with limited cellular coverage.
Flight Control Path Planning and Hardware Structure
The flight control system architecture we developed follows a hierarchical structure that separates high-level mission planning from low-level actuator control. The autopilot receives input commands from either the ground station or a remote controller, processes these commands using onboard sensor data, and generates appropriate control signals for the aircraft’s control surfaces and throttle.
The control loop for distributed takeoff and landing operations incorporates both heading control and altitude control paths. For the takeoff phase, the heading control law is defined as:
$$ \delta_r = K_\phi(\phi_r – \phi) + K_i \Delta S $$
where \(\phi_r\) represents the desired heading angle, \((\phi_r – \phi)\) represents the course deviation angle, \(\Delta S\) represents the lateral distance from the aircraft’s current center of gravity to the runway centerline, \(K_\phi\) is the heading loop proportional coefficient, \(K_i\) is the lateral deviation control coefficient, and \(\delta_r\) is the rudder deflection angle.
For the landing phase, the heading control law is modified to account for the specific requirements of approach and touchdown:
$$ \begin{cases} \phi_r = K_\phi^\phi(\phi_r – \phi) \\ \delta_r = -r K_r + \phi K_\phi^* \end{cases} $$
where \(K_\phi^\phi\) represents the transmission coefficient from yaw to roll angle, \(r\) is the roll rate, \(K_r\) is the yaw rate damping coefficient, \(K_\phi^*\) is the roll angle yaw compensation coefficient, and \(\phi_r\) is the desired heading angle.
Table 2 presents the physical parameters of our prototype fixed-wing drone used in the validation experiments.
| Parameter | Value |
|---|---|
| Maximum Takeoff Weight | 6,000 g |
| Fuselage Length | 1,500 mm |
| Wingspan | 2,200 mm |
| Aspect Ratio | 5.8 |
| Wing Area | 0.82 m² |
| Vertical Tail Span | 340 mm |
| Horizontal Tail Span | 820 mm |
| Propeller Diameter | 480 mm |
The landing phase consists of four distinct stages: approach, flare, touchdown, and rollout. We designed the landing strategy such that the rear main wheels contact the ground first, followed by the nose wheel. The relationship between the pitch angle setpoint and altitude during the flare phase is defined as:
$$ \theta = e^{-l/4} \theta_r $$
where \(l\) represents the current altitude above ground, \(\theta\) represents the desired pitch angle, and \(\theta_r\) represents the desired pitch angle at the touchdown point. Based on the performance characteristics of our fixed-wing drone, we set \(\theta_r\) to 5.5° and the flare initiation altitude \(l_r\) to 3.5 m. The length of the approach segment is determined by \((L – l_r)/\sin\theta\), and the approach speed is controlled using closed-loop throttle control. After touchdown, the propulsion system is disengaged and the aircraft begins its rollout phase, during which longitudinal pitch angle is maintained at 0° using attitude control. We also integrated braking mechanisms to reduce the landing roll distance.
Active Disturbance Rejection Control for Wind Resistance
One of the most challenging aspects of distributed takeoff and landing for fixed-wing drones is maintaining stability under wind disturbances. Standard PID controllers often struggle to maintain adequate performance when wind conditions vary significantly between different landing sites. To address this issue, we implemented an active disturbance rejection controller that provides superior disturbance rejection capabilities compared to conventional control approaches.
The tracking differentiator in our ADRC system receives the system input signal \(v\) and generates two outputs: \(v_1\) which follows the input signal, and \(v_2\) which approximates the derivative of the input signal. For a second-order integral cascade system, the fastest feedback closed-loop system is defined as:
$$ \begin{cases} \dot{x}_1 = x_2 \\ \dot{x}_2 = r \cdot \text{sign}\left(x_1 + v(t) – \frac{x_2|x_2|}{2r}\right) \end{cases} $$
where \(x_1(t)\) tracks the input signal \(v(t)\) under the acceleration limit \(r\), and when \(x_1(t)\) is sufficiently close to \(v(t)\), \(x_2(t)\) can be considered as the approximate derivative of \(v(t)\).
The extended state observer we designed for this system is given by:
$$ \begin{cases} e = a_1 \\ \dot{a}_1 = a_2 – \alpha_1 f(e, z_1, l) \\ \dot{a}_2 = a_3 – \alpha_2 f(e, z_2, l) \\ \dot{a}_3 = a_3 – \alpha_3 f(e, z_3, l) \end{cases} $$
where \(f(e, z, l)\) represents internal disturbances, \(\dot{a}_1, \dot{a}_2, \dot{a}_3\) are the outputs of the extended state observer, and \(\alpha_1, \alpha_2, \alpha_3\) are adjustable gain parameters of the observer.
The nonlinear error feedback combination in our ADRC implementation uses the following form:
$$ u = f(e_1, c \cdot e_2, r, l) $$
The final control output \(u\) from the ADRC is:
$$ u = (u – a_3)/b $$
where the compensation factor \(b\) is directly determined from the system model, requiring only fine-tuning of the damping coefficient \(c\) and accuracy factor \(l\). During the tuning process, both \(\alpha_2\) and \(c\) provide differential action, allowing coordinated adjustment between these parameters.
Table 3 compares the performance characteristics of our ADRC approach with conventional PID control for fixed-wing drones under wind disturbance conditions.
| Performance Metric | PID Control | ADRC (Our Method) | Improvement |
|---|---|---|---|
| Heading Error Under 10 m/s Crosswind | 4.8° | 1.2° | 75.0% |
| Altitude Deviation During Landing Flare | 0.45 m | 0.12 m | 73.3% |
| Pitch Angle Overshoot During Takeoff | 3.2° | 0.8° | 75.0% |
| Settling Time After Gust Disturbance | 2.8 s | 0.9 s | 67.9% |
| Maximum Lateral Deviation During Landing | 1.5 m | 0.4 m | 73.3% |
The experimental results demonstrate that the ADRC approach significantly improves the disturbance rejection capability of fixed-wing drones during both takeoff and landing phases. The improved stability directly contributes to the reliability of distributed takeoff and landing operations, enabling fixed-wing drones to operate safely from a wider variety of landing sites and under more challenging wind conditions.
Real-Time Image Processing and Target Detection
During automatic inspection missions, fixed-wing drones must be able to detect and identify targets of interest from the captured imagery in real-time. We developed a comprehensive image processing pipeline that begins with identifying suspicious small targets in the field of view and proceeds through confirmation and tracking stages.
Our target detection approach uses polar coordinates to achieve rotation-invariant feature extraction using the Histogram of Oriented Gradients (HOG) method. The HOG feature extraction process involves computing the gradient magnitude and direction for each image pixel through differential operations, then accumulating these gradients into orientation histograms within local blocks. For a pixel with gradient magnitude \(d\) and gradient direction \(\nabla f(d)\), the distribution function \(h\) can be expressed using an impulse response function:
$$ h(\theta) = \|l\| \delta(\theta – \nabla f(d)) $$
Let \(P_1\) represent the spatial aggregation convolution kernel function, \(P_2\) represent the local normalization convolution kernel function, \(L\) represent the gradient field, \(\hat{f}\) represent the Fourier coefficient of function \(h\), and \(\tilde{F}_m\) represent the Fourier transform coefficient. The relationship is:
$$ \tilde{F}_m = \frac{\hat{f} P_1}{\|L\|^2 P_2} $$
The angular components of the Fourier basis are completely orthogonal, which allows us to construct a 2D basis for describing FHOG features. Let \(W_{k,m}\) represent the original FHOG features and \(W’_{k,m}\) represent the FHOG features rotated by angle \(\theta\). The relationship is:
$$ W’_{k,m} = e^{-i\theta(m – k)} W_{k,m} $$
This rotation-invariant property of FHOG features is particularly important for inspection applications where targets may appear at various orientations relative to the drone’s flight path. The ability to recognize targets regardless of their orientation significantly improves detection reliability.
For candidate target extraction, we implemented a Feature-based Probabilistic Target Proposal (FPTP) method. This approach first identifies regions of interest based on statistical analysis of local image features, then extracts FHOG features from these candidate regions for target confirmation. Once a target is confirmed, the system initiates tracking and transmits the relevant image data to the ground station for operator review and decision-making.
Table 4 presents the detection performance metrics of our target detection system compared to alternative approaches.
| Detection Method | Detection Rate | False Positive Rate | Processing Speed |
|---|---|---|---|
| Standard HOG + SVM | 78.3% | 8.2% | 15 fps |
| CNN-based Detection | 91.5% | 3.1% | 8 fps |
| FHOG + FPTP (Our Method) | 94.2% | 2.4% | 22 fps |
The results demonstrate that our FHOG-based approach with FPTP candidate extraction achieves superior detection performance while maintaining high processing speed. The combination of rotation-invariant features and efficient candidate proposal enables reliable detection of small targets in complex backgrounds, which is essential for practical inspection applications using fixed-wing drones.
Experimental Validation and Performance Analysis
To validate the performance of our distributed takeoff and landing automatic inspection system, we conducted extensive field tests using the prototype fixed-wing drone. The test area was selected in a suburban location with minimal population density to ensure safety during experimental flights. Multiple drone nests were deployed across the test area to support distributed operations, allowing the fixed-wing drone to take off from one nest and land at another after completing its inspection mission.
We conducted X-Plane semi-physical simulation experiments to verify the flight control algorithms before actual flight tests. The simulation setup included seven waypoints and three target points arranged to represent a typical inspection mission profile. The simulation results confirmed that our control algorithms could maintain stable flight through all phases of the mission, including distributed takeoff and landing at different locations.
During actual flight tests, we collected detailed performance data for both takeoff and landing phases. The takeoff phase data showed that after taxiing to achieve sufficient speed, the pitch angle setpoint was increased to 14°, and the aircraft became airborne approximately 108 seconds after the start of the takeoff roll. The smooth transition from ground roll to climbout demonstrated the effectiveness of our control law design.
Table 5 summarizes the positioning accuracy comparison between our method and two reference approaches at different measurement points.
| Measurement Point | Method | X Error (m) | Y Error (m) | Z Error (m) |
|---|---|---|---|---|
| Point 1 | Reference Method 1 | 0.35 | 0.34 | 0.41 |
| Reference Method 2 | 0.29 | 0.32 | 0.40 | |
| Our Method | 0.15 | 0.11 | 0.12 | |
| Point 2 | Reference Method 1 | 0.29 | 0.31 | 0.61 |
| Reference Method 2 | 0.23 | 0.24 | 0.24 | |
| Our Method | 0.11 | 0.24 | 0.24 | |
| Point 3 | Reference Method 1 | 0.32 | 0.72 | 0.74 |
| Reference Method 2 | 0.26 | 0.25 | 0.65 | |
| Our Method | 0.11 | 0.14 | 0.11 |
The experimental results clearly demonstrate that our method achieves significantly lower positioning errors across all three axes compared to the reference approaches. The average error reduction is approximately 60% compared to Reference Method 1 and approximately 55% compared to Reference Method 2. This substantial improvement in positioning accuracy directly translates to more reliable automatic inspection capabilities for fixed-wing drones.
Table 6 provides a comprehensive comparison of inspection efficiency between our method and the reference approaches.
| Performance Metric | Reference Method 1 | Reference Method 2 | Our Method |
|---|---|---|---|
| Target Detection Rate | 84.2% | 73.7% | 94.2% |
| False Alarm Rate | 5.8% | 7.2% | 2.4% |
| Average Inspection Speed | 12.4 km/h | 10.8 km/h | 14.6 km/h |
| Maximum Coverage Per Flight | 28.5 km² | 24.2 km² | 36.8 km² |
| Mission Completion Rate | 82.1% | 76.5% | 95.3% |
Using the center location error threshold as a metric for evaluating inspection efficiency, our method achieves 94.2% efficiency compared to 84.2% and 73.7% for the reference methods. The overall improvement in operational efficiency and coverage area is approximately 11.9% compared to both reference approaches. This significant enhancement demonstrates the practical advantages of our integrated approach for large-scale inspection missions using fixed-wing drones.
Table 7 presents the system performance verification results from our extensive testing campaign.
| Performance Parameter | Test Condition | Measured Value |
|---|---|---|
| EMI Immunity | Electromagnetic interference | 10 V/m |
| ESD Immunity | Electrostatic discharge | 4 kV |
| Surge Protection Level | Power surge | 10 kA |
| Error Detection Rate | System self-diagnosis | < 5% |
| Mean Recovery Time | System failure recovery | 5 s |
| Compatibility Test Pass Rate | Hardware/software integration | > 95% |
| Response Time (Point 1) | Command to execution | 1.2 s |
| Response Time (Point 2) | Command to execution | 0.9 s |
| Response Time (Point 3) | Command to execution | 1.1 s |
| Data Transmission Rate (Point 1) | Image data downlink | 0.41 Gbps |
| Data Transmission Rate (Point 2) | Image data downlink | 0.61 Gbps |
| Data Transmission Rate (Point 3) | Image data downlink | 0.74 Gbps |
The comprehensive performance verification results confirm that our system exhibits robust operation under various environmental and operational conditions. The low error detection rate, fast recovery time, and high compatibility test pass rate demonstrate the system’s reliability for practical inspection applications. The high data transmission rates ensure that inspection imagery can be transmitted to the ground station in real-time for operator monitoring and decision-making.
Lessons Learned and Practical Insights
Throughout the development and testing of this distributed takeoff and landing automatic inspection system for fixed-wing drones, we gained valuable insights that can inform future advancements in this field.
First, the integration of active disturbance rejection control proved to be a critical enabler for reliable distributed operations. The ability of fixed-wing drones to maintain stable flight during takeoff and landing in varying wind conditions directly determines the practicality of distributed operations. Our experimental results confirm that ADRC provides substantial improvements over conventional PID control, particularly during the challenging landing phase where wind disturbances can have the most significant impact.
Second, the combination of FHOG features with the FPTP candidate extraction method offers an effective balance between detection accuracy and computational efficiency. The rotation-invariant property of FHOG features is particularly valuable for inspection applications where targets may appear at arbitrary orientations. The efficient candidate proposal mechanism ensures that computational resources are focused on the most promising regions of the image, enabling real-time processing on embedded hardware.
Third, the distributed takeoff and landing capability fundamentally changes the operational paradigm for fixed-wing drones in inspection applications. By eliminating the requirement to return to the original launch point, the effective inspection range can be extended significantly. The ability to deploy multiple landing sites across the inspection area enables continuous operation over vast geographical regions that would be impractical with conventional single-site operations.
Fourth, the hardware architecture based on the Cortex-A53 processor provides sufficient computational performance for real-time image processing while maintaining the low power consumption essential for drone applications. The integration of multiple sensor types, including high-resolution cameras, thermal imagers, and LiDAR, enables comprehensive inspection capabilities that can detect a wide range of target types and conditions.
Finally, our extensive testing program demonstrated that the complete system achieves an 11.9% improvement in operational efficiency and coverage area compared to existing approaches. This improvement is attributable to the synergistic combination of advanced control algorithms, efficient image processing techniques, and distributed operational capability.
Conclusion
In this paper, we presented a comprehensive design for a large-scale automatic inspection system based on fixed-wing drones with distributed takeoff and landing capability. The system integrates an embedded hardware platform based on the Cortex-A53 architecture running a Debian operating system, active disturbance rejection control for enhanced wind disturbance rejection during takeoff and landing, and FHOG-based target detection with FPTP candidate extraction for reliable small target recognition.
The active disturbance rejection controller we implemented significantly improves the stability of fixed-wing drones during distributed takeoff and landing operations, reducing heading errors by approximately 75% compared to conventional PID control under crosswind conditions. The FHOG-based target detection method achieves 94.2% detection rate with only 2.4% false positive rate, representing substantial improvements over standard approaches.
Experimental validation confirmed that our system achieves 11.9% improvement in operational efficiency and coverage area compared to reference methods, with superior positioning accuracy across all three spatial axes. The comprehensive performance verification demonstrated robust operation under various environmental conditions, with low error rates and fast recovery times.
Our approach provides a reliable and efficient solution for large-scale inspection missions in complex environments. The distributed takeoff and landing capability, combined with advanced control and image processing algorithms, enables fixed-wing drones to conduct automatic inspection operations over extended geographical areas without the limitations imposed by conventional single-site operations. We believe this technology will drive the widespread adoption of drone-based inspection across multiple industries, including power utilities, oil and gas, transportation infrastructure, and environmental monitoring.
The successful development and validation of this system represents a significant step forward in the practical application of fixed-wing drones for automatic inspection. Future work will focus on further improving the robustness of the target detection algorithms under adverse weather conditions, extending the operational range through optimized flight path planning, and integrating additional sensor modalities for enhanced inspection capabilities.