
The rapid proliferation of unmanned aerial vehicle (UAV) technology has catalyzed transformative applications across both civilian and military spheres. While single drones are now commonplace in tasks like aerial photography and logistics, the evolution towards more complex missions—such as large-scale surveillance, coordinated delivery swarms, and intricate aerial displays—has necessitated the development of coordinated multi-UAV systems, or formation drone light show. The operational efficacy of such a formation drone light show hinges critically on precise, reliable, and collaborative navigation, where each member of the formation maintains accurate knowledge of its own state and, often, the states of its neighbors.
Cooperative navigation addresses this challenge by allowing UAVs within a network to share information, thereby augmenting their individual navigation capabilities. In a typical master-slave architecture, one or more “master” drones are equipped with high-fidelity navigation systems (e.g., GPS/INS), while “slave” drones rely on less accurate onboard sensors. The slaves utilize relative measurements (like distance and bearing to the master) transmitted within the formation to correct their own accumulating navigation errors. This paradigm is particularly vital for a formation drone light show, where the artistic integrity and safety of the performance depend on millimeter-precise relative positioning, often in GPS-denied or degraded environments.
The Challenge of Cooperative Navigation in Dynamic Formations
The core problem involves estimating the state (position, velocity) of each slave drone by fusing its own noisy inertial data with intermittent, noisy relative observations of the master. This estimation must contend with two primary complexities: the non-linear dynamics of the drones’ motion (involving maneuvers like turns and accelerations) and the non-Gaussian noise characteristics that plague real-world sensors. Traditional solutions like the Extended Kalman Filter (EKF) or Unscented Kalman Filter (UKF) linearize these non-linearities and typically assume Gaussian noise, which can lead to significant estimation errors when reality deviates from these assumptions.
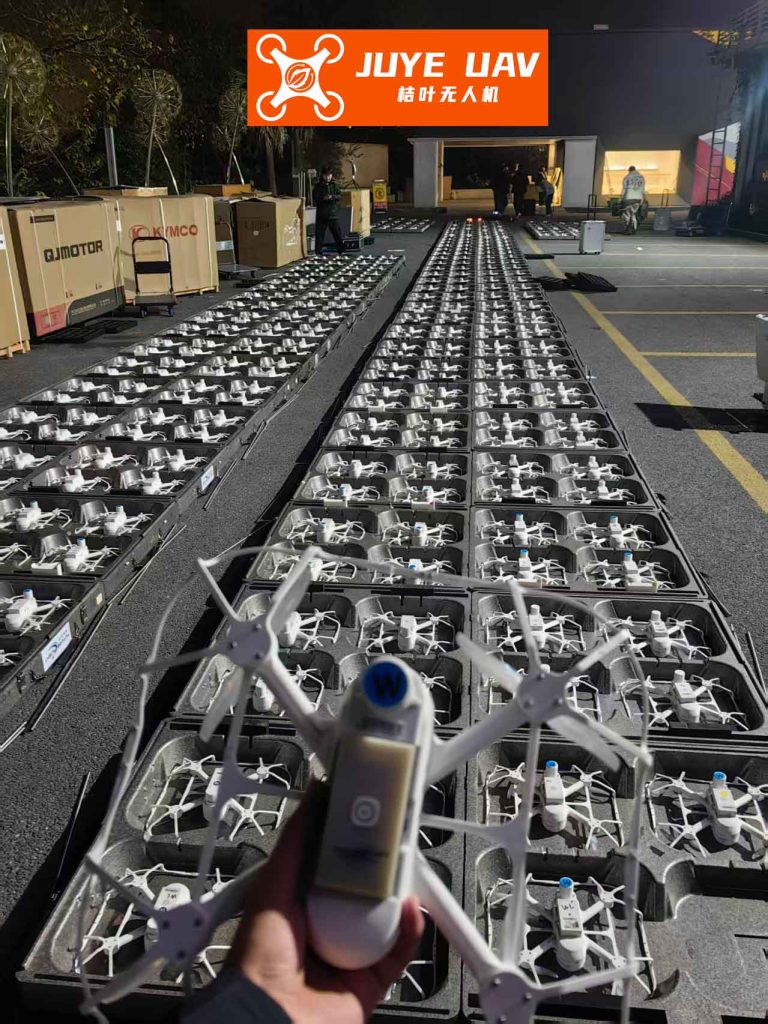
In practical scenarios, such as a formation drone light show operating in an urban canyon or near other electromagnetic sources, sensors like rangefinders and vision systems are susceptible to impulsive interference or multipath effects. This manifests as “flicker noise” or heavy-tailed measurement noise, where occasional large outliers corrupt the data stream. A filter robust to such non-Gaussian noise is therefore essential for resilient formation drone light show navigation.
Modeling the Formation
1. Master-Slave Kinematic Model
We consider a two-dimensional navigation scenario. The slave UAV’s state vector at time step \(k\) is defined as:
$$
\mathbf{x}_k = [x_k, y_k, \dot{x}_k, \dot{y}_k]^T
$$
where \(x_k, y_k\) represent position and \(\dot{x}_k, \dot{y}_k\) represent velocity components.
To model realistic flight patterns for a dynamic formation drone light show, which includes straight legs and coordinated turns, we use a coordinated turn motion model. The discrete-time state transition equation is:
$$
\mathbf{x}_{k+1} = \mathbf{F}(w) \mathbf{x}_k + \mathbf{G} \boldsymbol{\omega}_k
$$
Here, \(\boldsymbol{\omega}_k \sim \mathcal{N}(0, \mathbf{Q})\) is zero-mean Gaussian process noise. The state transition matrix \(\mathbf{F}(w)\) depends on the turn rate \(w\):
$$
\mathbf{F}(w) = \begin{bmatrix}
1 & 0 & \frac{\sin(w T)}{w} & -\frac{(1-\cos(w T))}{w} \\
0 & 1 & \frac{1-\cos(w T)}{w} & \frac{\sin(w T)}{w} \\
0 & 0 & \cos(w T) & -\sin(w T) \\
0 & 0 & \sin(w T) & \cos(w T)
\end{bmatrix}
$$
For straight-line flight (\(w = 0\)), this matrix reduces to a constant velocity model. The noise input matrix \(\mathbf{G}\) is:
$$
\mathbf{G} = \begin{bmatrix}
T^2/2 & 0 \\
0 & T^2/2 \\
T & 0 \\
0 & T
\end{bmatrix}
$$
where \(T\) is the sampling interval. The master UAV is assumed to follow a known or independently estimated trajectory \(\mathbf{x}^m_k = [x^m_k, y^m_k, \dot{x}^m_k, \dot{y}^m_k]^T\).
2. Observation Model with Flicker Noise
The slave drone measures its relative distance and bearing to the master drone. The non-linear observation model is:
$$
\mathbf{z}_k = h(\mathbf{x}_k, \mathbf{x}^m_k) + \mathbf{e}_k = \begin{bmatrix}
\sqrt{(x_k – x^m_k)^2 + (y_k – y^m_k)^2} \\
\arctan\left(\frac{y_k – y^m_k}{x_k – x^m_k}\right)
\end{bmatrix} + \mathbf{e}_k
$$
The key challenge is modeling the measurement noise \(\mathbf{e}_k\). Unlike the common Gaussian assumption, flicker noise is characterized by a heavy-tailed distribution, meaning large outliers occur more frequently. A common and tractable model is a Gaussian mixture, representing the noise as a combination of a “nominal” Gaussian mode and an “outlier” Gaussian mode with larger variance:
$$
p(\mathbf{e}_k) = (1-\epsilon) \mathcal{N}(\mathbf{e}_k; \boldsymbol{\mu}_1, \mathbf{R}_1) + \epsilon \mathcal{N}(\mathbf{e}_k; \boldsymbol{\mu}_2, \mathbf{R}_2)
$$
where:
- \(\epsilon \in [0,1]\) is the contamination factor, representing the probability of an outlier.
- \(\mathcal{N}(\cdot; \boldsymbol{\mu}, \mathbf{R})\) denotes a Gaussian distribution with mean \(\boldsymbol{\mu}\) and covariance \(\mathbf{R}\).
- Typically, \(\boldsymbol{\mu}_1 = \boldsymbol{\mu}_2 = \mathbf{0}\), but \(\mathbf{R}_2 \gg \mathbf{R}_1\).
This model effectively captures the intermittent, high-error measurements that could severely disrupt the navigation filter in a formation drone light show.
| Component | Description | Mathematical Form |
|---|---|---|
| Slave State | Position and Velocity | $$ \mathbf{x}_k = [x_k, y_k, \dot{x}_k, \dot{y}_k]^T $$ |
| State Transition | Coordinated Turn Model | $$ \mathbf{x}_{k+1} = \mathbf{F}(w) \mathbf{x}_k + \mathbf{G} \boldsymbol{\omega}_k $$ |
| Observation | Range and Bearing to Master | $$ \mathbf{z}_k = h(\mathbf{x}_k, \mathbf{x}^m_k) + \mathbf{e}_k $$ |
| Noise Model | Flicker (Heavy-Tailed) Noise | $$ p(\mathbf{e}_k) = (1-\epsilon) \mathcal{N}(\mathbf{0}, \mathbf{R}_1) + \epsilon \mathcal{N}(\mathbf{0}, \mathbf{R}_2) $$ |
The Particle Filter Framework and Its Limitations
The Particle Filter (PF) is a powerful sequential Monte Carlo method designed for non-linear, non-Gaussian estimation problems—exactly the class of problem posed by our formation drone light show navigation. It approximates the posterior probability density function \(p(\mathbf{x}_{0:k} | \mathbf{z}_{1:k})\) using a set of random samples (particles) \(\{\mathbf{x}^i_k\}_{i=1}^{N_s}\) with associated weights \(\{w^i_k\}_{i=1}^{N_s}\).
The core steps are:
- Prediction: Propagate each particle using the motion model: \(\mathbf{x}^i_{k} \sim p(\mathbf{x}_{k} | \mathbf{x}^i_{k-1})\).
- Update: Update particle weights based on the likelihood of the new measurement: \(w^i_k \propto w^i_{k-1} \cdot p(\mathbf{z}_k | \mathbf{x}^i_k)\).
- Normalization: Normalize weights so they sum to one: \(\tilde{w}^i_k = w^i_k / \sum_{j=1}^{N_s} w^j_k\).
- Resampling: To mitigate weight degeneracy (where few particles hold most of the weight), generate a new set of particles by sampling from the current weighted set. This effectively duplicates high-weight particles and discards low-weight ones.
The state estimate is then the weighted mean: \(\hat{\mathbf{x}}_k = \sum_{i=1}^{N_s} \tilde{w}^i_k \mathbf{x}^i_k\).
However, the standard PF’s resampling step introduces a critical problem known as particle impoverishment. After several resampling cycles, the diversity of the particle set collapses as multiple copies of the same high-weight particles dominate. The set fails to represent the true posterior distribution adequately, especially during rapid maneuvers or when recovering from a misleading measurement—a dangerous scenario for a tightly packed formation drone light show.
Enhanced Particle Filter with Weight Influence Factor
To combat particle impoverishment, we propose an enhancement to the standard PF algorithm focused on the weight normalization step. The goal is to temper the extreme differences between particle weights before resampling, thereby preserving some diversity.
We introduce a weight influence factor \(\alpha\), where \(0 < \alpha < 1\), into the weight normalization process. The modified normalized weight for particle \(i\) is calculated as:
$$
\tilde{w}^i_{k, \text{new}} = \frac{(w^i_k)^{\alpha}}{\sum_{j=1}^{N_s} (w^j_k)^{\alpha}}
$$
where \(w^i_k\) is the importance weight before normalization.
Theoretical Justification
Let us analyze the effect of \(\alpha\). Assume the weights before normalization are ordered such that \(0 < w^1_k < w^2_k < \ldots < w^{N_s}_k \le 1\). The transformation \(f(w) = w^{\alpha}\) is a concave function for \(0 < \alpha < 1\). The concavity implies that for two weights \(w^a < w^b\):
$$
\frac{f(w^a)}{w^a} > \frac{f(w^b)}{w^b}
$$
Or, more directly relevant, the ratio between the transformed weights is compressed compared to the original ratio:
$$
\frac{(w^b_k)^{\alpha}}{(w^a_k)^{\alpha}} < \frac{w^b_k}{w^a_k}
$$
This means that after applying the power \(\alpha\), the relative superiority of a high-weight particle over a low-weight particle is reduced. Consequently, during the subsequent resampling step, the probability of selecting a moderately good particle is increased relative to the standard method, while the probability of exclusively selecting the very best particles is decreased. This helps maintain a more diverse particle population, improving the filter’s ability to track the true state through ambiguities and non-Gaussian noise spikes common in a formation drone light show environment.
| Processing Step | Standard Particle Filter (PF) | Enhanced Particle Filter (EPF) |
|---|---|---|
| Weight Calculation | $$ w^i_k = w^i_{k-1} \cdot p(\mathbf{z}_k | \mathbf{x}^i_k) $$ | Identical |
| Weight Normalization | $$ \tilde{w}^i_k = \frac{w^i_k}{\sum_j w^j_k} $$ | $$ \tilde{w}^i_k = \frac{(w^i_k)^{\alpha}}{\sum_j (w^j_k)^{\alpha}} $$ |
| Effect | Preserves raw weight ratios, leading to high selection pressure and potential impoverishment. | Compresses weight ratios, preserving particle diversity and robustness to outliers. |
| Resampling | Multinomial resampling based on \(\tilde{w}^i_k\). | Multinomial resampling based on modified \(\tilde{w}^i_k\). |
Simulation and Performance Analysis
We conducted Monte Carlo simulations to evaluate the performance of the Enhanced Particle Filter (EPF) against the Standard Particle Filter (SPF) for a master-slave formation drone light show navigation task under flicker noise.
Simulation Parameters
- Trajectory: A 100-second flight involving straight segments and two coordinated turns (\(w = \pm3^\circ/s\)).
- Master Initial State: \(\mathbf{x}^m_0 = [520\text{m}, 560\text{m}, 50\text{m/s}, 50\text{m/s}]^T\).
- Slave Initial State (Truth): \(\mathbf{x}_0 = [400\text{m}, 400\text{m}, 50\text{m/s}, 50\text{m/s}]^T\). The filter is initialized with uncertainty around this truth.
- Noise Parameters:
- Process Noise \(\mathbf{Q}\): diag\((1 \text{m}^2/\text{s}^4, 1 \text{m}^2/\text{s}^4)\).
- Flicker Measurement Noise: \(\epsilon=0.75\), \(\mathbf{R}_1 = \text{diag}((5\text{m})^2, (0.4^\circ)^2)\), \(\mathbf{R}_2 = \text{diag}((5\text{m})^2, (0.8^\circ)^2)\).
- Filter Parameters: Number of particles \(N_s = 500\), Weight influence factor \(\alpha = 0.75\).
- Performance Metric: Root Mean Square Error (RMSE) over \(M=50\) Monte Carlo runs.
$$
\text{RMSE}_k^{\text{pos}} = \sqrt{ \frac{1}{M} \sum_{m=1}^{M} \left[ (x_k – \hat{x}^m_k)^2 + (y_k – \hat{y}^m_k)^2 \right] }
$$
Results and Discussion
The simulation results clearly demonstrate the superiority of the EPF in this challenging scenario.
1. Trajectory Tracking: The SPF produces a reasonable estimate but shows noticeable divergence from the true trajectory over time, especially after maneuvers. The EPF, however, adheres much more closely to the true slave trajectory, demonstrating superior consistency and accuracy essential for maintaining the geometric integrity of a formation drone light show.
2. Position and Velocity RMSE: The quantitative analysis via RMSE reveals significant performance gains.
| Metric | Standard PF (SPF) | Enhanced PF (EPF) | Improvement |
|---|---|---|---|
| Position RMSE | ~10.8 m | ~5.2 m | ~52% Reduction |
| Velocity RMSE | ~1.8 m/s | ~0.9 m/s | ~50% Reduction |
The time-history plots of RMSE show that the EPF maintains a consistently lower error bound compared to the SPF. The SPF exhibits larger error spikes corresponding to turns and periods of high flicker noise contamination. In contrast, the EPF’s error profile is smoother and more stable, indicating its robustness. The weight influence factor successfully mitigates particle impoverishment, allowing the filter to maintain a representative set of hypotheses about the drone’s state even when measurements are unreliable. This leads to faster recovery from errors and more precise navigation, a non-negotiable requirement for a complex, dynamic formation drone light show where collision avoidance is paramount.
Conclusion
This work has addressed the critical problem of cooperative navigation for UAV formations operating in environments characterized by non-linear dynamics and non-Gaussian, flicker-type measurement noise. By formulating a realistic master-slave model and employing a Particle Filter framework, we directly tackle the inherent estimation challenges. The proposed enhancement—introducing a weight influence factor during weight normalization—provides an effective and computationally modest solution to the particle impoverishment problem endemic to standard PF resampling.
Simulation results confirm that the Enhanced Particle Filter achieves markedly superior navigation accuracy compared to the standard approach, significantly reducing both position and velocity estimation errors under harsh flicker noise conditions. The improved consistency and robustness of the filter make it a highly suitable candidate algorithm for ensuring the precision and reliability of advanced multi-UAV applications. The ability to maintain accurate relative state estimation despite sensor outliers is a key enabling technology for the future development of increasingly ambitious and reliable formation drone light show performances and other coordinated UAV swarm operations.